

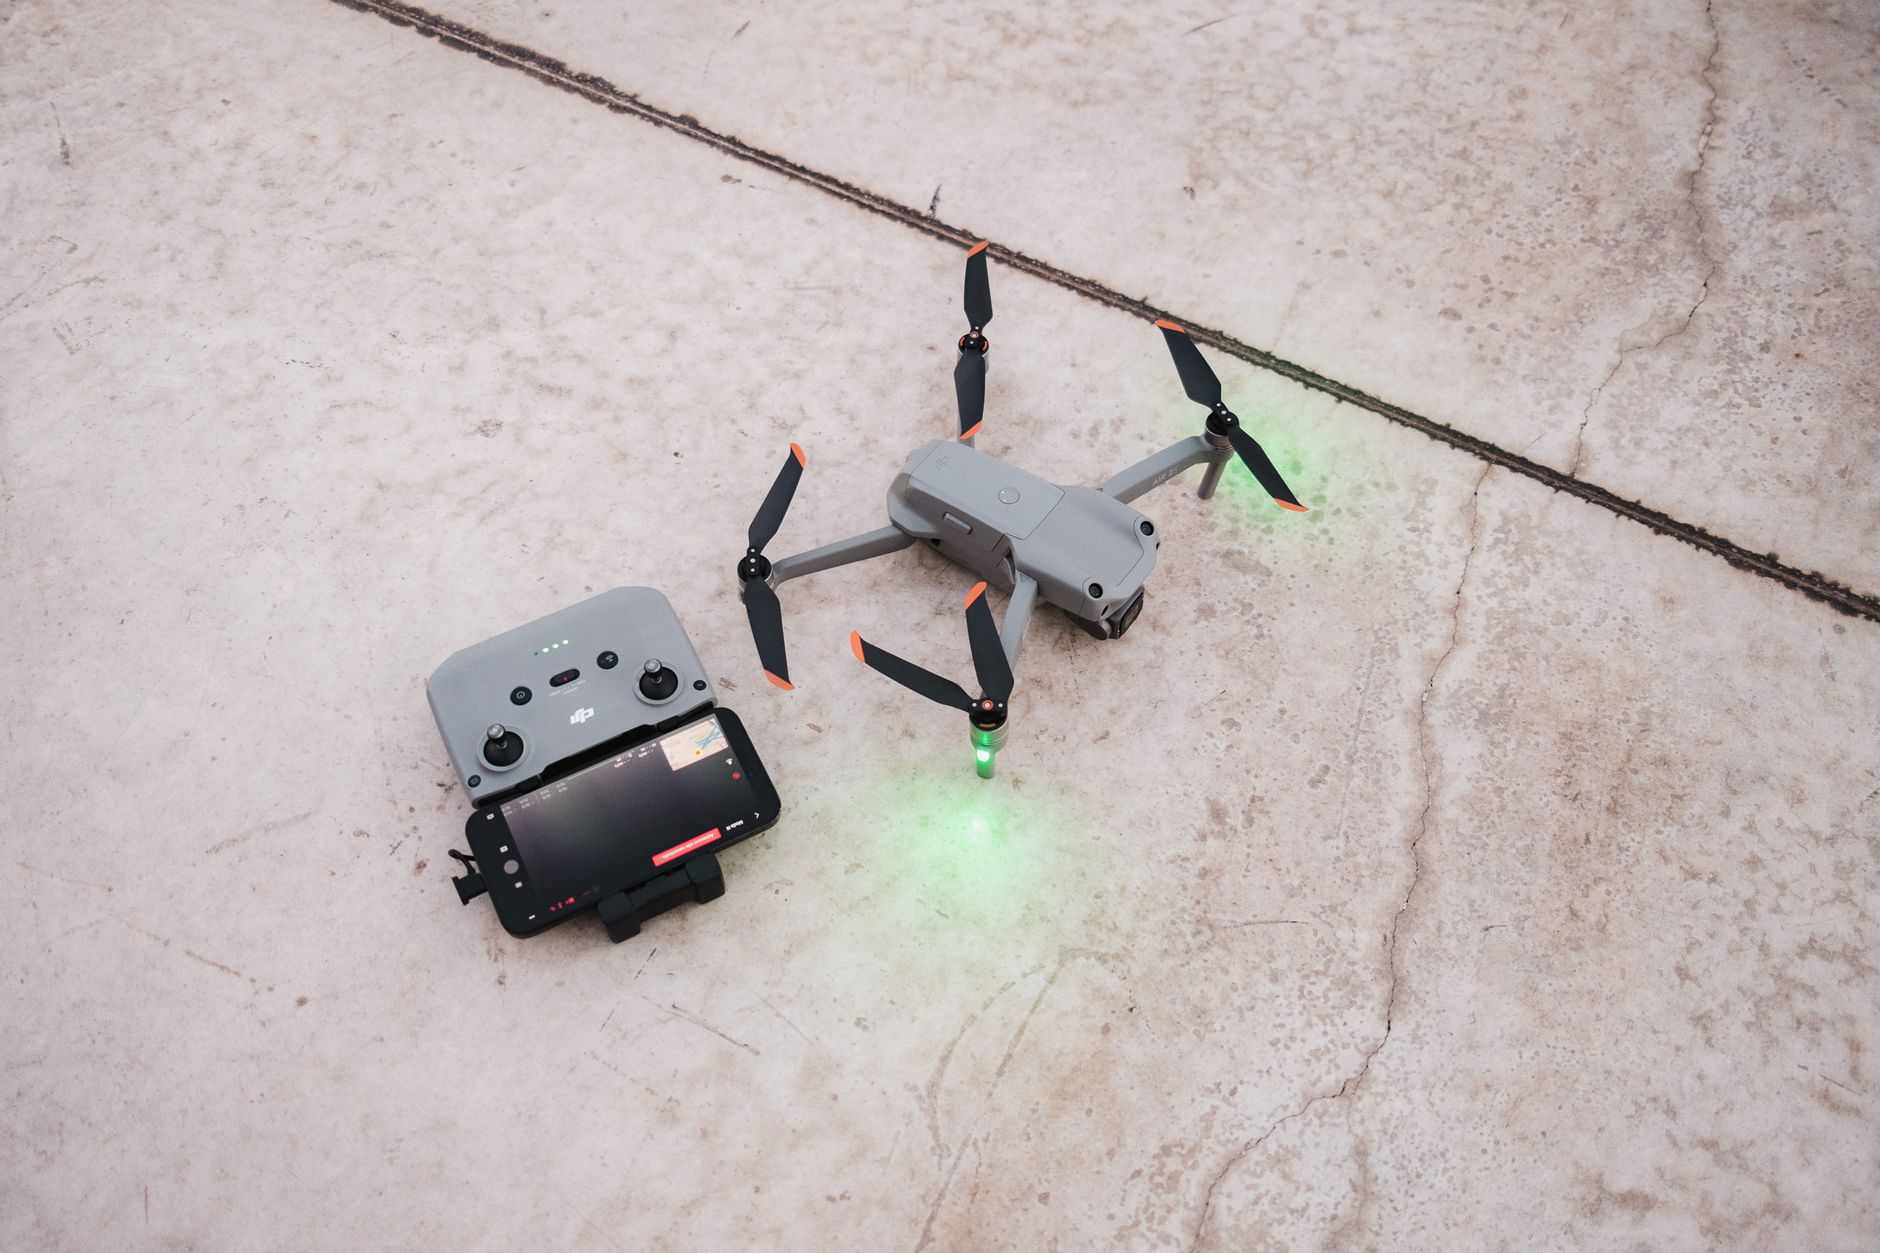
Object Avoidance Drone Guide: How to Build Safer UAVs with Compact dToF LiDAR Sensors
Modern drones can fly faster, carry sharper cameras, and run more complex autonomous missions than ever. But here’s the deal: the problem that still separates a lab prototype from a dependable commercial UAV is safe obstacle response. An object avoidance drone has to do more than “notice” a wall, branch, cable, shelf, bridge column, pallet, or moving cart. It has to measure distance in real time, decide whether that obstacle is actually in the flight path, and send a command the aircraft can act on before things get expensive.
For commercial drones used in inspection, mapping, logistics, security, research, agriculture, and indoor navigation, poor obstacle avoidance is not just an annoying performance gap. It can mean cracked props, wrecked payloads, missed customer deadlines, damaged property, and safety exposure. In the shop, we don’t judge an avoidance system by whether it looks clever on a demo video. We judge it by whether it gives the aircraft enough time and enough confidence to slow down, stop, climb, descend, reroute, or hold a safe standoff distance.
This guide walks through how to build safer UAVs using compact dToF LiDAR sensors, with a practical focus on depth sensing, sensor placement, field of view, range, frame rate, flight-controller integration, and testing workflows. Instead of treating obstacle avoidance as one checkbox feature, we’ll break it into the full perception-to-action chain: detection, depth measurement, confidence filtering, obstacle classification, decision logic, and flight control.
We’ll also look at how a lightweight solid-state LiDAR module such as the DTOF Solid State LiDAR HM-LD1 can support compact drone platforms by providing real-time depth maps and point cloud data through UART, UDP, and UVC interfaces. Look, the sensor alone will not magically make a drone safe. But the right depth sensor, mounted correctly and tied into a sane control strategy, can give your UAV a much better shot at avoiding bad contact.
Table of Contents
- 👉 What Is an Object Avoidance Drone?
- 👉 Why Object Avoidance Matters for Commercial UAVs
- 👉 How Object Avoidance Works: From Sensing to Flight Commands
- 👉 Sensor Options for Drone Obstacle Avoidance
- 👉 Why Compact dToF LiDAR Is Useful for Object Avoidance Drones
- 👉 Object Avoidance Drone System Architecture
- 👉 Sensor Placement, FOV, and Coverage Strategy
- 👉 Integration Workflow for Embedded UAV Platforms
- 👉 DTOF Solid State LiDAR HM-LD1 Specs for UAV Integration
- 👉 Testing and Validation for Safer Avoidance Behavior
- 👉 Industrial Applications for Object Avoidance Drones
- 👉 Common Engineering Mistakes to Avoid
- 👉 FAQ: Object Avoidance Drone Development
What Is an Object Avoidance Drone?
An object avoidance drone is a UAV equipped with perception sensors and control logic that allow it to detect nearby obstacles and automatically modify its flight behavior. The key word is “avoidance.” Plenty of systems can detect that something exists in the environment, but real avoidance means turning that measurement into a useful action. Depending on the mission, the aircraft may slow down before impact, stop and hover, maintain a defined distance boundary, reroute around an obstacle, follow terrain, assist landing, or avoid walls during indoor navigation.
For industrial UAVs, object avoidance is not limited to consumer-style “front obstacle sensing.” It can include forward collision prevention, downward altitude assistance, side-distance control for corridor flight, close-range structure inspection, autonomous docking support, and protective behavior near people or assets. The performance target should be defined by the mission profile, aircraft speed, payload value, operating environment, and acceptable risk level.
Obstacle Detection vs. Object Avoidance
Obstacle detection answers a simple question: is something present in the sensing area? Ranging answers a more useful question: how far away is it? Avoidance answers the engineering question that matters most: what should the drone do now? A camera model might identify an object visually, but the drone still needs distance, motion context, and control logic. A range sensor might measure a surface, but without decision thresholds and flight commands, it is only a measurement device.
Why Distance Data Matters More Than Image Recognition Alone
Image recognition is valuable when you need to understand what an object is. Distance data is essential when you need to know whether that object is a collision risk. A drone does not always need to know whether an obstacle is a wall, tree, pallet, railing, or bridge column. Often, it simply needs to know whether the obstacle is inside the motion path and how much time remains before the airframe reaches it.
That is why depth sensors, LiDAR, stereo vision, radar, and sensor fusion show up so often in autonomous navigation projects. The aircraft needs geometry, not just pretty pictures. To understand why depth-based sensing is widely used in robotics and UAV perception, see this guide on what is LiDAR technology.
Core Components of an Avoidance-Capable UAV
A functional object avoidance drone typically includes a perception sensor, a processor or companion computer, filtering software, avoidance logic, and a flight controller interface. The sensor captures depth or environmental data. The processor turns that data into useful measurements such as nearest obstacle distance or blocked flight regions. The avoidance logic decides whether to warn, brake, climb, descend, or change route. The flight controller executes the command while maintaining stable attitude and motor control.
In practical engineering terms, the main building blocks are:
- ✅ Perception hardware: LiDAR, stereo camera, radar, ultrasonic sensor, optical flow module, or a fused sensor package.
- ✅ Processing layer: Companion computer, embedded Linux board, microcontroller, or onboard compute module that can read and interpret sensor data.
- ✅ Decision logic: Software that determines whether the obstacle is relevant to the current flight direction and mission state.
- ✅ Flight controller interface: A reliable path for sending brake commands, velocity limits, obstacle distance messages, position offsets, or failsafe triggers.
- ✅ Validation workflow: Bench tests, controlled flight tests, logs, replay tools, and clear acceptance criteria.
Why Object Avoidance Matters for Commercial UAVs
Commercial UAV crashes are expensive because the cost is rarely limited to propellers or frame arms. A professional drone may carry a stabilized gimbal, inspection camera, thermal payload, mapping sensor, RTK positioning hardware, custom compute module, batteries, and customer-specific equipment. Even when the airframe survives, a crash can interrupt a paid mission, damage customer property, delay project schedules, and reduce operator confidence.
Look at it like a production floor problem. If a machine goes down, you do not just count the broken part. You count the idle crew, the missed delivery, the rework, the troubleshooting time, and the loss of trust. Drone crashes are the same. Object avoidance is not just about protecting plastic and carbon fiber. It is about keeping the mission moving.
Crash Prevention and Mission Continuity
Object avoidance improves mission continuity by reducing the likelihood of preventable contact with walls, shelves, columns, tree branches, machinery, cranes, scaffolding, and infrastructure. In inspection work, the drone may need to fly close enough to capture useful imagery but far enough to avoid striking the structure. In warehouse work, the drone may pass near racks, forklifts, pallets, lighting, hanging equipment, and people. In construction environments, the site layout changes constantly, so a static map cannot be trusted as the only safety layer.
The right obstacle avoidance system gives the aircraft a local awareness layer. It does not replace planning, pilot judgment, or compliance procedures. But it does give the UAV an onboard way to react when the real world does not match the plan.
Autonomy Requirements in GPS-Denied Environments
Indoor drones and confined-space UAVs often operate without reliable GNSS. In these environments, local perception becomes much more important. A drone that cannot rely on satellite positioning must use onboard sensing to understand walls, floors, ceilings, shelving, doors, windows, beams, and temporary obstacles. Object avoidance can also support stable behavior during docking, landing, corridor traversal, and low-altitude research flights.
GPS-denied work is where weak perception gets exposed quickly. The drone may drift, the pilot may have limited line of sight, and the environment may include narrow passages or reflective surfaces. That combination is exactly where direct depth measurement becomes useful.
Safety Margins for Inspection and Industrial Flights
Industrial navigation companies such as Trimble have helped popularize the importance of accurate positioning, mapping, and field data in connected industrial workflows. For UAV developers, the same lesson applies: reliable autonomy depends on high-quality environmental information. Obstacle avoidance improves safety margins by providing real-time local feedback when the drone approaches structures, assets, terrain, or people.
Industries that benefit from UAV obstacle avoidance include bridge inspection, warehouse inventory, construction monitoring, powerline inspection, dam and tunnel inspection, agriculture, indoor robotics research, emergency response, security patrol, and confined-space inspection. In each case, safer flight behavior can reduce downtime and expand the range of missions operators are willing to automate.
How Object Avoidance Works: From Sensing to Flight Commands
An object avoidance drone works by connecting perception to flight control. The sensor is only the first step. A safe system must measure the environment, filter the data, evaluate risk, choose an avoidance response, and send a command that the flight controller can execute reliably. This sequence must happen continuously during flight, with enough speed and confidence to keep the drone outside its minimum safe distance.
In the shop, we often describe this as the perception-to-action pipeline. If any link in that chain is weak, the whole system is weak. A good sensor with poor filtering will trigger false stops. Good filtering with poor latency will respond late. Good software with bad mounting will stare at landing gear all day. Good commands with bad flight-controller tuning can still overshoot the obstacle.
Step 1: Environmental Sensing
Sensors capture information about the world around the drone. A UAV obstacle avoidance system may use LiDAR, stereo cameras, ultrasonic sensors, radar, optical flow, visual-inertial odometry, or a fused sensor array. The right choice depends on range, lighting, weight, power budget, aircraft speed, operating environment, and software capability. For compact drones, small solid-state sensors are especially attractive because they can be mounted without excessive mechanical complexity.
Step 2: Depth Measurement and Point Cloud Generation
Depth sensors provide distance values for detected areas. A compact dToF LiDAR module can output depth maps and 3D point cloud data, allowing software to calculate the nearest object in a specific field of view. Instead of reporting only one distance value, a depth map provides spatial structure. This allows the system to divide the scene into regions such as center, left, right, upper, and lower zones and then decide whether the flight path is blocked.
Step 3: Obstacle Filtering and Region of Interest Selection
Raw sensor data should not be treated as a direct flight command. Avoidance systems should filter data by minimum distance threshold, object confidence, field-of-view region, flight direction, drone velocity, altitude, and mission state. For example, a small object at the edge of the field of view may not require the same response as a wall directly in front of the drone. A downward sensor used for terrain following should be processed differently from a forward-facing sensor used for collision prevention.
Step 4: Avoidance Decision Logic
Avoidance behavior may include braking, hovering, climbing, descending, moving laterally, following a surface contour, rerouting around an object, or alerting the operator. The correct behavior depends on the mission. A warehouse inventory drone might slow and stop near shelving. A bridge inspection UAV might maintain a fixed standoff distance from a concrete surface. A terrain-following drone may adjust altitude gradually instead of stopping completely.
Step 5: Flight Controller Command Execution
The companion computer or embedded controller sends commands to the flight controller. These commands may be velocity setpoints, position offsets, guided-mode requests, mission pause commands, or failsafe triggers. The flight controller remains responsible for stabilization, motor output, attitude control, and safety handling. For dependable performance, the avoidance algorithm should be designed around realistic latency, communication timing, and flight dynamics rather than ideal sensor readings alone.
A practical object avoidance workflow usually looks like this:
- ⚙️ Sense: Capture depth data from the LiDAR or other perception sensor.
- ⚙️ Filter: Remove invalid readings, noise, irrelevant edge data, and low-confidence points.
- ⚙️ Segment: Divide the field of view into useful regions such as center, left, right, upper, and lower zones.
- ⚙️ Evaluate: Compare obstacle distance against speed-based thresholds and mission rules.
- ⚙️ Command: Send a safe, bounded control request to the flight controller.
- ⚙️ Verify: Log sensor data, command timing, and aircraft response for tuning.
Sensor Options for Drone Obstacle Avoidance
There is no universal best drone obstacle avoidance sensor. Each sensing method has strengths and limitations. The most robust object avoidance drone architecture often uses sensor fusion, combining direct depth measurement, visual context, inertial data, and positioning where available. The sensor selection process should begin with the mission environment rather than the sensor catalog.
LiDAR Sensors
LiDAR sensors are useful because they provide direct distance measurement. A LiDAR drone sensor can support obstacle detection, altitude hold, terrain following, inspection standoff control, and robotic navigation. Compact dToF LiDAR modules are particularly relevant for small UAVs because they can provide depth images without requiring a large rotating scanner.
Stereo Vision Cameras
Stereo vision cameras provide rich visual data and can estimate depth from the difference between two camera views. They are valuable when object recognition and scene understanding are important. However, stereo vision can degrade in low-texture environments, glare, darkness, repetitive patterns, or high-speed motion. It also requires sufficient compute resources and careful calibration.
Ultrasonic Sensors
Ultrasonic sensors are low cost and simple for short-range distance detection. They are often used for landing assistance or close-range indoor sensing. Their limitations include short range, wide beam patterns, and poor performance on angled, soft, or irregular surfaces. They are usually not enough for advanced autonomous drone navigation by themselves.
Millimeter-Wave Radar
Radar can perform well in dust, fog, poor visibility, and some harsh outdoor environments. It is useful for detecting motion and working in conditions where optical sensors may struggle. However, radar typically offers lower spatial resolution than LiDAR or cameras, so it may be less effective for identifying small object shapes or precise close-range structure boundaries.
Optical Flow and Visual-Inertial Systems
Optical flow and visual-inertial systems estimate movement relative to the environment. They are useful for indoor stabilization, drift reduction, and GPS-denied navigation. However, they are not a complete substitute for obstacle distance sensing because they primarily estimate motion rather than measuring all nearby collision risks directly.
Why Sensor Fusion Is Often the Best Strategy
Companies such as Luminar Technologies have shown how LiDAR can become a key perception layer in safety-critical autonomy. In drone systems, LiDAR can be fused with cameras, IMU data, optical flow, GNSS, RTK, or radar to create more resilient behavior. For example, LiDAR may provide direct depth, a camera may identify object type, and the IMU may help compensate for drone motion during rapid maneuvers.
| Sensor Type | Strengths | Limitations | Best UAV Use Cases |
|---|---|---|---|
| dToF LiDAR | Direct distance measurement, depth maps, compact modules, useful indoors and outdoors | Range and reflectivity depend on environment and target surface | Obstacle avoidance, altitude hold, terrain following, inspection drones |
| Stereo Camera | Rich visual information, object recognition, passive sensing | Performance can degrade in low texture, glare, darkness, or high-speed scenes | Visual navigation, AI recognition, mapping |
| Ultrasonic | Low cost, simple short-range distance detection | Limited range, wide beam, poor performance on angled or soft surfaces | Landing assist, close-range indoor avoidance |
| Radar | Works in dust, fog, and poor visibility; good for velocity detection | Lower spatial resolution than LiDAR or cameras | Outdoor UAVs, harsh environments, vehicle detection |
Why Compact dToF LiDAR Is Useful for Object Avoidance Drones
Compact dToF LiDAR is useful for object avoidance drones because it offers direct depth measurement in a small package. For UAV developers, this matters because every gram, watt, cable, and mounting location affects the total aircraft design. A sensor that can provide depth maps and point cloud data without large mechanical scanning hardware is easier to evaluate on compact airframes, robotics prototypes, and embedded UAV platforms.
What Direct Time-of-Flight Means
dToF stands for direct time-of-flight. A dToF sensor measures distance by emitting light and calculating the time required for reflected light to return. Because the measurement is based on return time, it provides direct range information rather than relying only on image appearance. This is valuable for UAV obstacle avoidance because the flight controller needs distance-aware decisions.
Depth Maps vs. Single-Point Distance Sensors
A single-point range sensor may tell the drone that something exists at a specific distance, but it cannot easily show whether the obstacle is wide, narrow, centered, above the drone, or off to the side. A depth map provides distance values across a grid. This allows the software to focus on a region of interest, such as the central flight corridor, and ignore less relevant areas. For a deeper explanation of how depth images are created and interpreted, read this guide to dToF LiDAR imagery and depth maps.
Why Solid-State Design Helps UAV Integration
Solid-state LiDAR modules do not rely on a large rotating mechanical scanning assembly. This can simplify mechanical integration, reduce packaging challenges, and make the sensor easier to mount on small UAVs. For drone developers, solid-state architecture can also support multi-sensor layouts, where several compact modules are placed around the airframe for forward, downward, side, or rear coverage.
Balancing Weight, Range, Field of View, and Power
A drone depth sensor must be selected as part of a full system tradeoff. Long range is useful, but not if the module is too heavy for the aircraft. Wide field of view is useful, but it must match the flight path and obstacle geometry. Low power is useful, but the data must still update quickly enough to support the intended speed. The best sensor choice is the one that supports the mission’s real avoidance envelope, not simply the highest number on one specification line.
When reviewing a compact LiDAR for UAV use, pay attention to:
- ✅ Usable range: Indoor, outdoor, daytime, nighttime, dark surface, reflective surface, and angled target performance may all differ.
- ✅ Field of view: The FOV must cover the flight corridor, not just look impressive on a datasheet.
- ✅ Frame rate: Update rate must match aircraft speed, braking distance, and processing latency.
- ✅ Weight and power: A few extra grams and watts matter on small UAVs.
- ✅ Interfaces: UART, UDP, and UVC can support very different integration workflows.
- ✅ Software support: SDKs, sample tools, and point cloud access can shorten development time.
Object Avoidance Drone System Architecture
A reliable object avoidance drone usually separates responsibilities between the perception system and the flight controller. This separation helps engineers build modular systems that can be tested, upgraded, and debugged. The perception layer measures the world. The processing layer interprets the data. The flight controller layer stabilizes and commands the aircraft.
Perception Layer
The perception layer may include LiDAR, cameras, IMU, barometer, GNSS, RTK, optical flow, or radar. A dToF LiDAR sensor provides depth information for nearby obstacles. In a forward-facing configuration, it can help detect collision risks in the direction of flight. In a downward-facing configuration, it can support terrain following, altitude hold, and landing assistance.
Companion Computer or Embedded Processor
A Raspberry Pi, Jetson, x86 Linux computer, ARM Linux board, or custom embedded processor may process depth maps and point clouds. This layer runs filtering, thresholding, object segmentation, region-of-interest logic, and avoidance behavior. Engineers should first visualize the raw depth data before closing the loop with flight control commands.
Flight Controller Layer
The flight controller handles stabilization, motor control, mission execution, mode changes, and failsafe behavior. A companion computer may send obstacle distance information, velocity limits, position setpoints, or mission pause commands. The flight controller should also have clear behavior for lost sensor data, invalid measurements, or communication failure.
Communication Interfaces
Communication interface selection affects development speed and system architecture. UVC can support camera-like depth workflows. UDP can support networked data streaming. UART can support embedded or microcontroller-style integration. The right choice depends on the processor, software stack, cable length, bandwidth requirements, and system reliability goals.
Power and Mechanical Design
Power and mechanical design are often underestimated. A sensor should be mounted where it has a clear field of view, stable mechanical support, and protected cabling. Engineers should avoid mounting locations where propellers, landing gear, payload brackets, protective cages, or frame parts enter the sensor view. Vibration should be considered, especially on small multirotors where frame resonance can affect sensor stability.
For outdoor autonomous drones, obstacle avoidance is often paired with high-precision positioning; this article explains the difference between an RTK receptor vs receiver.
Sensor Placement, FOV, and Coverage Strategy
Sensor placement determines what the drone can actually perceive. A powerful sensor mounted in the wrong location can create blind zones, false detections, or delayed response. UAV developers should map the sensor’s field of view against the aircraft’s likely motion envelope, mission path, payload geometry, and flight modes.
Forward-Facing Obstacle Avoidance
Forward-facing sensors are useful for route navigation and collision prevention during normal forward flight. They should be mounted where the central field of view aligns with the likely motion direction. A slight downward tilt can be useful if the drone needs to detect both frontal obstacles and rising terrain, but too much downward tilt can reduce forward warning distance.
Downward Sensing for Altitude Hold and Terrain Following
Downward-facing sensors help with altitude hold, terrain following, landing assistance, and low-altitude inspection. They are especially useful where barometric altitude is insufficient or where the drone needs to maintain a defined distance from the ground or a surface below. For outdoor terrain following, engineers should test slopes, vegetation, dark ground, reflective materials, and sunlight conditions.
Side Coverage for Confined-Space Flight
Side-facing sensors are useful in corridors, warehouses, tunnels, bridges, and close-proximity inspection. They can help maintain distance from walls, racks, columns, and structural surfaces. Side sensing is also valuable when the drone performs lateral movement rather than only forward movement.
Multi-Sensor Layouts for 360-Degree Awareness
Some UAVs use multiple compact sensors to improve coverage around the airframe. A multi-sensor layout may include forward, rear, downward, and side-facing modules. This can support safer operation during reverse flight, side-slip movement, docking, and confined-space navigation. The tradeoff is increased weight, power consumption, cabling, and data processing.
Understanding Field of View and Blind Zones
The HM-LD1’s 60° horizontal by 45° vertical field of view should be mapped to the drone’s intended flight envelope. Blind zones can occur outside the field of view, behind payloads, below landing gear, or near airframe components. The only reliable way to confirm placement is to view the actual depth map and point cloud data after the sensor is installed on the drone.
Integration Workflow for Embedded UAV Platforms
Integration should be performed in stages. A common mistake is connecting a sensor to a flight controller too quickly and assuming that raw measurements are ready for autonomous control. A safer workflow begins with use-case definition, interface selection, visualization, detection logic, flight-controller integration, and progressive validation.
Step 1: Define the Avoidance Use Case
Start by defining the mission. An indoor drone avoiding walls has different requirements from an inspection drone maintaining distance from bridge surfaces. A warehouse drone needs to handle shelving and changing inventory. A terrain-following drone needs reliable downward or angled sensing. A landing assistance system needs stable close-range measurements. Clear requirements make sensor selection and testing much more effective.
Step 2: Select Interface and Development Platform
Choose the interface based on your development platform and data workflow. UVC is useful for camera-like depth data workflows. UDP is suitable for networked data streaming. UART can be practical for embedded systems and microcontroller-style integration. Development may involve x86 Windows, x86 Linux, ARM Linux, Raspberry Pi, Jetson, or other embedded platforms.
Step 3: Stream Depth Data
Depth maps and point clouds should be visualized before flight. Engineers should confirm range stability, frame rate, noise behavior, outdoor performance, and target reflectivity behavior. This stage is essential because it reveals real sensor behavior before the drone is allowed to react automatically.
Step 4: Build Obstacle Detection Logic
Start with simple and explainable logic. Define a region of interest, calculate the nearest valid obstacle distance, set warning and stop thresholds, apply temporal filtering, ignore invalid pixels, and log distance over time. Once the basic system is reliable, more advanced behavior such as lateral rerouting or contour following can be added.
Step 5: Connect to Flight Controller
Avoidance commands can be implemented as velocity reduction, brake command, guided-mode position offset, mission pause, altitude change, or obstacle distance message. Start with non-aggressive behavior such as warning logs or speed limiting before enabling automatic motion commands. The flight controller should also know what to do if the sensor stream is lost.
Step 6: Validate in Simulation and Controlled Flight
Validation should progress from bench testing to controlled flight. Engineers should perform sensor bench tests, static obstacle tests, tethered hover tests, low-speed manual flights, assisted autonomous flights, and full mission validation. Each stage should include logging so failures can be reproduced and corrected.
DTOF Solid State LiDAR HM-LD1 Specs for UAV Integration
The DTOF Solid State LiDAR HM-LD1 is a compact solid-state LiDAR module based on SPAD dToF technology. It is designed to deliver real-time depth images and 3D point cloud data for environmental perception. For an object avoidance drone, its compact size, low weight, depth output, and multiple interfaces make it suitable for prototyping and system deployment across UAVs, mobile robots, cameras, security systems, and embedded development platforms.
HM-LD1 supports indoor or nighttime ranging up to 25 m and outdoor daytime ranging up to 8 m, with a stated ranging accuracy of ±3 cm. It can support obstacle avoidance, distance detection, autonomous navigation, smart inspection, robotic vision development, UAV altitude hold, terrain following, SLAM support, autofocus, user presence detection, object recognition, volume measurement, and zone intrusion monitoring. Its UART, UDP, and UVC interfaces provide flexible integration options for PCs, Raspberry Pi, flight controllers, and embedded platforms.
| Specification | DTOF Solid State LiDAR HM-LD1 |
|---|---|
| Product Name | DTOF Solid State LiDAR HM-LD1 |
| Technology | SPAD dToF solid-state LiDAR |
| Dimensions | 43.5 mm × 30 mm × 26.5 mm |
| Weight | 28 g |
| Indoor Ranging Capability | 0.5–25 m |
| Outdoor Ranging Capability | 0.2–8 m |
| Ranging Accuracy | ±3 cm |
| Field of View | 60° horizontal × 45° vertical |
| Resolution | 40 × 30 |
| Frame Rate | 10 fps |
| Interfaces | UART / UDP / UVC |
| Operating Temperature | -20 ℃ to 60 ℃ |
| Power Consumption | 1.2 W |
| Supported Development Platforms | x86 Windows, x86 Linux, ARM Linux SDKs |
| Typical Applications | Obstacle avoidance, distance detection, autonomous navigation, altitude hold, terrain following, robotic vision, smart inspection, SLAM support |
Why 28 g Matters for Drone Payload Budgets
For UAV design, 28 g is meaningful because sensor mass affects flight time, payload allocation, center of gravity, and mounting flexibility. A compact object avoidance drone may need multiple sensors, a companion computer, battery reserve, payload camera, and protective housing. Keeping the depth sensor lightweight gives engineers more freedom to design a complete system without exceeding the airframe’s payload budget.
Using 60° × 45° FOV for Front or Downward Sensing
The 60° horizontal by 45° vertical field of view can be used for forward obstacle detection, downward altitude assistance, or angled terrain awareness. For forward sensing, engineers should align the field of view with the drone’s motion corridor. For downward sensing, the field should cover the expected landing or terrain following zone. The best mounting angle depends on mission speed, stopping distance, airframe geometry, and obstacle type.
Indoor and Outdoor Range Planning
The HM-LD1 supports indoor ranging from 0.5 m to 25 m and outdoor ranging from 0.2 m to 8 m. Developers should design avoidance thresholds around the actual environment. Indoor and nighttime testing may show longer useful range, while bright outdoor environments require conservative speed limits and safety buffers. Outdoor validation should include sunlight, dark surfaces, reflective targets, angled surfaces, and real mission distances.
Interface Selection: UART, UDP, and UVC
UART, UDP, and UVC support different integration workflows. UVC can make the module easier to evaluate in camera-like development environments. UDP can support networked streaming to a companion computer. UART can fit embedded control designs where simple data exchange is preferred. Interface choice should consider bandwidth, software stack, processor type, cable routing, and the reliability requirements of the flight system.
SDK Support for Windows, Linux, and ARM Linux
MRP offers SDK support for x86 Windows, x86 Linux, and ARM Linux, enabling development across common operating systems and processor architectures. This is useful for teams moving from lab evaluation to embedded deployment. A team may begin on a PC for visualization, then migrate to a Raspberry Pi, Jetson, or ARM Linux platform for flight testing.
Review the full specifications and integration resources for the DTOF Solid State LiDAR HM-LD1. You can also download the DTOF SSL HM-LD1 Product Brochure for additional product information.
View Product Details & Pricing ➔
Testing and Validation for Safer Avoidance Behavior
Object avoidance must be tested as a full system, not just as a sensor demo. A sensor may measure distance correctly on a bench, but the drone may still respond too late if the processing pipeline, decision logic, communication timing, or flight controller behavior is not tuned correctly. Validation should focus on the entire chain from depth measurement to motor response.
Bench Testing Sensor Output
Bench testing should confirm that the sensor streams data reliably and that the development platform can read it continuously. Engineers should view depth maps, inspect point cloud behavior, test targets at multiple distances, and record data for later analysis. This stage should include dark surfaces, reflective materials, angled boards, thin poles, and partial obstacles.
Static Obstacle Testing
Static obstacle testing allows engineers to validate region-of-interest logic and threshold behavior without flight risk. Place walls, boxes, poles, and surfaces at known distances. Confirm that the system reports distance accurately enough for the mission and that warning zones trigger consistently.
Dynamic Obstacle Testing
Dynamic testing evaluates moving people, carts, doors, vehicles, or swinging objects. The goal is to see how quickly the system responds to changing depth data. For commercial UAVs, dynamic obstacles are common in warehouses, construction sites, and inspection environments.
Outdoor Bright-Light Testing
Outdoor testing should not be skipped. Bright sunlight, high-lux conditions, weather variation, surface reflectivity, and target angle can affect sensor performance. Developers should test realistic mission conditions rather than relying only on indoor laboratory results.
Flight Envelope and Safety Margin Validation
A simplified safety model should include reaction distance, braking distance, and safety buffer. Reaction distance depends on sensor frame rate, data transfer time, processing latency, decision logic, and command delay. Braking distance depends on drone speed, mass, controller tuning, wind, and available thrust. The safety buffer accounts for uncertainty, measurement variation, and environmental change.
Logging, Replay, and Failure Analysis
Raw depth data, filtered distance, flight speed, command output, flight-controller response, and mission state should be logged. Without logs, it is difficult to determine whether a failure came from the sensor, algorithm, communication layer, or flight dynamics. Replay tools are especially useful because they allow engineers to tune thresholds and filtering without repeating every flight test.
Industrial Applications for Object Avoidance Drones
Object avoidance drones are valuable wherever UAVs operate near structures, equipment, terrain, people, or confined spaces. The strongest business case appears when the drone carries expensive payloads, performs repetitive autonomous work, or flies in environments where pilot visibility is limited.
Bridge, Dam, and Infrastructure Inspection
Infrastructure inspection requires close but safe distance control. A drone may need to approach concrete, steel, cables, beams, or retaining walls while maintaining a safe standoff distance for imaging. Depth sensing can help reduce collision risk and support more repeatable inspection paths.
Warehouse and Indoor Inventory Drones
Warehouse drones operate around shelving, racks, forklifts, pallets, walls, and personnel. GNSS is usually unavailable indoors, and the environment can change daily. Local obstacle avoidance helps the drone operate more safely during inventory scans, aisle navigation, and autonomous docking.
Construction Site Monitoring
Construction sites change frequently. Temporary materials, cranes, scaffolding, vehicles, and people can appear in areas that were previously clear. Object avoidance can provide real-time protection when maps or mission plans do not reflect the current site layout.
Security Patrol and Perimeter Monitoring
Security drones may operate at night or in low-light conditions, making active depth sensors useful. A drone that patrols near fences, buildings, gates, vehicles, and vegetation can benefit from distance-aware behavior that reduces risk during autonomous routes.
Agriculture and Terrain Following
Agricultural drones may use downward or angled sensing to support terrain following and low-altitude operation. Uneven ground, slopes, crops, irrigation equipment, and tree rows can create obstacle risks that require real-time perception.
Robotics Research and UAV Development Platforms
Research teams benefit from sensors with standard interfaces, SDK support, and compact form factors. A small dToF LiDAR module can support experimentation in depth sensing, autonomous drone navigation, SLAM support, obstacle detection, and robotic vision.
Common Engineering Mistakes to Avoid
Many object avoidance drone projects fail not because the sensor is unusable, but because the system is designed or validated incorrectly. Avoidance is a control problem as much as a perception problem. Engineers should avoid the following mistakes during design and testing.
Mistake 1: Treating Detection as Avoidance
Detecting an obstacle does not guarantee that the drone can avoid it. The system must also understand distance, flight direction, speed, latency, and safe response behavior. A detection-only system may warn the operator but still fail to prevent impact.
Mistake 2: Ignoring Latency and Stopping Distance
Avoidance thresholds should account for sensor update rate, processing delay, command delay, and aircraft braking distance. A threshold that works at low speed may be unsafe at higher speed. Conservative speed limits are essential during early development.
Mistake 3: Mounting the Sensor in a Blind or Vibrating Location
Sensors should be mounted where they have an unobstructed view and stable mechanical support. Propellers, landing gear, payloads, and frame parts can create false detections or blind zones. Vibration can reduce data consistency and should be evaluated during motor-on tests.
Mistake 4: Testing Only Indoors
Indoor testing is useful, but outdoor sunlight, reflective surfaces, dark materials, weather, and long-distance scenes can produce different results. If the drone will fly outdoors, it must be validated outdoors under realistic conditions.
Mistake 5: Using One Threshold for Every Flight Speed
Avoidance distance should scale with velocity. A slow indoor drone may safely stop within a short distance, while a faster outdoor drone needs more warning range. Thresholds should be tuned to the flight envelope and mission mode.
Mistake 6: Not Logging Raw Sensor Data
Raw sensor data is essential for debugging. If the drone behaves incorrectly, logs help determine whether the obstacle was missed, filtered out, interpreted incorrectly, or acted on too late. Logging also supports algorithm improvement and customer validation.
FAQ: Object Avoidance Drone Development
Why does my drone detect obstacles but still fail to avoid them?
Is obstacle avoidance worth the extra cost for commercial or development drones?
Where should I start if I am building an autonomous drone with object detection and avoidance?
What type of sensor is best for an object avoidance drone?
How much range does a drone obstacle avoidance sensor need?
Can dToF LiDAR work outdoors on drones?
Where should LiDAR sensors be mounted on a drone?
Is a depth map better than a single distance reading for drone avoidance?
What frame rate is needed for drone obstacle avoidance?
Can object avoidance replace a skilled drone pilot?
Building an object avoidance drone for inspection, navigation, or robotics development? Explore the compact DTOF Solid State LiDAR HM-LD1 and review its depth sensing capabilities, interfaces, SDK support, and UAV integration potential.
📚 References & Further Reading
- Industry Standard: Trimble and Luminar Technologies
- Related Guide: what is LiDAR technology, dToF LiDAR imagery and depth maps, and RTK receptor vs receiver








