


In urban canyons, forests, under bridges, inside factories, and in mining sites, one of the most common failure scenarios for drones is this: when GNSS signals weaken, positioning becomes unstable; when signals are lost, the EKF quickly diverges.
The real solution to these engineering challenges is not simply adding another RTK module, but using a fully integrated system—a complete hardware stack from the same provider, combining vision, IMU, and GNSS/RTK, along with a tightly coupled sensor fusion engine.
– When satellites are available: RTK provides global positioning
– When signals are weak or lost: stereo VIO/VINS maintains continuity
– When signals recover: the system quickly re-aligns to global accuracy
Below is a practical, “ready-to-deploy” recommendation list, categorized into lightweight airborne, industrial-grade, and high-reliability modular systems. Key parameters are included for each option, such as weight, dimensions, power consumption, and most importantly, GNSS outage drift performance (expressed as a percentage of distance traveled).
Ⅰ Key Metric: Drift During GNSS Outage (Distance Percentage)
Engineers prefer metrics like ‘0.75% of distance traveled’ because it directly answers: If you fly 1 km without GNSS, how far will it drift?
– 0.75% ≈ 7.5 m per km
– 1% ≈ 10 m per km
Different products report this type of metric. For example, Fixposition Vision-RTK 2, Xsens Vision Navigator, Link Robotics VINS-RTK, Kindhelm IPESSA RTK-VINS, and Inertial Labs VINS have all provided similar specifications in their publicly available documentation.
Ⅱ Recommended Options (Categorized by Drone Payload Capacity)
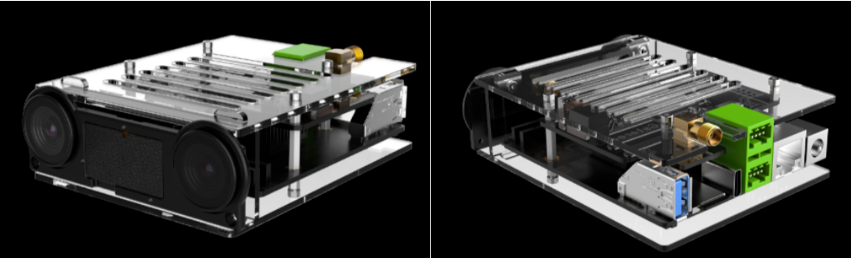
① Lightweight Airborne (100g-Class): RoboBaton VIOBOT2 (China)
If you’re looking for a solution that is lightweight, provides direct pose output, and supports GNSS/RTK fusion, VIOBOT2 is one of the most practical off-the-shelf options in this category.
- Dimensions / Weight / Power: 78 × 101 × 33 mm / 138 g / ~11 W
- Output & Fusion: Built-in VIO and GVIO pose output (200 Hz), with support for coupling onboard GNSS data and RTK fusion
Best suited for:
Small to medium multirotor drones, research validation, and applications where the positioning module is used as an independent onboard sensor.
② Mid-Range “Plug-and-Play” (400g-Class): Fixposition Vision-RTK 2 (International)
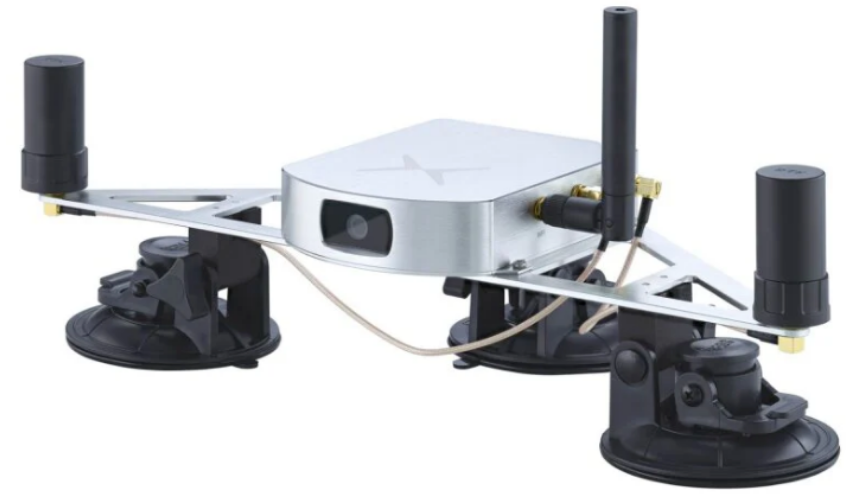
If you’re looking for a solution that works out of the box—with full ROS support and stable performance even during GNSS outages—Vision-RTK 2 is a representative option.
- Turnkey Kit: Delivered as a complete system including sensor unit, RTK antenna, cables, and battery. Emphasizes plug-and-play deployment with ROS1/ROS2 drivers.
- GNSS Outage Performance: Drift of approximately 0.75% of distance traveled (DT), as reported in official documentation.
- Power & Form Factor: Typical power consumption ~7.5W; enclosed version measures 113 × 130 × 30 mm / 420 g (lighter OEM board + camera configurations are also available).
Best suited for:
Teams requiring rapid deployment, testing in urban or forested weak-signal environments, and projects with strong software ecosystem demands.
③ Same Class, More “Navigation Module” Oriented: Xsens Vision Navigator (International)
If your preference is a dedicated navigation module rather than a camera-centric system, Vision Navigator offers a more direct approach. It is a tightly integrated vision + dual RTK GNSS/INS navigation module.
- Performance: Official documentation states reliable positioning in GNSS-denied environments using Visual Inertial Odometry, with ~0.75% DT drift during GNSS outages.
- Specifications: 129 × 114 × 30 mm / 420 g, ~10W power consumption, up to 200 Hz output, compatible with ROS1/ROS2.
Best suited for:
Applications where an industrial-grade navigation module is required to interface directly with flight controllers or onboard systems, rather than being used as a camera device.
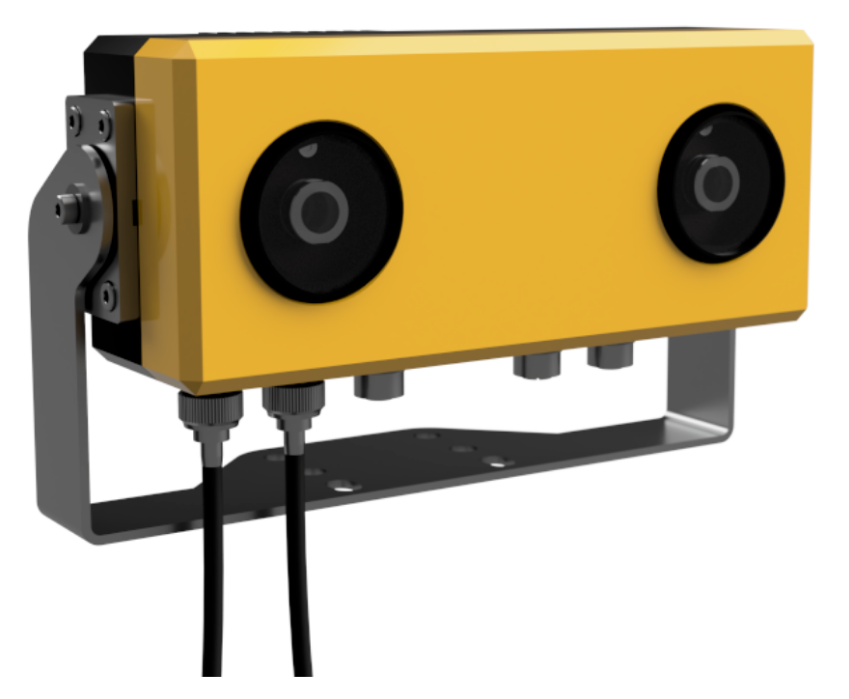
④ Industrial Heavy Payload (1kg+): Kindhelm IPESSA RTK-VINS (International)
For platforms with sufficient payload capacity and a need for long-duration operation in mapped environments without GNSS, IPESSA represents an industrial-grade solution.
- System Architecture: Stereo vision + IMU + dual-antenna multi-frequency RTK-GNSS, with integrated RTK-VINS fusion and SLAM.
- Performance: Dead-reckoning drift <1% DT; capable of maintaining global positioning in pre-mapped environments using SLAM after GNSS loss (based on official claims).
- Weight: Starts from 1050 g (short baseline) and can reach up to 2 kg (long baseline configurations).
Best suited for:
Industrial UAVs, VTOL platforms, and heavy-duty autonomous systems.
⑤ Modular High-Reliability System: Inertial Labs VINS (International)
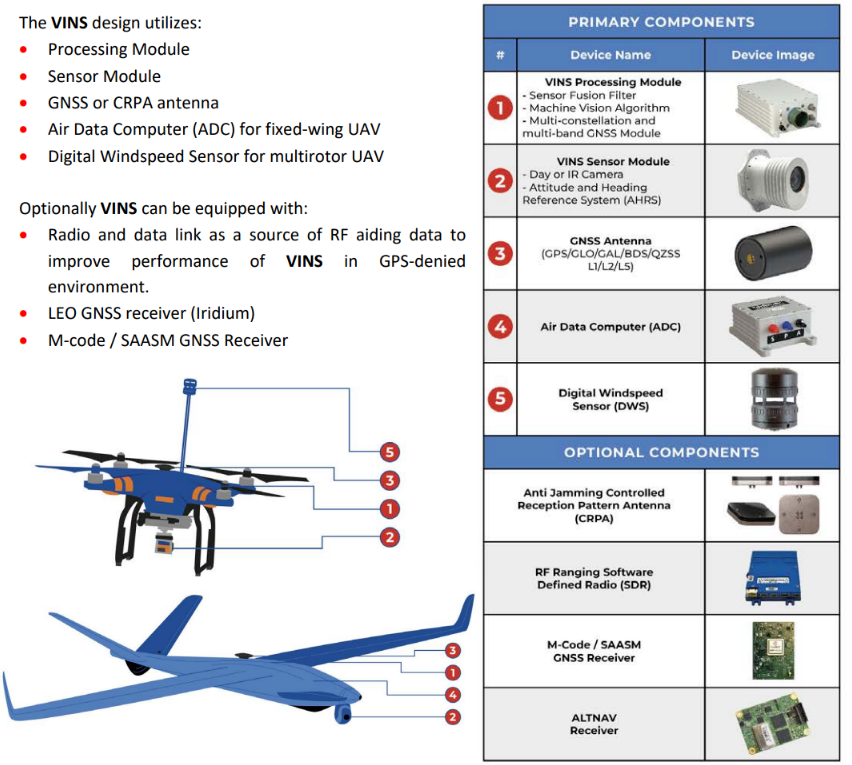
For applications requiring higher reliability, strong interference resistance, or mission-critical performance, Inertial Labs VINS provides a modular, system-level solution.
- System Design: Composed of sensor modules, processing unit, and GNSS antennas. The processing unit integrates multi-frequency, multi-constellation GNSS with support for PPP and RTK.
- Performance in GNSS-Denied Environments: Horizontal positioning drift (Visual Odometry) <1% DT, typically 0.5–1%.
Best suited for:
Applications prioritizing system-level robustness, environmental adaptability, and long-duration operational reliability.
Ⅲ Selection Guidelines (Avoid Common Pitfalls)
- Start with GNSS outage drift (%DT):
This metric reflects real-world performance in weak or no-signal conditions far better than “advertised centimeter-level RTK accuracy.” - Then evaluate weight, power, and interfaces:
For multirotor platforms, payload capacity and power constraints are often the primary limiting factors. - Finally, consider the ecosystem:
Check for ROS1/ROS2 support, as well as the availability of mature configurations and example workflows (Fixposition and Xsens both emphasize strong ROS integration and documentation).
Ⅳ My Recommendations
- If you need a lightweight solution for rapid validation in weak GNSS environments, start with VIOBOT2 (100g-class, China).
- If you want a plug-and-play system with a mature ecosystem and stable performance during GNSS outages, solutions like Fixposition Vision-RTK 2 or Xsens Vision Navigator (400g-class) are more suitable.
- If your application requires an industrial-grade solution with sufficient payload capacity and map-level relocalization capabilities, consider Kindhelm IPESSA RTK-VINS.
Final Note: Don’t Be Misled by “GNSS-Free Navigation”
No matter how advanced, pure vision has its limits.
Highly reflective surfaces, rain, fog, snow, low-texture environments, and extreme low-light conditions can all degrade the performance of VIO/VINS.
A reliable engineering approach is clear:
use RTK whenever possible for global accuracy,
rely on VINS to maintain continuity when GNSS is weak or unavailable,
and rapidly re-converge once satellite signals are restored.








