Customer Communication Version | Outdoor Distance Measurement Test Report
| Test Product | HM-LD1 dToF LiDAR |
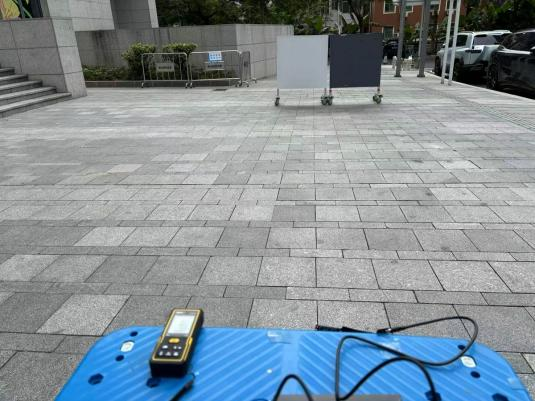
| Test Mode | Static test based on actual obstacle sensing requirements |
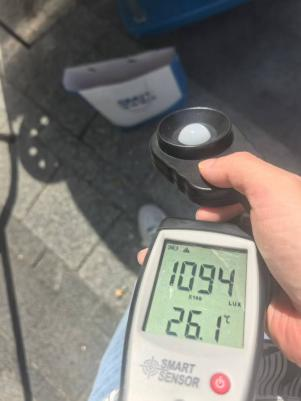
| Test Environment | Outdoor strong-light environment, approx. 109 klux sunlight illuminance |
| Test Targets | 10% & 70% reflectance boards |
| Report Contents | Test overview, front-light/back-light distance data, error statistics, raw screenshots, and conclusions |
| This report is compiled from three original Excel test spreadsheets. It preserves the original test data and data screenshots, and adds error statistics and charts to help customers quickly understand the distance measurement performance of HM-LD1 under outdoor strong-light conditions. |
1. Test Overview and Key Conclusions
Calculation basis: Difference = True Distance – Measured Distance; MAE = Mean Absolute Error; RMSE = Root Mean Square Error.
| Scenario | Samples | Range (m) | Mean Diff. (m) | MAE (m) | Max Abs. Error (m) | RMSE (m) | Mean Rel. Abs. Err. |
| Front-light | 11 | 0.30-8.00 | 0.055 | 0.055 | 0.090 @ 8.0m | 0.058 | 3.41% |
| Back-light | 11 | 0.30-8.00 | 0.034 | 0.043 | 0.140 @ 8.0m | 0.060 | 1.49% |
| Overall | 22 | 0.30-8.00 | 0.044 | 0.049 | 0.140 @ 8.0m | 0.059 | 2.45% |
| Under the 109 klux outdoor strong-light environment, HM-LD1 can output valid distance data within the 0.3-8 m range. The front-light scenario has an MAE of approximately 0.055 m, with a maximum absolute error of approximately 0.090 m; the back-light scenario has an MAE of approximately 0.043 m, with amaximum absolute error of approximately 0.140 m. From the perspective of obstacle avoidanceapplications, it is recommended to reserve a safety distance margin in real projects based on targetreflectance, installation angle, and ambient light changes, and to combine ROI and threshold strategies for scenario-specific tuning. |
2. Test Conditions and Site Photos
| Item | Content |
| Test Mode | Tested based on actual obstacle sensing requirements |
| Test Status | Static test |
| Test Environment | Outdoor, November 21 & 25, 2025, 14:00-16:00, approx. 109 klux sunlight illuminance |
| Test Targets | 10% & 70% reflectance boards |
| Distance Range | Front-light: 0.3-8 m; Back-light: 0.3-8 m |
| Original Note | The summary table marks the 0.3-1.2 m range as 500 ps and the 2-8 m range as 1000 ps |
Site Photo 1
Site Photo 2
3. Front-light Environment: Distance Test Data
Under the front-light environment, the measured distance was generally lower than the true distance, with a difference range of approximately 0.02-0.09 m.
| No. | True Distance(m) | MeasuredDistance(m) | Difference(m) | Absolute Error(m) | PCD File |
| 1 | 0.30 | 0.27 | 0.03 | 0.03 | front-light/0d3.pcd |
| 2 | 0.40 | 0.36 | 0.04 | 0.04 | front-light/0d4.pcd |
| 3 | 0.70 | 0.68 | 0.02 | 0.02 | front-light/0d7.pcd |
| 4 | 1.20 | 1.16 | 0.04 | 0.04 | front-light/1d2.pcd |
| 5 | 2.00 | 1.93 | 0.07 | 0.07 | front-light/2.pcd |
| 6 | 3.00 | 2.94 | 0.06 | 0.06 | front-light/3.pcd |
| 7 | 4.00 | 3.94 | 0.06 | 0.06 | front-light/4.pcd |
| 8 | 5.00 | 4.95 | 0.05 | 0.05 | front-light/5.pcd |
| 9 | 6.00 | 5.94 | 0.06 | 0.06 | front-light/6.pcd |
| 10 | 7.00 | 6.92 | 0.08 | 0.08 | front-light/7.pcd |
| 11 | 8.00 | 7.91 | 0.09 | 0.09 | front-light/8.pcd |
Front-light statistics: MAE = 0.055 m, maximum absolute error = 0.090 m, RMSE = 0.058 m.
4. Back-light Environment: Distance Test Data
Under the back-light environment, errors from 0.3-7 m were generally small, while the largest error in this group occurred at 8 m.
| No. | True Distance(m) | MeasuredDistance(m) | Difference(m) | Absolute Error(m) | PCD File |
| 1 | 0.30 | 0.29 | 0.01 | 0.01 | back-light/0d3.pcd |
| 2 | 0.60 | 0.58 | 0.02 | 0.02 | back-light/0d6.pcd |
| 3 | 0.80 | 0.79 | 0.01 | 0.01 | back-light/0d8.pcd |
| 4 | 1.00 | 0.99 | 0.01 | 0.01 | back-light/1.pcd |
| 5 | 2.00 | 2.01 | -0.01 | 0.01 | back-light/2.pcd |
| 6 | 3.00 | 3.04 | -0.04 | 0.04 | back-light/3.pcd |
| 7 | 4.00 | 3.99 | 0.01 | 0.01 | back-light/4.pcd |
| 8 | 5.00 | 4.95 | 0.05 | 0.05 | back-light/5.pcd |
| 9 | 6.00 | 5.91 | 0.09 | 0.09 | back-light/6.pcd |
| 10 | 7.00 | 6.92 | 0.08 | 0.08 | back-light/7.pcd |
| 11 | 8.00 | 7.86 | 0.14 | 0.14 | back-light/8.pcd |
Back-light statistics: MAE = 0.043 m, maximum absolute error = 0.140 m, RMSE = 0.060 m.
5. Data Visualization Analysis
The charts below provide a quick comparison between true distance and measured distance, as well as the error trend under different lighting directions.
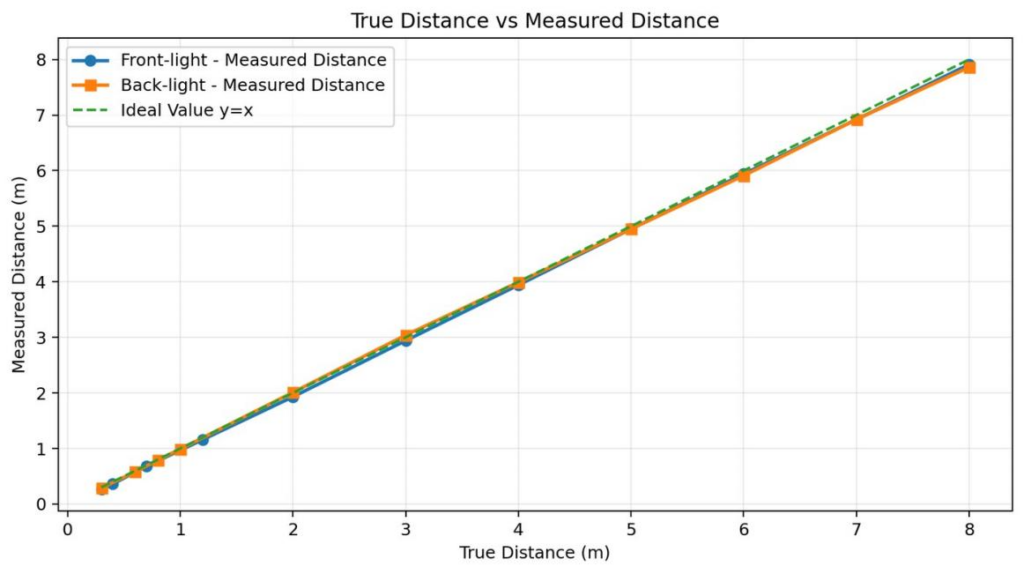
Figure 1 Comparison of True Distance and Measured Distance
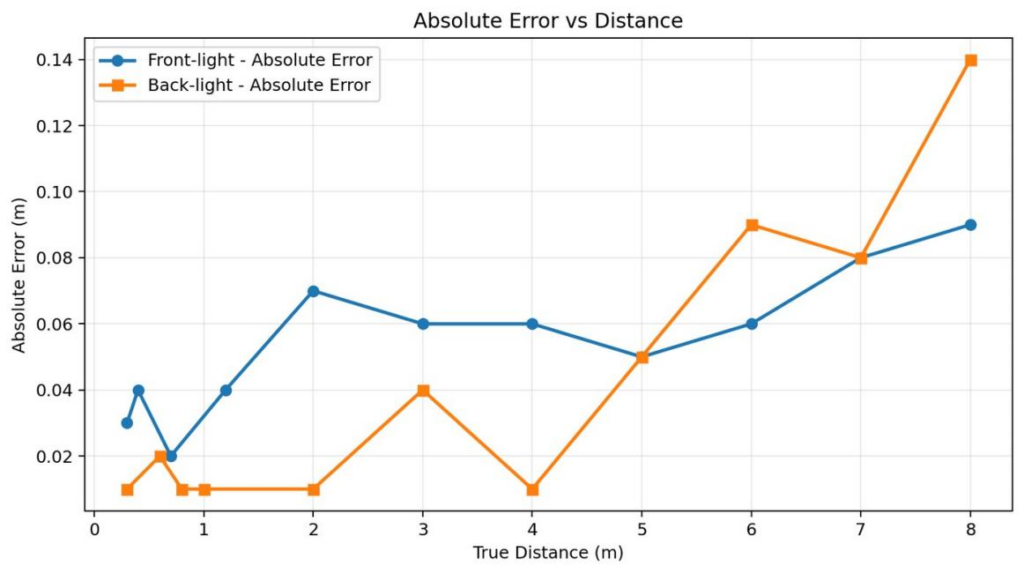
Figure 2 Absolute Error vs Distance
6. Customer-facing Conclusions and Recommendations
| Dimension | Conclusion / Recommendation |
| Distance Measurement Validity | In this outdoor strong-light test, HM-LD1 recorded valid measured distances across the 0.3-8 m range. |
| Front-light Performance | Front-light MAE is approximately 0.055 m, with a maximum absolute error of approximately 0.090 m. The overall deviation shows a trend where the measured distance is slightly lower than the true distance. |
| Back-light Performance | Back-light MAE is approximately 0.043 m, with a maximum absolute error of approximately 0.140 m. The error at 8 m is relatively higher. |
| Application Recommendation | For outdoor obstacle avoidance, it is recommended to set safety threshold margins based on target material, reflectance, mounting height, and lighting changes, and to make jointjudgments using ROI, distance thresholds, and point-count thresholds. |
| Further Validation | It is recommended to supplement the test with dynamic targets, materials with differentreflectance, different incidence angles, different weather/time periods, and actual obstacle avoidance tests after mounting on drones/UGVs. |
| Suggested customer communication wording: HM-LD1 is suitable for short-to-mid range outdoorobstacle sensing validation. Under strong sunlight, it maintains usable distance output across 0.3-8 m, with practical threshold margins recommended for real deployment. |
7. Appendix A: Raw Data Screenshots – Front-light Environment
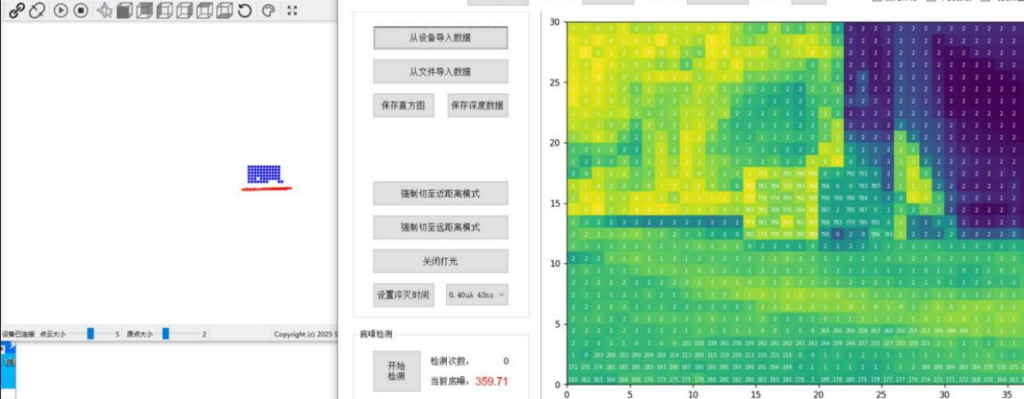
The following are data screenshots embedded in the original Excel sheets, arranged by test distance.
1. True Distance 0.30 m / Measured Distance 0.27 m / Difference 0.03 m / PCD: front-light/0d3.pcd
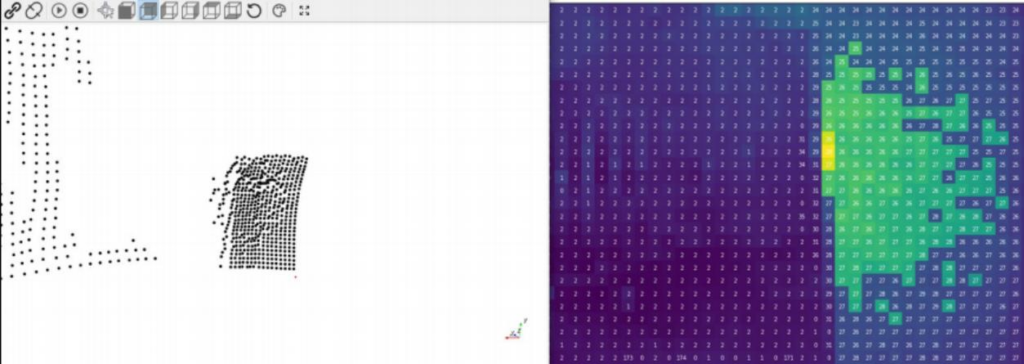
2. True Distance 0.40 m / Measured Distance 0.36 m / Difference 0.04 m / PCD: front-light/0d4.pcd
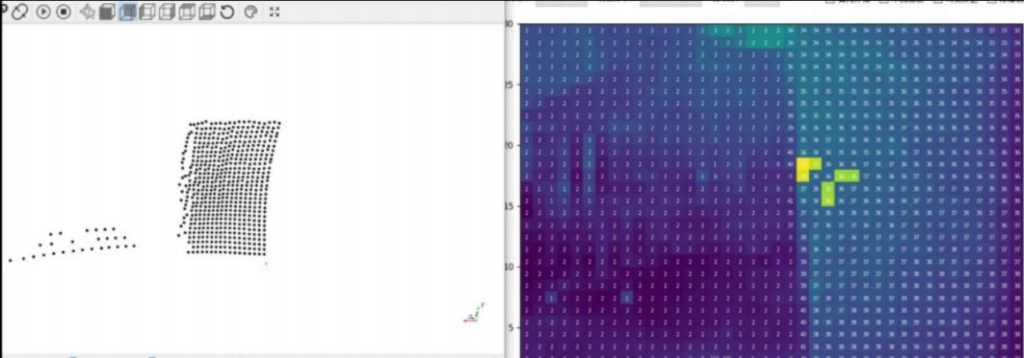
3. True Distance 0.70 m / Measured Distance 0.68 m / Difference 0.02 m / PCD: front-light/0d7.pcd
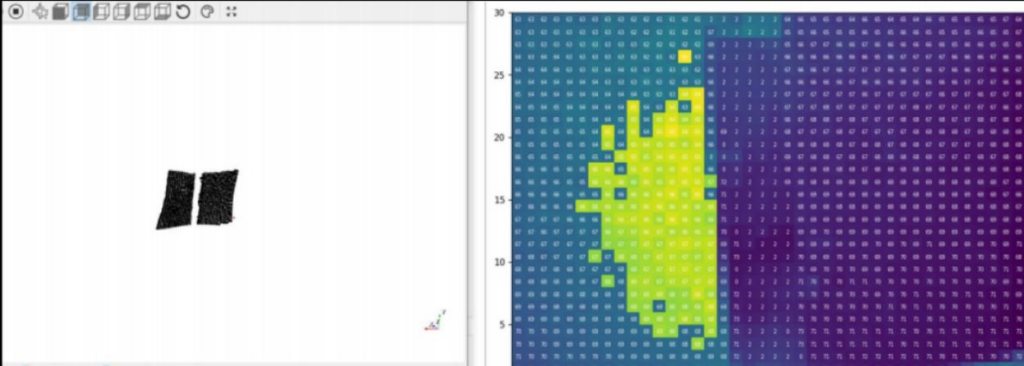
4. True Distance 1.20 m / Measured Distance 1.16 m / Difference 0.04 m / PCD: front-light/1d2.pcd
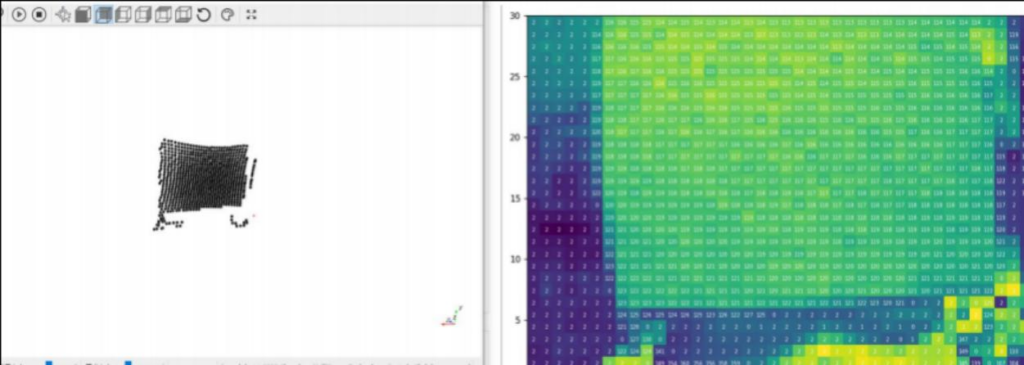
5. True Distance 2.00 m / Measured Distance 1.93 m / Difference 0.07 m / PCD: front-light/2.pcd
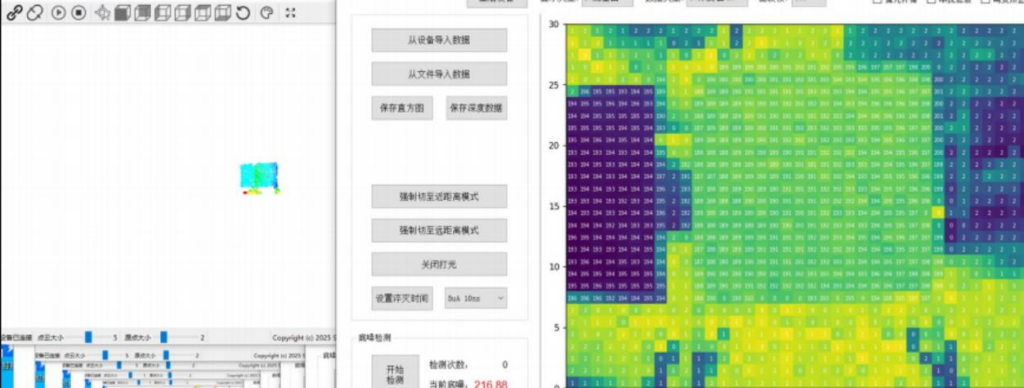
6. True Distance 3.00 m / Measured Distance 2.94 m / Difference 0.06 m / PCD: front-light/3.pcd
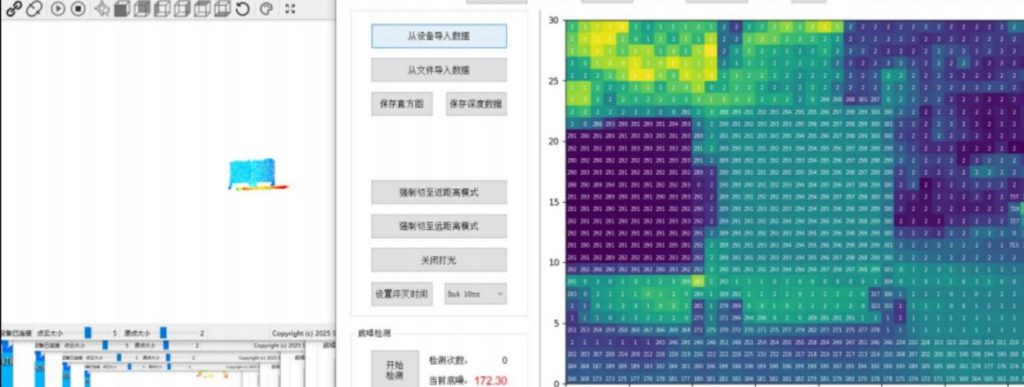
7. True Distance 4.00 m / Measured Distance 3.94 m / Difference 0.06 m / PCD: front-light/4.pcd
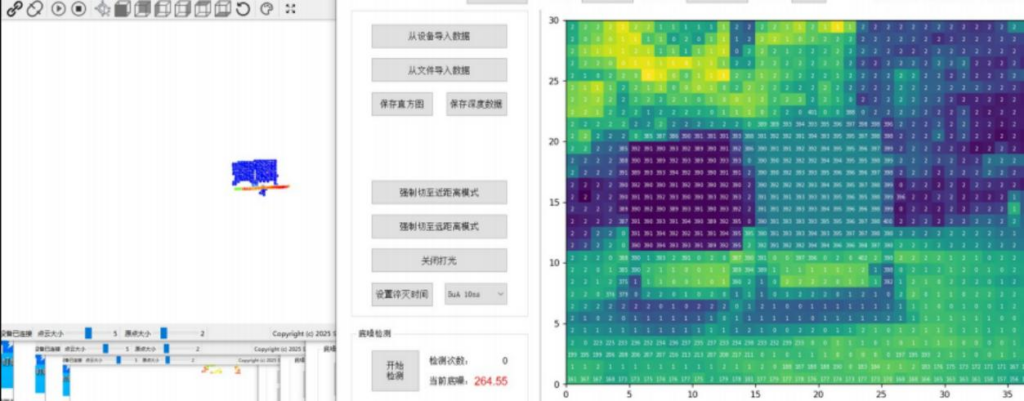
8. True Distance 5.00 m / Measured Distance 4.95 m / Difference 0.05 m / PCD: front-light/5.pcd
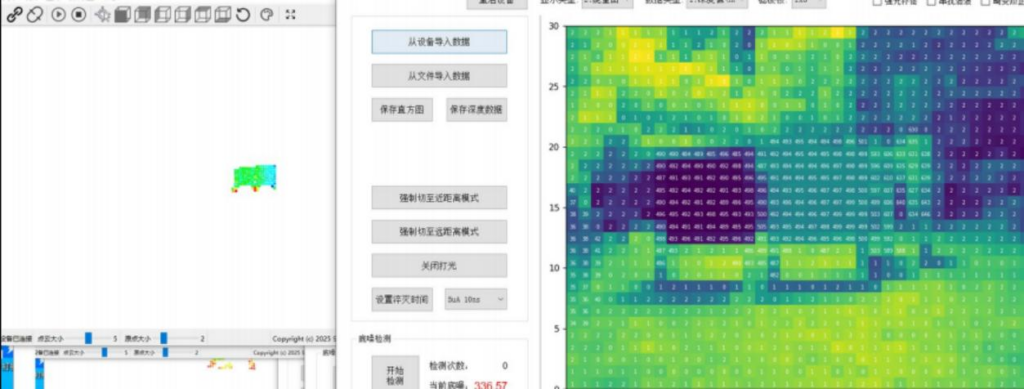
9. True Distance 6.00 m / Measured Distance 5.94 m / Difference 0.06 m / PCD: front-light/6.pcd
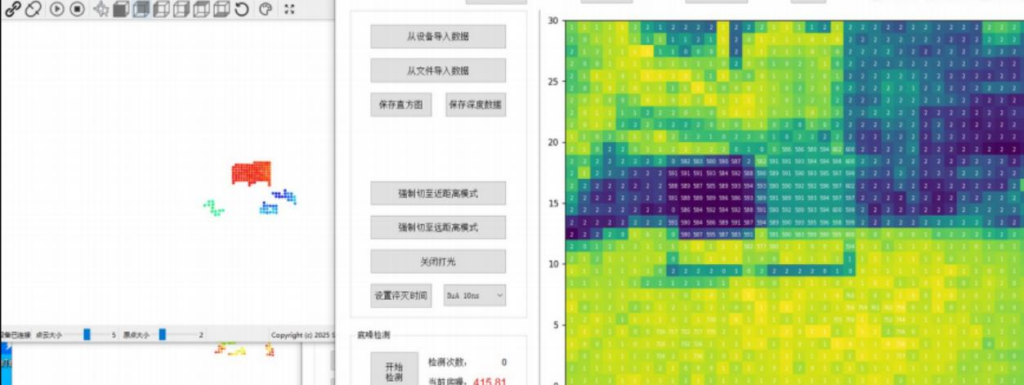
10. True Distance 7.00 m / Measured Distance 6.92 m / Difference 0.08 m / PCD: front-light/7.pcd
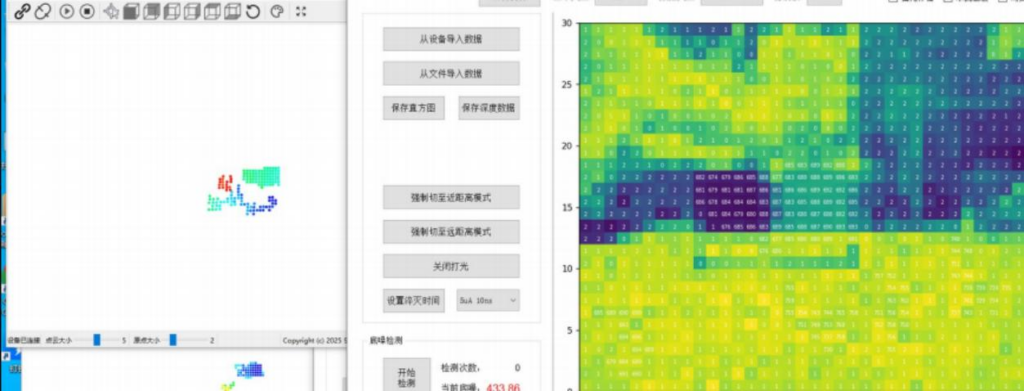
11. True Distance 8.00 m / Measured Distance 7.91 m / Difference 0.09 m / PCD: front-light/8.pcd
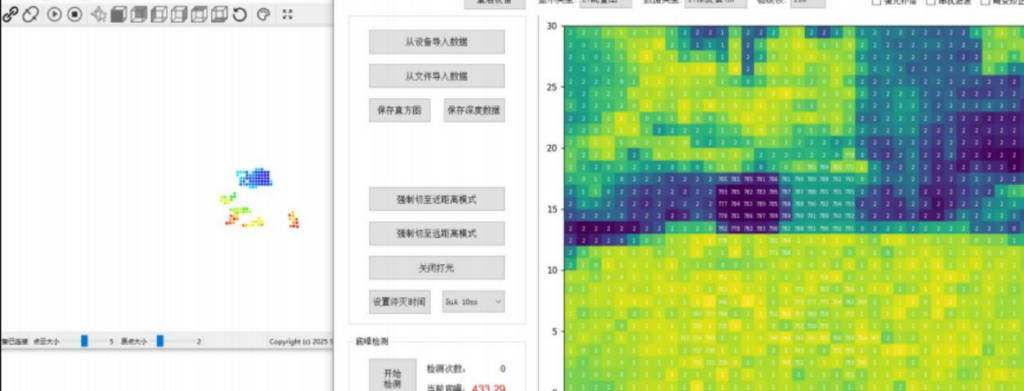
8. Appendix B: Raw Data Screenshots – Back-light Environment
The following are data screenshots embedded in the original Excel sheets, arranged by test distance.
1. True Distance 0.30 m / Measured Distance 0.29 m / Difference 0.01 m / PCD: back-light/0d3.pcd
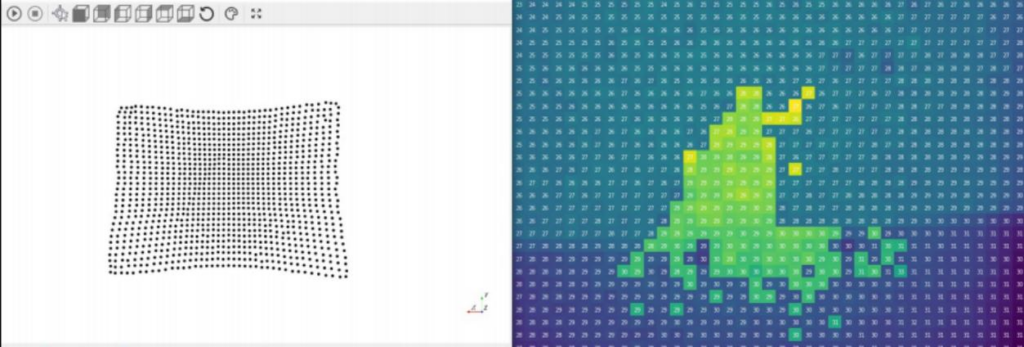
2. True Distance 0.60 m / Measured Distance 0.58 m / Difference 0.02 m / PCD: back-light/0d6.pcd
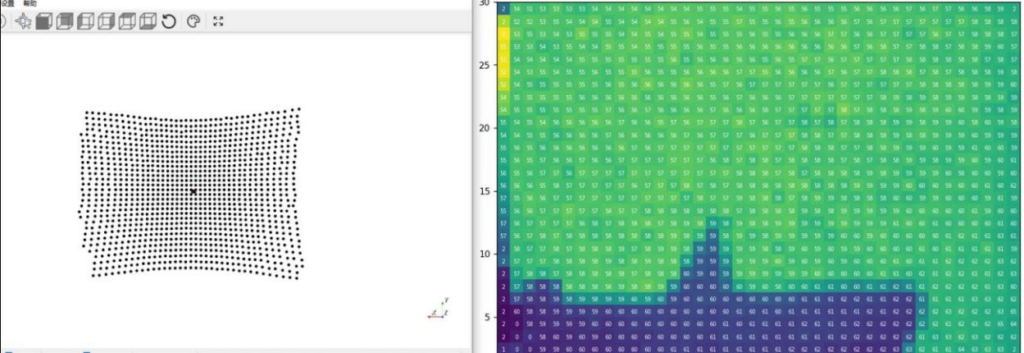
3. True Distance 0.80 m / Measured Distance 0.79 m / Difference 0.01 m / PCD: back-light/0d8.pcd
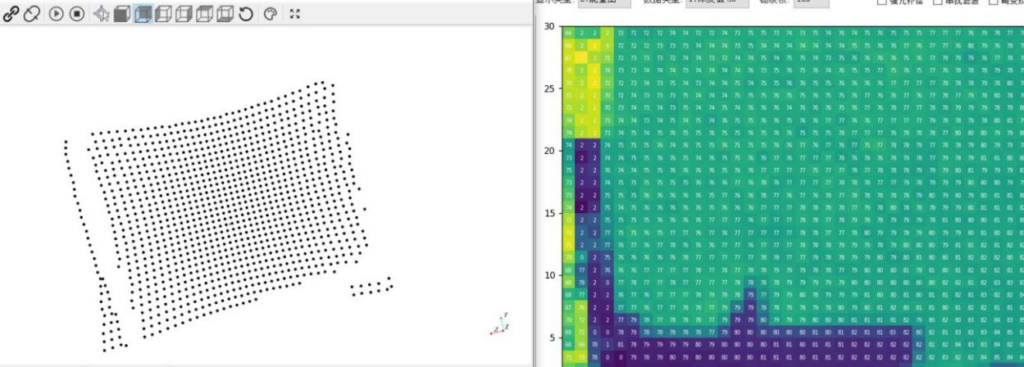
4. True Distance 1.00 m / Measured Distance 0.99 m / Difference 0.01 m / PCD: back-light/1.pcd
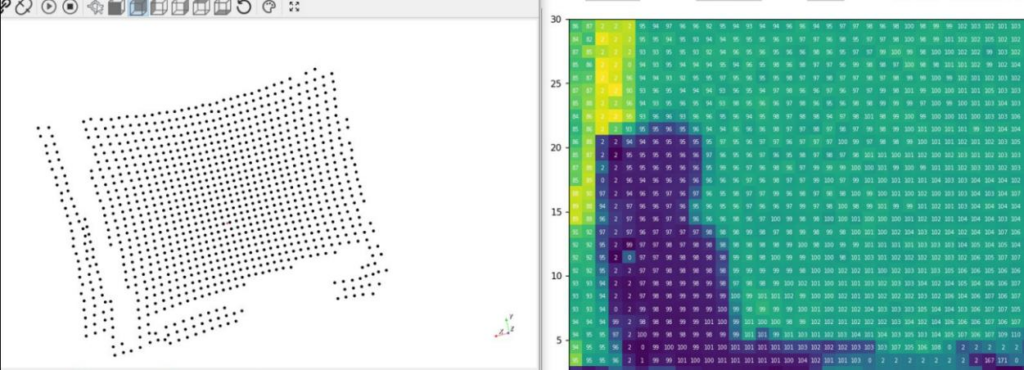
5. True Distance 2.00 m / Measured Distance 2.01 m / Difference -0.01 m / PCD: back-light/2.pcd
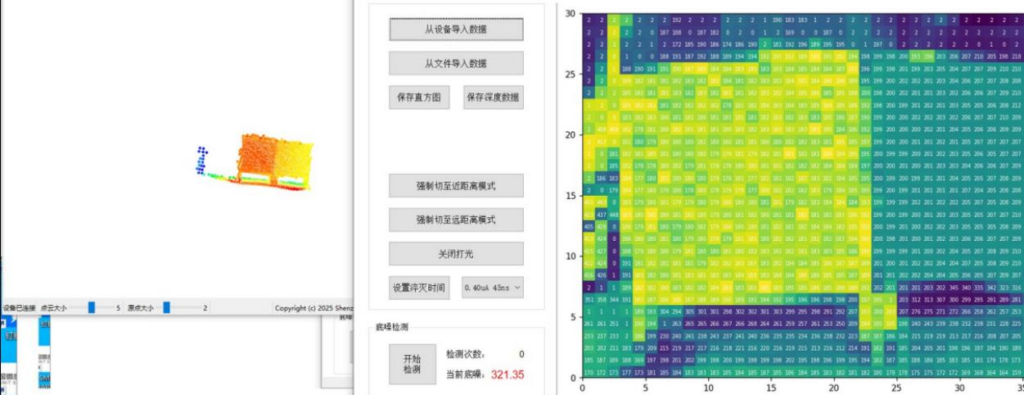
6. True Distance 3.00 m / Measured Distance 3.04 m / Difference -0.04 m / PCD: back-light/3.pcd
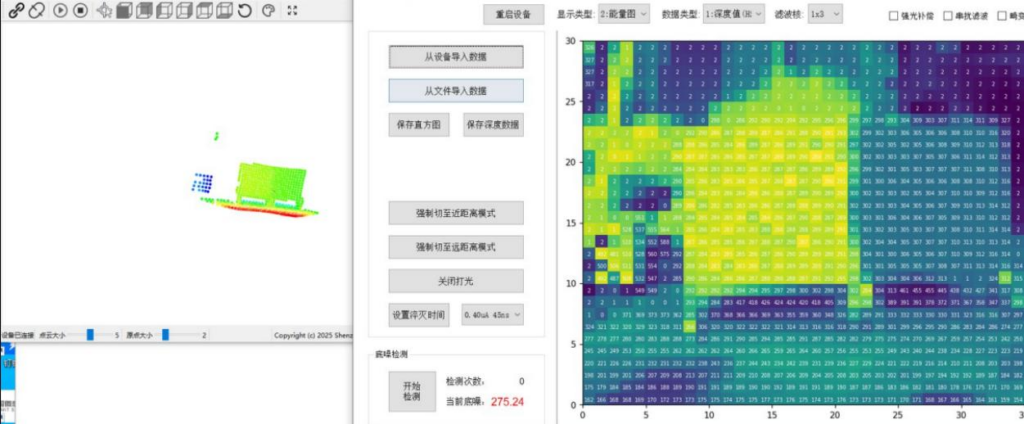
7. True Distance 4.00 m / Measured Distance 3.99 m / Difference 0.01 m / PCD: back-light/4.pcd
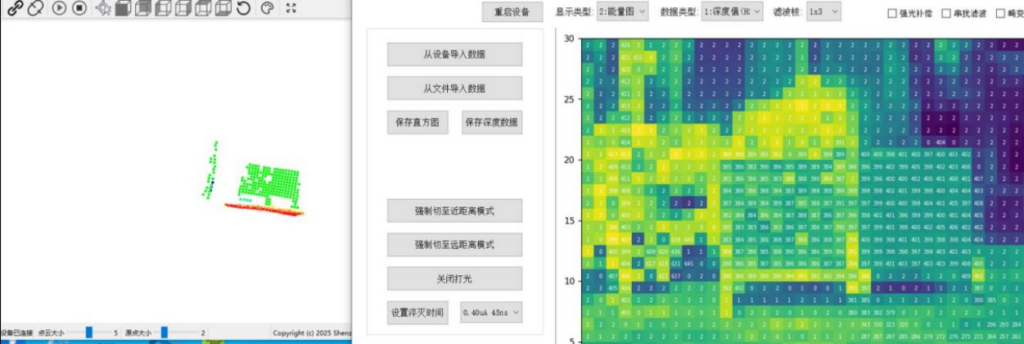
8. True Distance 5.00 m / Measured Distance 4.95 m / Difference 0.05 m / PCD: back-light/5.pcd
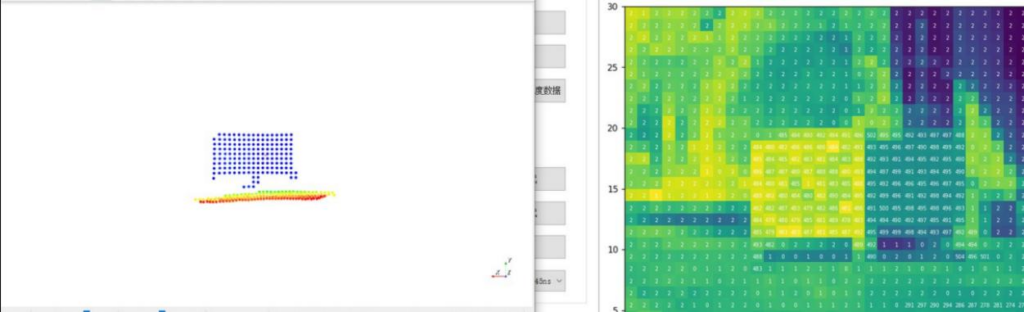
9. True Distance 6.00 m / Measured Distance 5.91 m / Difference 0.09 m / PCD: back-light/6.pcd
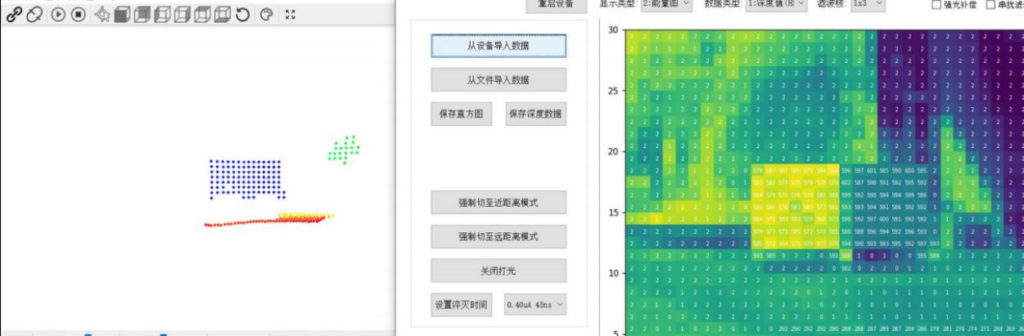
10. True Distance 7.00 m / Measured Distance 6.92 m / Difference 0.08 m / PCD: back-light/7.pcd
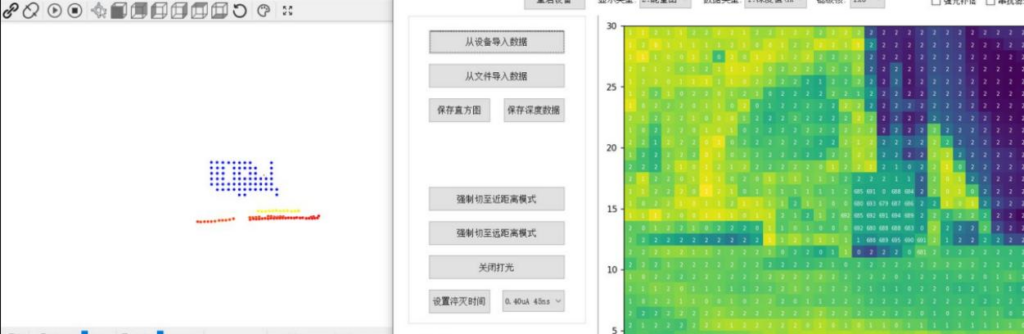
11. True Distance 8.00 m / Measured Distance 7.86 m / Difference 0.14 m / PCD: back-light/8.pcd