


LiDAR Scanner Arc Raiders Guide: Quest Locations, Uses, and Real-World 3D Sensing Explained
If you are searching for “lidar scanner arc raiders,” here’s the deal: you are probably stuck on one of the game’s more annoying objective problems. You may be trying to figure out where the scanner is, whether it is a fixed quest pickup or a loot-style item, and why areas like Dam Battlegrounds, Spaceport, control tower interiors, rooftops, industrial rooms, and stash screens keep coming up in player discussions. The frustration usually starts when you reach what looks like the right place, but there is no obvious pickup, no clean quest update, or no clear route upward.
This guide handles the game problem first, then ties the idea back to real LiDAR hardware. In Arc Raiders, the LiDAR scanner is best treated as a tactical or quest-related scanning device. In the shop, on a robot, or on a UAV, a real LiDAR scanner measures distance, builds depth data, and can produce 3D point cloud information for navigation, inspection, obstacle detection, and smart monitoring. A compact example is the DTOF Solid State LiDAR HM-LD1, a SPAD dToF LiDAR module with indoor 0.5–25 m ranging, outdoor 0.2–8 m ranging, ±3 cm accuracy, 60° × 45° FOV, 40 × 30 resolution, 10 fps frame rate, and UART, UDP, and UVC interfaces.
Table of Contents
- 👉 Quick Answer: LiDAR Scanner in Arc Raiders
- 👉 Where to Find the LiDAR Scanner in Arc Raiders
- 👉 How to Reach the Control Tower for the LiDAR Scanner Quest
- 👉 What Is the LiDAR Scanner Used For in Arc Raiders?
- 👉 Arc Raiders LiDAR vs Real-World LiDAR Scanners
- 👉 How dToF LiDAR Scanners Work
- 👉 Real Product Example: DTOF Solid State LiDAR HM-LD1
- 👉 Industrial Robotics and UAV Applications
- 👉 How to Choose a LiDAR Scanner for Robotics Projects
- 👉 Integration Notes for Developers
- 👉 Common Mistakes: In-Game and Real-World LiDAR
- 👉 FAQ: LiDAR Scanner Arc Raiders and Real-World LiDAR
Quick Answer: LiDAR Scanner in Arc Raiders
The LiDAR scanner in Arc Raiders is best understood as an objective-sensitive item or scanning-related quest object, not as a normal combat tool. Look, that matters. If you treat it like ammo, a weapon mod, or a random valuable, you can waste an entire raid searching the wrong containers. Players usually search for it because they are working through progression tied to surveillance, mapping, tower access, technical equipment, or scanner recovery.
The fastest way to handle it is to read the active quest text before you start running routes. If the wording mentions a tower, sky, surveillance, control equipment, signal gear, or scanning, assume the job may involve vertical access instead of a ground-floor pickup. On Dam Battlegrounds, prioritize technical buildings, control rooms, industrial interiors, communication equipment zones, rooftops, and elevated access points. On Spaceport, check operations rooms, hangar-side technical areas, tower-adjacent interiors, equipment crates, maintenance corridors, and upper platforms.
The biggest mistake is treating the scanner like ordinary loot. Quest items can behave differently from weapons, ammo, shields, or valuables. If you believe you found the scanner but the objective did not complete, check whether the item is in your stash, your carried inventory, your quest inventory, or still waiting for extraction. Some objectives depend not only on finding an item but also on carrying it to the right place, extracting with it, or interacting with a specific location.
That game logic lines up nicely with the real technology behind the word. A real compact solid-state LiDAR module measures distance and produces depth information for robots, drones, security devices, and inspection platforms. In both cases, the value is not visual flash. The value is spatial awareness.
Where to Find the LiDAR Scanner in Arc Raiders
Why Players Struggle to Find the Scanner
The “lidar scanner arc raiders” search is high-friction because the scanner is not always understood as a simple spawn. Players may assume it is a random loot item, a fixed quest object, a stash item, or an interactable device. Extraction shooters often mix all of those systems, so confusion is normal. You can be in the right map region and still fail if the quest is inactive, the required object is on another floor, the scanner must be extracted, or the item blends into a cluttered technical room.
Another source of confusion is map language. Players may hear Dam Battlegrounds, Spaceport, control tower, “Eyes in the Sky,” or scanner stash and combine multiple objectives into one messy search route. The better way is to separate the problem into three practical checks:
⚙️ Check the active quest wording first. Is it asking you to find, scan, deliver, extract, stash, or interact?
⚙️ Match the objective to a believable location. Scanning equipment usually belongs near control rooms, towers, communication gear, consoles, technical crates, and industrial interiors.
⚙️ Confirm the quest state before leaving. Do not assume the job is done just because you touched a scanner-looking object.
Dam Battlegrounds Search Pattern
Dam Battlegrounds is a strong search candidate when the objective wording suggests industrial infrastructure, monitoring systems, high ground, surveillance, or a control-room environment. Dams are built around machinery, concrete interiors, maintenance access, technical rooms, catwalks, service platforms, and elevated inspection points. That makes the map thematically suitable for scanner-related objectives. If you only search ground-level containers, you may miss the route entirely.
Start by identifying large structures with control-room potential. Search technical buildings, equipment rooms, interior offices, catwalk-adjacent areas, and rooftops. Then move toward communication structures, power-related interiors, and objective-marked locations. If you see a tower or elevated building, circle the base before entering and look for side doors, stairwells, exterior ladders, broken access routes, or adjacent rooftops. Many players reach the correct building footprint but never climb to the correct level.
Once you find a scanner-style object, do not leave immediately unless the objective clearly updates. Check the quest tracker and confirm whether the item is counted. If the scanner goes into inventory, take the safer extraction path instead of chasing unrelated loot. Here’s the deal with extraction games: a successful pickup does not mean much if you die five minutes later with the objective item still on you.
Spaceport Search Pattern
Spaceport is another logical search area because scanners fit naturally with launch infrastructure, radar-like equipment, operations rooms, logistics systems, hangars, maintenance corridors, and communications hardware. If your quest language points toward technical equipment, surveillance systems, aerospace-style control rooms, or high-value electronics, search Spaceport systematically instead of wandering from container to container.
Prioritize operations rooms, tower-adjacent interiors, tech crates, hangar-side equipment zones, elevated platforms, and maintenance corridors. Do not focus only on obvious loot containers. Scanner objectives may sit near terminals, consoles, shelves, equipment benches, or rooms that look functional rather than lucrative. In the shop, the most important tool is not always the shiny one on the bench. Same idea here.
The correct route may require moving through exposed areas, so avoid overloading your inventory before the objective is handled. A full backpack makes players cautious, and that caution often keeps them away from the risky vertical or technical path the quest actually requires. For scanner objectives, complete the job first, then decide whether the raid is worth extending.
Stash Confusion and Inventory Handling
Stash confusion is one of the most common reasons a player thinks the LiDAR scanner is bugged. In extraction games, ownership and quest progress are not always the same thing. An item in stash may not count as carried. A carried item may not count until extraction. An interactable scan may not create a physical item at all. A delivery objective may require the scanner to be brought into a raid rather than found during the same run.
After every attempt, check your quest inventory, stash inventory, objective tracker, extraction status, and task wording. If the scanner appears in stash but the quest remains incomplete, read whether the task requires delivery, deployment, scanning, extraction, or hand-in. If you are still searching, focus on technical environments instead of general loot routes.
For comparison, a real compact dToF LiDAR scanner module is also built around deployment context. It is not just a box that “sees.” It has to be mounted, powered, connected, calibrated, and used in the right operating environment. The game simplifies that, but the basic lesson holds: context matters.
How to Reach the Control Tower for the LiDAR Scanner Quest
Understanding the “Eyes in the Sky” Navigation Problem
The control tower objective is usually difficult because it is vertical. Many players reach the right map marker and still fail because they are standing below the correct floor, inside a nearby structure, or on the wrong side of the tower. In a dense extraction map, a marker can guide you horizontally while leaving the actual access path unclear. That creates the familiar loop: reach the area, search the ground floor, circle the building, fight enemies, leave confused, and repeat.
Think of the control tower as a route-finding problem, not just a location problem. The key is not only where the tower is, but how the level designers expect you to reach the upper control area. The scanner, terminal, or objective trigger may be near the top, inside a control room, on a landing, near a console, or beside technical equipment. If you do not climb, you may never trigger the interaction.
Route-Finding Principles
Start outside the tower and identify the full structure. Do not rush through the first door you see. Circle the base and look for stairwells, side entrances, exterior ladders, maintenance platforms, roof connections, and broken access routes. If there is an adjacent building with roof access, it may connect to the tower indirectly. If there are exterior platforms, check whether they wrap around to a higher door or ladder.
Use a shop-floor mindset: inspect the structure before touching the controls. The route usually gives itself away once you stop staring only at the marker. Move upward one section at a time. Clear each landing before continuing because tower routes are exposed and can trap you between PvE threats and other players.
⚙️ Circle the tower base before entering.
⚙️ Check side doors, ladders, broken stairs, and roof connections.
⚙️ Move upward slowly and clear each landing.
⚙️ Watch for quest prompts near consoles, cases, and equipment panels.
⚙️ Confirm the objective update before extracting.
Why Players Get Stuck
Players usually get stuck by entering the wrong nearby structure, mistaking an antenna or industrial frame for the control tower, missing a side entrance, ignoring exterior access, or leaving before the quest state updates. Another common issue is approaching from a poor angle. The visible side of the tower may not contain the entrance, while a less obvious side route may lead to the correct staircase or platform.
Inventory pressure also matters. If you carry too much loot, you may avoid climbing because vertical movement feels risky. For scanner objectives, prioritize the quest first and loot after the objective confirms. The safest run is not always the richest run. It is the run where the quest state updates and you extract cleanly.
What Is the LiDAR Scanner Used For in Arc Raiders?
Quest Progression Use
In Arc Raiders, the LiDAR scanner appears to function primarily as a progression item or objective tool. It may represent equipment that supports scanning, mapping, surveillance, retrieval, reconnaissance, or interaction with a location. The exact quest behavior can depend on the active task, but the practical player takeaway is simple: treat the scanner as mission-critical rather than optional loot.
If the objective asks for a scanner, the goal may involve finding equipment, reaching a tower, performing a scan, extracting with the item, or delivering it later. Always verify whether the quest tracker changes after pickup or interaction. If it does not, you may still need to complete another step.
Tactical Meaning of LiDAR in a Sci-Fi Extraction Shooter
LiDAR fits the Arc Raiders setting because it implies environmental awareness beyond normal vision. In a sci-fi extraction shooter, a LiDAR scanner could be used to map terrain, detect structures, support reconnaissance, identify objects in low-visibility conditions, feed autonomous systems, or assist drones and surveillance networks. Even if the game simplifies the device, the concept communicates technical value immediately.
This is why scanner objectives often feel connected to control towers, industrial rooms, communications equipment, and high-tech locations. The item is not thematically random. It belongs where a world would store mapping, range detection, monitoring, or navigation hardware.
Why the Scanner Is Easy to Miss
The scanner is easy to miss because players naturally prioritize combat value. Weapons, shields, ammunition, healing items, and rare valuables pull the eye quickly. A utilitarian scanner may not look valuable at first glance, especially in a cluttered technical room. Players who search only high-rarity loot routes may walk past the exact kind of industrial or objective-specific area where scanner equipment appears.
To improve your odds, change your search mindset. Look for places where a technician, operator, or surveillance system would use a scanning device. That means consoles, control desks, equipment shelves, tower rooms, technical crates, hangars, and maintenance interiors. If the room looks like someone would maintain sensors, wiring, communications, or monitoring equipment there, it deserves a closer look.
Arc Raiders LiDAR vs Real-World LiDAR Scanners
The In-Game Concept
The Arc Raiders LiDAR scanner is an abstraction of a real sensing tool. In the game, it helps create a believable objective around scanning, mapping, surveillance, or technical recovery. Players do not need to understand optics or signal processing to use it, but the item works because the word “LiDAR” already suggests advanced perception and environmental measurement.
Game designers use that expectation well. A scanner sounds like something you would take into a dangerous environment to understand what is around you. It also sounds like something a faction would want recovered from a tower, control room, or technical site. That is why the objective feels right even when the pickup logic is not obvious.
The Real Engineering Concept
A real LiDAR scanner emits light and measures the returning signal to calculate distance. Depending on the system architecture, it may generate a single distance value, a 2D scan, a structured depth map, or a 3D point cloud. In robotics and UAVs, this distance information helps machines understand where objects are, how far away surfaces are, and whether a path is safe.
For broader industry context, companies such as RoboSense develop LiDAR perception technologies for robotics, vehicles, and intelligent machines. The larger LiDAR ecosystem includes automotive perception, mobile robotics, industrial navigation, mapping, safety monitoring, and embedded sensing.
Key Similarities
The game item and real LiDAR share the same conceptual foundation: environmental perception. Both are associated with mapping, navigation, reconnaissance, and sensing beyond ordinary human vision. Both fit naturally with drones, robots, surveillance systems, and technical missions. Both are useful in environments where direct human inspection is difficult, dangerous, or inefficient.
✅ Both connect to scanning and spatial awareness.
✅ Both make sense around towers, industrial sites, and technical equipment.
✅ Both support the idea of safer decision-making in complex environments.
✅ Both are valuable because they reveal geometry, distance, or structure that normal vision may miss.
Key Differences
The differences are in engineering detail. Game scanners are simplified for objectives and pacing. Real LiDAR requires optical design, timing electronics, calibration, signal processing, software integration, mechanical mounting, power planning, and environmental validation. Real systems are selected by measurable specifications such as range, accuracy, field of view, resolution, frame rate, interface, operating temperature, power consumption, size, and weight.
In other words, the Arc Raiders scanner is a useful narrative object. A real LiDAR sensor is a measurement system. One moves a quest forward. The other has to survive vibration, sunlight, dust, bad mounting decisions, noisy data, cable strain, power limits, software bugs, and whatever else the field throws at it.
How dToF LiDAR Scanners Work
Direct Time-of-Flight Measurement
dToF means direct time-of-flight. A dToF LiDAR sensor emits short pulses of light and measures how long it takes for reflected photons to return from a target surface. Since the speed of light is known, the system calculates distance from the round-trip travel time. The measurement must be extremely precise because light travels very quickly, so the electronics and timing architecture are critical to performance.
Distance = speed of light × round-trip time ÷ 2
The division by two matters because the pulse travels from the sensor to the object and then back to the sensor. The measured time includes the full round trip, while the useful distance is only the one-way distance to the target.
SPAD-Based Sensing
SPAD stands for single-photon avalanche diode. A SPAD detector is highly sensitive and can register very weak returning light signals. This is important for compact solid-state LiDAR because returning light may be limited by distance, target reflectivity, surface angle, ambient light, and optical constraints. In practical terms, SPAD-based dToF sensing helps compact modules detect distance while remaining small enough for robots, drones, embedded devices, and industrial equipment.
Real-world performance still depends on environment and integration. Bright sunlight introduces background noise. Dark or angled surfaces may reflect less light. Shiny surfaces may create unusual reflections. Dust, rain, glass, and vibration can affect measurement reliability. Good system design combines sensor capability with mounting, filtering, calibration, and application-specific validation.
Depth Maps and Point Clouds
A depth map is a structured grid of distance values. Instead of showing color like a normal camera image, each cell represents how far a surface is from the sensor. A 40 × 30 depth frame contains 1,200 measurement points arranged in a grid. That can support zone detection, obstacle awareness, presence detection, and compact perception tasks.
A point cloud converts depth data into spatial points, usually represented as X, Y, and Z coordinates. Point clouds help software reason about 3D geometry, object position, surfaces, and free space. For mobile robots, point cloud data can support obstacle detection, mapping, navigation, and sensor fusion. For UAVs, point clouds or distance frames can support altitude hold, terrain following, and landing assistance.
FOV, Range, and Accuracy
Field of view defines how wide and tall the sensing area is. A 60° horizontal × 45° vertical FOV gives a rectangular sensing zone suitable for localized environmental perception, forward obstacle detection, downward terrain sensing, and area monitoring. Range defines the practical distance over which the module can measure, while accuracy describes how close the reported distance is to the real distance under specified conditions.
For a module with ±3 cm ranging accuracy, the sensor can support many robotics and inspection tasks, but it should not be confused with a high-density survey instrument. Accuracy, resolution, and frame rate must be matched to the mission. At 10 fps, a compact module can update depth information in real time for many slow to moderate robotics applications, but high-speed autonomy may require additional sensing, faster update rates, or sensor fusion.
For complementary positioning and navigation hardware, Beitian is another relevant reference in the broader navigation ecosystem.
Real Product Example: DTOF Solid State LiDAR HM-LD1
The DTOF Solid State LiDAR HM-LD1 is a compact real-world example of the technology behind the LiDAR scanner concept. Instead of acting as a fictional quest object, it provides measurable depth sensing for robotics, UAVs, smart inspection, security monitoring, embedded vision, and autonomous navigation development. It is based on SPAD dToF technology and delivers real-time depth images and 3D point cloud data for environmental perception.
The HM-LD1 is designed for projects where size, weight, power consumption, and interface flexibility matter. Its compact dimensions make it suitable for autonomous mobile robots with limited sensor space and UAVs where weight affects flight time and payload capacity. With UART, UDP, and UVC interfaces, it can integrate with PCs, Raspberry Pi systems, flight controllers, embedded Linux platforms, and robot compute units. SDK support for x86 Windows, x86 Linux, and ARM Linux improves development flexibility.
The module supports indoor or nighttime ranging up to 25 m and outdoor daytime ranging up to 8 m, with the product information noting accurate outdoor measurement at 8 m on a clear summer day under approximately 80,000 lux. That makes it relevant for applications where people should not approach the target directly, such as inspection around bridges, expressways, dams, machinery zones, restricted industrial sites, and security perimeters.
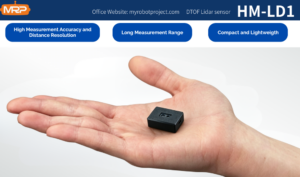
| Specification | DTOF Solid State LiDAR HM-LD1 |
|---|---|
| Dimensions | 43.5 mm × 30 mm × 26.5 mm |
| Ranging Capability | Indoor: 0.5–25 m; Outdoor: 0.2–8 m |
| Ranging Accuracy | ±3 cm |
| Field of View | 60° horizontal × 45° vertical |
| Weight | 28 g |
| Resolution | 40 × 30 |
| Frame Rate | 10 fps |
| Interface | UART / UDP / UVC |
| Operating Temperature | -20 ℃ to 60 ℃ |
| Power Consumption | 1.2 W |
View Product Details & Pricing ➔
Download the product brochure: DTOF SSL HM-LD1 Product Brochure.
Industrial Robotics and UAV Applications
Obstacle Avoidance
Compact LiDAR modules help robots detect walls, shelves, pallets, railings, machinery, people, and other obstacles in the operating area. A module can be mounted forward-facing for navigation, downward-facing for floor or terrain monitoring, or angled to cover a specific safety zone. For embedded robotics and UAV development, the HM-LD1 dToF LiDAR module provides compact depth sensing with UART, UDP, and UVC integration options.
Obstacle avoidance does not require the sensor to understand every object semantically. Often, the robot only needs to know that a surface exists within a defined distance or zone. Depth frames and point cloud data can trigger slow-down behavior, stop commands, path replanning, or alerts to a higher-level autonomy stack.
✅ Robots can slow down before reaching a wall, rack, pallet, or person.
✅ UAVs can use distance data to maintain safer standoff from structures.
✅ Security systems can monitor defined zones without relying only on camera images.
✅ Inspection platforms can keep a controlled distance from bridges, dams, or machinery.
SLAM and Autonomous Navigation
LiDAR data can support simultaneous localization and mapping by giving a robot spatial information about nearby surfaces. For lower-resolution depth modules, the sensor may be used as part of a fusion system rather than as the only mapping source. Cameras, IMUs, wheel odometry, GNSS, UWB, and other positioning modules can all contribute to a more robust navigation system.
In an indoor AMR, LiDAR can help detect obstacles and environmental structure. In a service robot, it can support local perception around people and furniture. In an industrial robot, it can help maintain awareness around machinery, aisles, or inspection paths. The best architecture depends on speed, environment complexity, safety requirements, and processing resources.
UAV Altitude Hold and Terrain Following
Drones can use compact LiDAR for altitude hold, terrain following, landing assistance, and low-altitude obstacle awareness. A lightweight 28 g module is valuable because every gram affects flight time, payload budget, and aircraft stability. Power consumption also matters, especially on battery-powered UAVs where sensors compete with propulsion, compute, communication, and payload systems.
A downward-facing LiDAR can measure distance to the ground or target surface more directly than a monocular camera. Terrain following applications benefit from regular distance updates, especially when flying over uneven surfaces. For UAV inspection, a compact depth sensor can help maintain safer standoff distances from structures.
Smart Inspection and Industrial Measurement
Industrial inspection often requires sensing in places that are inconvenient or unsafe for people to approach. Bridges, expressways, dams, warehouses, tunnels, restricted zones, and security perimeters can all benefit from compact distance sensing. The HM-LD1 product details note outdoor measurement capability up to 8 m in clear summer daylight conditions around 80,000 lux, making outdoor validation an important part of deployment planning.
For inspection robots, depth data can help maintain distance from surfaces, identify obstacles, assist positioning, and support data collection. For stationary monitoring systems, LiDAR can detect whether an object or person enters a defined zone. For mobile platforms, LiDAR can provide geometric context that complements cameras and other sensors.
Presence Detection, Autofocus, Volume Measurement, and Intrusion Monitoring
Beyond navigation, dToF LiDAR can support user presence detection, object recognition assistance, autofocus support, zone intrusion monitoring, package or bin volume measurement, and safety boundary detection. These applications depend on how the sensor data is processed. A depth frame can identify whether something is present in a zone, while point cloud data can help estimate shape, position, or volume.
In security systems, LiDAR can help distinguish movement in a defined area without relying only on appearance. In cameras, distance sensing can improve focus decisions. In logistics, depth information can assist package sizing or bin fill estimation. The same physical principle that makes the Arc Raiders scanner feel useful in a sci-fi world is used in real systems to give machines measurable spatial awareness.
How to Choose a LiDAR Scanner for Robotics Projects
Range Requirements
Start with the mission. Indoor AMRs often need short to medium range obstacle detection. UAV altitude hold needs stable downward ranging. Outdoor inspection needs sunlight tolerance and validation on real target surfaces. Security monitoring needs reliable field coverage in the intended detection zone. A sensor’s headline range is useful, but the practical range depends on target reflectivity, ambient light, mounting angle, and software filtering.
Look at the environment before you fall in love with a spec sheet. A clean indoor wall, a dark rubber tire, a shiny metal panel, wet concrete, glass, dust, sunlight, and angled surfaces can all produce different behavior. The right scanner is the one that holds up under the actual conditions, not only under ideal lab conditions.
Accuracy and Resolution
Accuracy defines how close the reported distance is to the true distance. Resolution defines how much spatial detail the sensor provides. A ±3 cm accuracy specification may be suitable for obstacle avoidance, presence detection, distance measurement, and localized navigation, but it is not the same as metrology-grade scanning. A 40 × 30 resolution depth module provides compact depth imaging, not dense survey mapping.
Choosing the wrong resolution can lead to disappointment. If you need dense 3D reconstruction, a low-resolution module may not be the right primary sensor. If you need compact local awareness, however, lower-resolution depth data can be efficient, lightweight, and easier to process.
Field of View
Field of view determines how much area the sensor sees. A 60° × 45° FOV can cover a useful rectangular zone for front-facing obstacle awareness, downward terrain sensing, or localized area monitoring. The right FOV depends on mounting height, target size, detection distance, and whether the application needs narrow long-range sensing or wide short-range coverage.
In the shop, mounting geometry is where many sensor projects get into trouble. A sensor with a decent FOV can still perform poorly if brackets, covers, wires, payloads, or machine frames sit in the sensing path. Before final installation, check the actual field clearance and verify that the data matches what the robot or UAV needs to do.
Interface and Platform Support
Interface choice affects integration complexity. UART is useful for embedded controllers and simple data communication. UDP supports network-style data streaming to higher-level compute platforms. UVC can allow camera-like integration with compatible PCs and embedded systems. SDK support for x86 Windows, x86 Linux, and ARM Linux is valuable because it covers many common robotics development environments.
⚙️ Use UART when the system needs compact embedded communication.
⚙️ Use UDP when the host can receive streamed sensor data over a network-style connection.
⚙️ Use UVC when camera-like integration is useful for compatible systems.
⚙️ Confirm SDK and driver support before committing to the mechanical design.
Size, Weight, and Power
Physical constraints matter as much as signal performance. The HM-LD1’s 43.5 mm × 30 mm × 26.5 mm size, 28 g weight, and 1.2 W power consumption make it suitable for compact robots, UAVs, embedded devices, and battery-powered systems. A sensor that is too large, heavy, hot, or power-hungry may fail the project even if its measurement performance is strong.
For UAVs, weight affects flight time and stability. For mobile robots, power draw affects battery life and thermal planning. For embedded equipment, cable routing and enclosure space can decide whether the design is practical. Good sensor selection is never only about range. It is about the complete system.
Integration Notes for Developers
Platform Planning
Before selecting a LiDAR scanner, define the host platform. A Windows PC, Linux industrial computer, Raspberry Pi-class board, ARM Linux module, microcontroller, flight controller, or robot compute unit will each impose different limits on processing, interface compatibility, driver support, power delivery, and cable routing. Choosing the host first makes the sensor integration path clearer.
Developers should also plan how the LiDAR data will move through the system. A low-level controller may only need thresholded distance values. A robot navigation stack may need depth frames or point clouds. A visualization system may need camera-like output. A safety monitor may need clean zone events. Different outputs lead to different software, compute, and interface decisions.
Data Output Planning
Developers should decide whether the application needs raw distance frames, depth maps, point cloud data, object distance thresholds, zone detection, visualization output, or sensor fusion input. A simple obstacle alert may only need thresholded distance data. A navigation stack may prefer point clouds. A visualization tool may need depth images. The same LiDAR module can serve different roles depending on software design.
⚙️ Define the required data format before writing application logic.
⚙️ Decide whether the system needs real-time reaction, logging, visualization, or mapping.
⚙️ Confirm frame rate needs against robot speed and stopping distance.
⚙️ Plan filtering before field testing, not after the first bad dataset.
Mechanical Mounting
Mounting affects performance. Consider sensor angle, vibration, enclosure window material, dust exposure, water exposure, cable strain, field-of-view clearance, and thermal environment. Avoid placing structural parts, wires, covers, or protective windows inside the sensing field unless they are designed for optical compatibility. In UAVs, also account for propeller vibration and airflow. In robots, protect the sensor from impacts and contamination.
Mounting also affects maintenance. A sensor buried deep inside a frame may be hard to clean, inspect, or replace. A sensor mounted too low may get hit. A sensor mounted too high may miss the objects that matter. The best position is the one that gives the software useful data while still surviving the work environment.
Software Filtering
Real-world LiDAR systems often require filtering for outliers, multipath reflections, sunlight interference, reflective surfaces, dark objects, transparent materials, and moving obstacles. Software should not blindly trust every frame. Robust applications compare data over time, reject impossible measurements, smooth noisy readings, and validate sensor behavior against the actual operating environment.
Good filtering does not mean hiding every strange reading. It means understanding which readings are physically plausible and which ones should trigger caution. In industrial robotics, bad assumptions can lead to poor navigation, false stops, missed obstacles, or unstable behavior. Treat the LiDAR as a sensor that needs engineering discipline, not a magic eye.
Common Mistakes: In-Game and Real-World LiDAR
Arc Raiders Mistakes
In Arc Raiders, common mistakes include searching only ground floors, ignoring vertical access, confusing stash items with active quest items, leaving before the quest state updates, and following general loot routes instead of objective-relevant technical areas. Players also lose time by treating Dam Battlegrounds and Spaceport as broad map names instead of searching specific control rooms, tower interiors, industrial spaces, hangars, maintenance corridors, and elevated platforms.
The best correction is to slow down and read the objective precisely. If the task mentions scanning, towers, surveillance, or sky-related wording, search upward and technical. If the item appears in inventory or stash, confirm whether the next step is extraction, delivery, interaction, or deployment.
✅ Search technical rooms before random loot containers.
✅ Check upper floors, rooftops, ladders, stairwells, and control areas.
✅ Watch the quest tracker after pickup or interaction.
✅ Extract safely once the scanner objective is active or complete.
Real LiDAR Mistakes
In real engineering, common mistakes include choosing range without considering sunlight, ignoring FOV and mounting geometry, expecting low-resolution depth sensors to behave like dense survey scanners, forgetting power and interface limitations, ignoring operating temperature, and failing to validate performance on real target materials. A LiDAR scanner should be selected for the actual mission environment, not just the most attractive specification.
Outdoor applications especially require testing. Sunlight, reflectivity, distance, dust, weather, target angle, and enclosure design can change results. Good integration treats the sensor as part of a full perception system that includes mechanical design, software filtering, power planning, and platform compatibility.
Look, the scanner is only one part of the job. Whether you are trying to finish a quest in Arc Raiders or make a robot behave safely around equipment, the same discipline helps: understand the objective, inspect the environment, verify the data, and do not assume the first apparent answer is the correct one.
We’ve recently been testing the HM-LD1 compact dToF LiDAR in a variety of r…
FAQ: LiDAR Scanner Arc Raiders and Real-World LiDAR
Where can I find a LiDAR scanner in Arc Raiders?
How do I reach the top of the control tower for the LiDAR scanner quest?
What is a LiDAR scanner used for in Arc Raiders and in real robotics?
Is the LiDAR scanner random loot or a fixed quest item in Arc Raiders?
Should I search Dam Battlegrounds or Spaceport first for a LiDAR scanner?
How far can a real compact LiDAR scanner measure outdoors?
What is the difference between a depth map and a point cloud?
Why use LiDAR instead of only a camera?
What platforms can the HM-LD1 LiDAR module support?
How do I choose the right LiDAR scanner for a robot or UAV?
📚 References & Further Reading
- Industry Standard: RoboSense | Beitian
- Related Guide: DTOF Solid State LiDAR HM-LD1






