


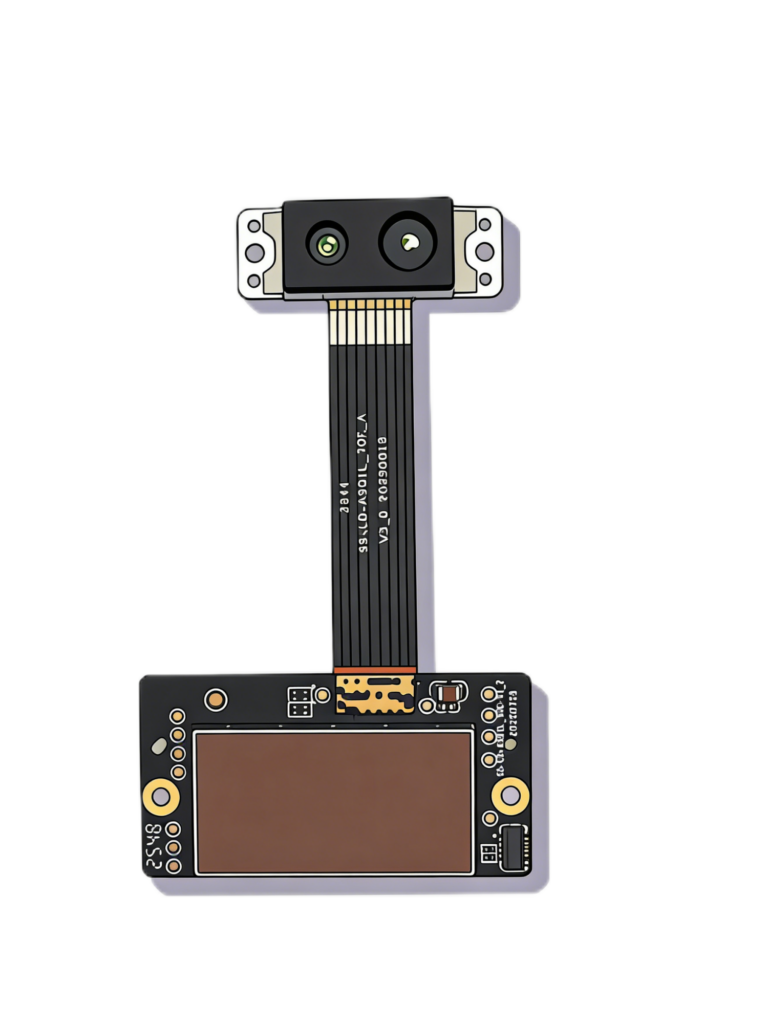
hm_ld1_opencv_demo is an OpenCV demo for visualizing HM-LD1 depth frames and point clouds. It builds two applications:
hm_ld1_depth_viewerhm_ld1_pointcloud_viewer
Supported transports:
serialudpuvc
Applications
hm_ld1_depth_viewer: renders colorized depth images, supports snapshots, zoom, pan, and headless modehm_ld1_pointcloud_viewer: renders interactive point clouds, supports rotate, pivot, zoom, and headless mode
Features
- Uses the SDK
FrameSetAPI across all transports - Renders depth images with auto range or fixed display range
- Renders point clouds with interactive camera controls
- Supports snapshots and no-window execution for quick capture or scripting
- Prints device information and frame summaries for debugging
Quick Start
Recommended layout:
tof_test/
|-- Dtof-SSL-HM-LD1-sdk/
`-- hm_ld1_opencv_demo/
git clone https://github.com/myrobotproject/Dtof-SSL-HM-LD1-sdk
cmake -S hm_ld1_opencv_demo -B hm_ld1_opencv_demo/build -DCMAKE_BUILD_TYPE=Release
cmake --build hm_ld1_opencv_demo/build -j
./hm_ld1_opencv_demo/build/hm_ld1_depth_viewer --transport uvc --uvc-device /dev/video0For a one-frame headless capture:
./hm_ld1_opencv_demo/build/hm_ld1_depth_viewer \
  --transport uvc \
  --uvc-device /dev/video0 \
  --headless \
  --max-frames 1 \
  --snapshot-path depth.png
Repository Layout
hm_ld1_opencv_demo/
|-- include/
|   |-- cli/
|   |-- core/
|   |-- hm_ld1_sdk/        Used when storing SDK headers in-repo
|   |-- render/
|   `-- viewer/
|-- lib/                   Used when storing SDK libraries in-repo
|-- src/
|   |-- apps/
|   |-- cli/
|   |-- core/
|   |-- render/
|   `-- viewer/
|-- CMakeLists.txt
|-- README.md
`-- README_CN.md
Requirements
- CMake
>= 3.16 - A C++17 compiler
- OpenCV with
core,imgproc,highgui, andimgcodecs - HM-LD1 SDK:
https://github.com/myrobotproject/Dtof-SSL-HM-LD1-sdk
SDK Setup
This repository does not include SDK headers or shared libraries. Prepare the SDK in one of the following ways before building.
1. Recommended: clone the SDK next to this repository
CMakeLists.txt automatically detects the sibling SDK repository and builds it with add_subdirectory().
2. Pass HM_LD1_SDK_ROOT
cmake -S . -B build -DHM_LD1_SDK_ROOT=/path/to/Dtof-SSL-HM-LD1-sdk
cmake --build build -j
HM_LD1_SDK_ROOT may point to:
- the SDK source repository
- an installed SDK prefix
- a prebuilt SDK directory containing
include/andlib/
3. Use an installed SDK package
If the SDK was installed with cmake --install, this demo can load it through find_package(hm_ld1_sdk) using CMAKE_PREFIX_PATH or the system default package search path.
4. Store the SDK inside this repository
hm_ld1_opencv_demo/
|-- include/hm_ld1_sdk/hm_ld1_sdk.hpp
`-- lib/libhm_ld1_sdk.so
Use this layout if you want the demo and SDK files in the same directory tree.
Build
cmake -S . -B build -DCMAKE_BUILD_TYPE=Release
cmake --build build -j
Generated binaries:
build/hm_ld1_depth_viewerbuild/hm_ld1_pointcloud_viewer
Usage Examples
Serial depth viewer
./build/hm_ld1_depth_viewer --transport serial --port /dev/ttyUSB0UDP depth viewer
./build/hm_ld1_depth_viewer --transport udp --udp-bind 0.0.0.0 --udp-port 2368UVC depth viewer
./build/hm_ld1_depth_viewer --transport uvc --uvc-device /dev/video0UVC point-cloud viewer
./build/hm_ld1_pointcloud_viewer --transport uvc --uvc-device /dev/video0Headless snapshot
./build/hm_ld1_depth_viewer \
  --transport serial \
  --port /dev/ttyUSB0 \
  --headless \
  --max-frames 1 \
  --snapshot-path depth.png
Common CLI Options
Transport options
--transport <serial|udp|uvc>--port <name>--baud <value>--udp-bind <address>--udp-port <value>--udp-interface <name>--udp-auto-config--udp-auto-timeout-ms <ms>--uvc-device <path>--uvc-stream-width <px>--uvc-stream-height <px>--uvc-bootstrap-timeout-ms <ms>
Common viewer options
--width <value>--height <value>--rotate <0|180>--depth-min <value>--depth-max <value>--auto-range--crc-mode <auto|none|crc8|crc8_itu|maxim|rohc>--snapshot-path <path>--headless--max-frames <count>--idle-timeout-ms <ms>
Point-cloud options
--pc-width <value>--pc-height <value>--pc-point-size <value>--pc-yaw <deg>--pc-pitch <deg>--pc-zoom <value>
Controls
Depth viewer
- Mouse wheel or
+/-: zoom - Left drag: pan
Ror0: reset viewQorEsc: quit
Point-cloud viewer
- Left drag: rotate
- Right drag: move the pivot on the XZ plane
- Mouse wheel or
+/-: move the camera W/S: pitchA/D: yawRor0: resetQorEsc: quit
Verified Environment
The current version has been verified with:
- Debian Linux on
aarch64 - GCC
14.2.0 - OpenCV
4.10.0 - HM-LD1 UVC device on
/dev/video0
Troubleshooting
Could not find hm_ld1_sdk: clone the SDK next to this repository, setHM_LD1_SDK_ROOT, or install the SDK package firstFailed to open UVC device: check the device path, permissions, and whether the sensor appears under/dev/video*- OpenCV not found during CMake configure: install the OpenCV development package and make sure CMake can find it
- No frame arrives in headless mode: verify the transport settings, device connection, and timeout values
License
This repository is released under the MIT License. See LICENSE.
Official Website:https://myrobotproject.com/product/dtof-solid-state-lidar-hm-ld1/
GitHub Repository:https://github.com/myrobotproject/HM-LD1-OpenCV-Demo








