


3D Drone LiDAR for UAV Mapping: How to Choose the Right Sensor, SDK, and Integration Path
Choosing the right 3d drone lidar is not just a spec-sheet contest anymore. Here’s the deal: maximum range and point cloud density matter, but they are only part of the job. For UAV mapping, inspection, obstacle avoidance, terrain following, and autonomous navigation, the sensor has to fit the aircraft, the mission, and the software stack. That means payload limits, flight time, processing hardware, field of view, outdoor lighting, SDK quality, interface options, and the actual integration path all matter.
Look, a high-end mapping LiDAR payload can generate beautiful georeferenced point clouds. But if it is too heavy, too power-hungry, or too complicated for a compact autonomous drone, it is the wrong tool for that platform. On the other hand, a lightweight solid-state depth LiDAR may not replace a full survey payload, but it can be exactly what you want for real-time obstacle avoidance, embedded robotic perception, low-altitude inspection, altitude hold, and short-range 3D sensing.
This guide breaks down how 3d drone lidar works, how UAV LiDAR differs from 2D scanners and camera-based depth systems, which specifications actually matter in the field, and how to choose between mapping-grade LiDAR payloads, solid-state dToF modules, and embedded depth sensors. It also covers SDK, ROS, Embedded Linux, Raspberry Pi, Jetson, and flight controller integration paths.
We will also look at where the DTOF Solid State LiDAR HM-LD1 fits. In the shop, I would describe it as a compact SPAD dToF depth LiDAR module suited for UAV altitude hold, near-field obstacle detection, robotic vision, short-range inspection assistance, and development-stage 3D perception. It is not a complete survey-grade mapping payload, and that distinction matters.
Table of Contents
- 👉 What Is 3D Drone LiDAR?
- 👉 How 3D Drone LiDAR Works
- 👉 3D Drone LiDAR vs 2D LiDAR vs Depth Cameras
- 👉 Key Specifications That Matter for UAV LiDAR
- 👉 Mapping, Navigation, and Obstacle Avoidance Use Cases
- 👉 How to Choose the Right 3D Drone LiDAR Sensor
- 👉 SDK, ROS, Embedded Linux, and Flight Controller Integration
- 👉 RTK, GNSS, INS, and Georeferenced UAV Mapping
- 👉 Recommended Compact dToF LiDAR Module: HM-LD1
- 👉 Recommended Integration Workflows for 3D Drone LiDAR
- 👉 Common Mistakes When Buying 3D Drone LiDAR
- 👉 FAQ: 3D Drone LiDAR
- 👉 Choosing the Right 3D Drone LiDAR Starts with the Integration Path
What Is 3D Drone LiDAR?
3D drone LiDAR is a LiDAR-based perception or mapping system mounted on a UAV to generate distance measurements, depth maps, or 3D point clouds. In plain engineering terms, it gives the drone spatial awareness. Instead of only recording visual images, a LiDAR sensor actively measures distance to surfaces such as terrain, walls, trees, bridge structures, shelves, industrial equipment, vehicles, or people. That output may be used for real-time control, autonomous navigation, industrial inspection, or post-processed mapping.
The phrase “3D drone LiDAR” usually covers two major categories. The first is a mapping-grade UAV LiDAR payload. This setup typically combines a laser scanner, GNSS receiver, RTK or PPK correction workflow, INS/IMU, time synchronization, onboard storage, calibration data, and post-processing software. These systems are used for drone LiDAR mapping, corridor mapping, terrain modeling, forestry measurement, mine stockpile measurement, road surveys, and other georeferenced point cloud applications.
The second category is an embedded 3D depth LiDAR module. This type of sensor outputs real-time depth frames or local point cloud data for nearby perception. It may not include GNSS, RTK, INS, or survey software, but it can be extremely useful for UAV altitude hold, terrain following, obstacle avoidance, docking, indoor navigation, robot SLAM development, and inspection standoff measurement. A compact dToF LiDAR module is often easier to integrate into small drones because it can be lighter, lower power, and more software-accessible than a full mapping payload.
Common applications include aerial topographic mapping, bridge inspection, dam inspection, expressway inspection, warehouse automation, tunnel inspection, powerline proximity detection, indoor autonomous flight, MAV research, object recognition, volume measurement, and zone intrusion monitoring. For mapping applications that require centimeter-level positioning, see our guide on what RTK means in centimeter-level GPS navigation.
Here is the practical difference: mapping LiDAR is usually about producing a trusted record of the world, while embedded depth LiDAR is usually about helping the machine make a decision right now. A surveyor cares whether the final point cloud lines up correctly with real-world coordinates. A drone autonomy engineer cares whether the aircraft sees the wall, shelf, beam, or ground surface quickly enough to avoid it.
How 3D Drone LiDAR Works
Time-of-Flight Measurement
LiDAR measures distance by emitting light and detecting the reflected signal returned from a target. In direct time-of-flight, or dToF, the system measures how long it takes for emitted light to travel to the object and return to the receiver. Because the speed of light is known, that time delay can be converted into distance.
Distance = (Speed of Light × Time Delay) / 2
The division by two is required because the light travels both directions: from the LiDAR transmitter to the target, then from the target back to the receiver. In a drone application, the measured distance can be converted into local spatial data. With the right optics, calibration, and processing, this becomes a depth map or point cloud that software can use to estimate obstacles, surfaces, altitude, or terrain profile.
dToF, SPAD, and Solid-State LiDAR
Many compact depth LiDAR modules use sensitive photodetectors to detect reflected photons. SPAD, or single-photon avalanche diode, technology is often used in dToF systems because it can detect extremely weak return signals. That matters when the sensor is compact, power-limited, and operating in changing real-world environments.
Solid-state LiDAR designs reduce or eliminate mechanical scanning mechanisms. For UAVs, this can make integration easier because mechanical simplicity often supports compact size, lower weight, improved resistance to vibration, and cleaner mounting. The DTOF Solid State LiDAR HM-LD1 is based on SPAD dToF technology and outputs real-time depth images and 3D point cloud data for environmental perception.
Point Cloud and Depth Map Output
A depth map is a two-dimensional grid where each pixel contains distance information. It is convenient for embedded perception because it behaves a lot like camera data and can be processed using image-style algorithms. A point cloud is a 3D representation where each point has spatial coordinates, often expressed as X, Y, and Z values relative to the sensor. For autonomous drones, a depth map may be converted into obstacle zones, while a point cloud may be used for SLAM, mapping, terrain estimation, or 3D visualization.
Why UAVs Need Real-Time Depth Data
Drones operate under strict timing constraints. If a UAV is moving through a warehouse aisle, along a bridge surface, or close to uneven terrain, late perception data can be almost as bad as no perception data. A drone obstacle avoidance LiDAR must deliver measurements quickly enough for the companion computer or flight controller to respond. Real-time depth data supports emergency braking, altitude corrections, terrain following, safe standoff distance, wall following, and low-speed autonomous inspection.
In the shop, this is where a lot of projects succeed or fail. A sensor that looks good on a bench may still be hard to use on a flying platform if the latency is high, the driver is unstable, or the output format is awkward. Flight control does not wait politely for your software stack to catch up.
3D Drone LiDAR vs 2D LiDAR vs Depth Cameras
2D LiDAR on Drones
2D LiDAR scans a single plane. It can be useful for simple altitude detection, wall distance measurement, or basic obstacle detection. However, 2D LiDAR does not directly capture a full 3D scene in one frame. To generate 3D data, the drone must move through space while software records sensor scans, UAV pose, timestamps, and motion data. This approach can work in controlled research projects, but it increases the burden on synchronization, calibration, and motion compensation.
True 3D LiDAR
True 3D LiDAR captures spatial depth across multiple horizontal and vertical angles. It can output local point clouds more directly than a 2D scanner when the goal is 3D obstacle awareness or dense mapping. Mapping-grade 3D LiDAR payloads are often used when the operator needs georeferenced output. Embedded 3D depth LiDAR modules are often used when the UAV needs local perception rather than survey-grade mapping.
Structured Light, Stereo Vision, and ToF Cameras
Camera-based depth systems can be excellent for short-range indoor perception, object recognition, and visual navigation. Stereo cameras estimate depth using image disparity. Structured light systems project a known pattern and calculate depth from deformation. ToF cameras estimate distance using light timing or phase. These technologies can be useful, but they may be affected by sunlight, low texture, reflective surfaces, glass, dark materials, or motion blur. For more background on structured light depth sensing, see our article on what phase means in 3D structured light cameras.
The best choice is not always the most expensive sensor. It is the sensor that solves the actual failure mode you are worried about. If your drone keeps drifting into racks in a warehouse, you need reliable near-field depth. If your survey model needs accurate ground classification through vegetation, you need a mapping-grade system. If your robot needs to recognize objects and read visual labels, you may need cameras alongside LiDAR.
| Technology | Best For | Limitations | Typical UAV Use |
|---|---|---|---|
| 2D LiDAR | Single-plane scanning, altitude, wall distance | Needs motion compensation for 3D mapping | Basic navigation, simple obstacle detection |
| 3D LiDAR | Point clouds, mapping, obstacle perception | Can be heavier or more expensive | UAV mapping, inspection, autonomous navigation |
| dToF Depth LiDAR | Compact real-time depth sensing | Range and resolution depend on module design | Obstacle avoidance, terrain following, robotics development |
| Stereo / Structured Light | Short-range depth, visual perception | Lighting and texture sensitivity | Indoor navigation, object detection, prototyping |
Key Specifications That Matter for UAV LiDAR
Range
Range is one of the first specifications buyers compare, but it has to be read carefully. Indoor range and outdoor range are often different because sunlight, target reflectivity, atmospheric conditions, optical filtering, and sensor architecture affect the signal-to-noise ratio. A compact sensor may perform very well indoors or at night but have a shorter rated range under bright outdoor conditions.
The HM-LD1 supports indoor ranging from 0.5 m to 25 m and outdoor ranging from 0.2 m to 8 m. That makes it suitable for near-field UAV perception, altitude tasks, and inspection standoff measurement rather than long-range survey scanning. That is not a weakness if the mission is local perception. It simply means you should not confuse short-range depth sensing with high-altitude mapping.
Accuracy
Accuracy can mean different things depending on the job. Ranging accuracy describes how accurately the sensor measures distance to a target. Mapping accuracy describes how accurately the final point cloud aligns with real-world coordinates. Mapping accuracy also depends on GNSS, RTK, INS, IMU quality, calibration, synchronization, and post-processing.
The HM-LD1 has a ranging accuracy of ±3 cm, which is useful for local depth sensing, obstacle detection, and robotic vision development. For UAV control, that level of local measurement can be very helpful. For survey-grade mapping, though, you still need the positioning and timing stack to turn local measurements into trusted world-referenced data.
Field of View
Field of view determines how much of the environment the sensor can observe at once. A wider field of view is useful for obstacle avoidance and situational awareness, while a narrower field may be suitable for focused range measurement. For front-facing UAV obstacle detection, horizontal and vertical coverage both matter. For downward-facing terrain following, the vertical field and mounting angle influence how terrain changes are detected.
The HM-LD1 offers a 60° horizontal by 45° vertical field of view. For a compact near-field perception module, that gives developers useful coverage without turning the device into a large scanning payload. Mounting angle still matters. A forward-facing sensor, downward-facing sensor, and angled inspection sensor will produce very different data even with the same FOV.
Resolution and Frame Rate
Resolution defines how many depth samples are available in each frame. Higher resolution can improve object shape understanding, but it also increases processing load. Frame rate affects reaction time. For small drones, latency and stable frame delivery are often more important than maximum point count.
The HM-LD1 provides 40 × 30 resolution at 10 fps. That gives developers a compact depth data stream suitable for near-field perception algorithms and embedded experiments. Look at this from a practical angle: if you are flying slowly near structures, trying to maintain standoff distance, or building a prototype obstacle detection layer, clean and predictable data can be more valuable than a massive data stream your companion computer struggles to process.
Weight and Power Consumption
Every gram matters on a UAV platform. Sensor weight affects flight time, battery size, frame selection, gimbal design, vibration behavior, and control margin. Power consumption also matters because drones are battery-operated systems with strict energy budgets.
The HM-LD1 weighs 28 g and consumes 1.2 W, making it attractive for compact UAVs, MAVs, mobile robots, and embedded perception platforms where payload margin is limited. In small aircraft, saving weight is not just about endurance. It can also improve handling, reduce vibration problems, and leave room for other sensors or protective housings.
Interface and SDK Availability
A sensor’s interface often determines how quickly it can be integrated. UART is useful for embedded control and low-bandwidth distance data. UDP supports network-based streaming to embedded Linux systems. UVC can make the device behave more like a camera-style depth stream, which is convenient for PC, Raspberry Pi, and Linux development.
The HM-LD1 supports UART, UDP, and UVC, and MRP offers SDKs for x86 Windows, x86 Linux, and ARM Linux. ARM Linux support is especially valuable because many UAV companion computers use Raspberry Pi, Jetson, or other embedded Linux platforms. From an engineering standpoint, this matters because the sensor is only as useful as the data path you can actually build, test, and maintain.
Mapping, Navigation, and Obstacle Avoidance Use Cases
UAV Mapping
Drone LiDAR mapping is used to generate 3D point clouds of terrain, vegetation, buildings, roads, power corridors, stockpiles, and industrial sites. A complete mapping payload usually includes a LiDAR scanner, GNSS receiver, RTK or PPK correction method, INS/IMU, time synchronization, calibration, onboard data logging, and processing software.
LiDAR alone measures distances relative to the drone. To create accurate world-referenced maps, the system must know exactly where the drone was and how it was oriented when each measurement was taken. That is why a mapping payload is more than a laser scanner. It is a synchronized measurement system.
Industrial Inspection
Drones reduce risk when measuring or inspecting bridges, dams, expressways, warehouses, tunnels, and other infrastructure that can be difficult or dangerous for people to approach. A compact 3D drone LiDAR module can help maintain safe distance from surfaces, detect protrusions, estimate structure proximity, or support semi-autonomous inspection paths.
The HM-LD1 product information highlights outdoor measurement capability from up to 8 meters on a clear summer day assuming 80,000 lux, making it useful for distance detection in demanding outdoor inspection conditions within its rated range. For bridge, dam, or expressway work, that can help an operator or autonomous stack maintain a safer distance from surfaces, as long as the mission remains inside the sensor’s environmental and range limits.
Obstacle Avoidance
For obstacle avoidance, the perception system must detect objects early enough for the drone to react. Software may divide the field of view into warning zones, stopping zones, and clear zones. The LiDAR output can trigger speed reduction, braking, climbing, descending, or path adjustment.
A compact dToF LiDAR is especially useful for near-field detection because it provides active distance measurements that do not depend entirely on texture or visual contrast. That is a big deal around blank walls, low-texture floors, shelves, boxes, machinery, and structural surfaces where vision-only approaches may struggle.
Altitude Hold and Terrain Following
Downward-facing LiDAR can improve altitude estimation when barometers drift or visual sensors struggle. Terrain following requires more than a single range value if the ground is sloped or uneven. A depth image or local point cloud can help estimate surface shape beneath or ahead of the drone.
For low-altitude inspection, agriculture, indoor flight, or research UAVs, this can support smoother altitude control and safer movement near surfaces. The key is to validate the control loop carefully. You do not want noisy measurements, vibration artifacts, or prop wash contamination driving unstable altitude behavior.
Indoor Autonomous Drones and MAVs
Indoor drones usually cannot rely on GNSS. They may combine LiDAR, optical flow, visual-inertial odometry, UWB, IMU data, and SLAM algorithms. A compact depth LiDAR can help detect walls, shelves, beams, people, boxes, machinery, and doorways.
For MAVs, sensor weight and power consumption become critical. A 28 g LiDAR module with ARM Linux SDK support can significantly reduce the integration burden compared with heavier perception payloads. In a small indoor drone, payload margin is often the difference between a stable test platform and a machine that spends most of its time on the repair bench.
How to Choose the Right 3D Drone LiDAR Sensor
Step 1: Define the Mission
Start with the mission, not the specification sheet. Survey mapping, real-time obstacle avoidance, indoor SLAM, altitude hold, terrain following, inspection, and research prototyping all require different sensor tradeoffs. A mapping company may need long range, high point density, GNSS/RTK/INS integration, and post-processing. A drone developer building obstacle avoidance may prioritize low latency, wide FOV, embedded Linux support, low weight, and power efficiency.
Before buying hardware, write down the operating distance, lighting conditions, drone speed, payload budget, required update rate, required output format, and target computing platform. That simple exercise prevents a lot of expensive mistakes.
Step 2: Determine Required Range
A 100 m mapping range may be unnecessary for indoor obstacle avoidance. Conversely, an 8 m outdoor range may be practical for near-field inspection, safe standoff measurement, and collision prevention, but not sufficient for high-altitude topographic mapping. Required range depends on drone speed, stopping distance, mission altitude, lighting conditions, and target reflectivity. Always validate indoor and outdoor ratings separately.
Look at range as a safety and data-quality requirement, not just a marketing number. A slow inspection drone working within a few meters of a wall does not need the same LiDAR as a corridor mapping UAV flying high over a road or utility line.
Step 3: Calculate Payload Budget
Payload budget includes more than the sensor. Add mounting brackets, cables, vibration isolation, protective housing, companion computer, connectors, heat management, and battery impact. A lightweight sensor may allow a smaller drone platform, longer flight time, or additional sensors.
For compact UAVs, reducing payload mass often improves controllability and endurance more than buyers initially expect. Do the weight math early. Then add a margin, because real builds always collect extra hardware as they move from bench prototype to field-ready platform.
Step 4: Match FOV to Mounting Position
A front-facing LiDAR is useful for forward obstacle detection and inspection standoff. A downward-facing LiDAR supports altitude hold and terrain following. Side-facing sensors may help wall following or infrastructure scanning. Some UAVs use multiple sensors to cover blind spots.
The field of view must match both the mission and the mounting geometry. Sensor placement should avoid propeller interference, landing gear obstruction, vibration sources, and cable strain. In the shop, it is worth checking the sensor’s actual view with the drone fully assembled, not just holding the module in your hand on the bench.
Step 5: Evaluate SDK and Data Output
An excellent sensor can become difficult to use if it lacks documentation, Linux drivers, ARM support, example code, or clear data formats. For robotics engineers, SDK quality can determine whether integration takes days or months.
Check whether the sensor provides depth maps, point clouds, distance values, timestamps, calibration data, and platform libraries. Also confirm whether it can work with your selected processing platform, such as Raspberry Pi, Jetson, x86 Linux, Windows, or a microcontroller. If you plan to use ROS or a custom flight-control pipeline, confirm the data path before committing to hardware.
Step 6: Test in Real Lighting Conditions
Real environments include sunlight, glass, dark materials, reflective metal, water, dust, fog, vibration, and moving targets. Test on the surfaces that matter for your mission. A warehouse drone should be tested near shelves, boxes, plastic wrap, forklifts, and people. An inspection drone should be tested near concrete, steel, asphalt, cables, and structural surfaces.
For broader industrial LiDAR context, established sensor manufacturers such as SICK and HOKUYO provide useful reference points for scanning LiDAR applications. The important point is not to copy another application blindly. Use references, then run your own validation on the aircraft and in the environment where the drone will actually work.
SDK, ROS, Embedded Linux, and Flight Controller Integration
Typical UAV LiDAR Integration Architecture
A typical UAV LiDAR architecture starts with the LiDAR capturing depth or point cloud data. The sensor sends data through UART, UDP, UVC, USB, or Ethernet depending on the hardware design. A companion computer receives and processes the data. Perception software detects obstacles, estimates terrain, filters noise, and calculates safe zones. The flight controller then receives high-level commands, distance measurements, or avoidance triggers. Finally, the drone adjusts path, altitude, speed, or failsafe behavior.
Here’s the deal: the integration architecture matters as much as the sensor. A good sensor connected through the wrong interface, processed on an overloaded computer, or passed to the flight controller with poor filtering can create unreliable behavior. Start with a clean data path, then build complexity only after the basic measurement loop is stable.
UART Integration
UART is useful when the system needs simple data exchange with a microcontroller or flight controller. It is often selected for basic distance output, proximity triggers, altitude hold inputs, or low-bandwidth embedded communication. For production UAVs, UART can be reliable and straightforward if the protocol is well documented and electrical integration is handled carefully.
UART is usually not the best path for streaming large point clouds, but it can be excellent for a simple distance sensor role. If the goal is to send a filtered distance value or zone warning into a flight controller, UART may be the cleanest solution.
UDP Integration
UDP is useful for network-based data streaming to embedded Linux systems or robot platforms. It works well when a companion computer needs to receive frames from the LiDAR while other processes handle visualization, logging, ROS conversion, or navigation. UDP integration requires attention to packet handling, timestamps, buffering, and network reliability.
For UAV work, pay close attention to dropped packets and timing. A desktop demo can hide issues that show up once the drone is vibrating, the CPU is busy, and multiple processes are competing for bandwidth.
UVC Integration
UVC is convenient for rapid development because the LiDAR can be accessed in a camera-like way. Developers can stream depth frames to a PC, Raspberry Pi, or Linux application using familiar video capture workflows. For early prototyping, UVC can reduce integration friction and make it easier to display depth maps, test algorithms, and validate sensor behavior.
This is especially useful during the first phase of a project, when the team is still learning what the sensor sees, how surfaces behave, and what filtering the application needs. Once the prototype works, the team can decide whether to keep UVC or move toward UDP, UART, or another production-friendly interface.
SDK Platform Support
MRP offers SDK support for the HM-LD1 across x86 Windows, x86 Linux, and ARM Linux. This platform coverage is important because industrial teams often prototype on Windows or x86 Linux, then deploy on ARM Linux hardware such as Raspberry Pi, Jetson, or other embedded computers. A practical SDK can help teams move from bench testing to flight testing with fewer driver-level obstacles.
Do not underestimate SDK maturity. Good example code, clear documentation, and stable platform support can save weeks of engineering time. Bad drivers can turn a promising sensor into a permanent prototype.
ROS and Middleware Considerations
In a ROS workflow, raw depth data can be converted into topics such as depth images, point clouds, or range messages. Developers may publish data using message types such as sensor image messages, point cloud messages, or custom distance messages. The perception stack may fuse LiDAR with IMU, odometry, visual-inertial data, or SLAM outputs. For navigation, processed obstacle layers can be used to support avoidance, path planning, and local mapping.
For production UAVs, middleware should be treated as part of the safety architecture. Message timing, queue sizes, frame IDs, coordinate transforms, and failure behavior all need to be reviewed. A drone does not care whether the bug is in the LiDAR driver, the transform tree, the flight controller interface, or the planner. If the data is late or wrong, the aircraft still reacts to bad information.
RTK, GNSS, INS, and Georeferenced UAV Mapping
Why LiDAR Needs Positioning for Mapping
LiDAR measures distance relative to the sensor. If a drone is moving, rotating, vibrating, or changing altitude, each point must be transformed from the sensor frame into the drone frame and then into a global coordinate frame. That transformation requires position, orientation, calibration, and timing. Without accurate pose information, a point cloud may be useful locally but not suitable for survey-grade mapping.
This is one of the most common misunderstandings in UAV LiDAR. A LiDAR module can produce depth data, but that does not automatically produce a georeferenced survey deliverable. For that, every measurement needs to be tied to a trustworthy estimate of where the sensor was and how it was oriented at the time of capture.
RTK vs PPK
RTK provides real-time positioning corrections during flight. PPK applies corrections after the flight using recorded GNSS data. Both methods can improve mapping accuracy when implemented correctly. RTK can support real-time awareness, while PPK is often valued for post-processing robustness. The right choice depends on workflow, communication reliability, accuracy requirements, and survey procedures.
For industrial mapping, this decision is usually about operations as much as technology. If you need real-time field feedback, RTK may be attractive. If communication links are unreliable or the workflow is built around careful post-processing, PPK may make more sense.
IMU and INS Role
The IMU measures angular velocity and acceleration. An INS combines inertial data with GNSS and other inputs to estimate position and attitude over time. Roll, pitch, yaw, vibration, and timing errors can strongly affect LiDAR mapping quality. For aerial mapping, even small attitude errors can become large positional errors at distance. For a deeper explanation of centimeter-level positioning, read What Is RTK? The Centimeter-Level GPS Navigation Guide.
In other words, the LiDAR is only one part of the measurement chain. If the timing is off, the boresight calibration is poor, or the INS solution is weak, the final point cloud can be wrong even if the range measurements themselves are accurate.
Recommended Compact dToF LiDAR Module: DTOF Solid State LiDAR HM-LD1
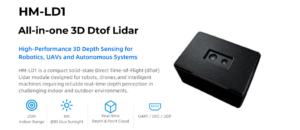
The DTOF Solid State LiDAR HM-LD1 is a compact SPAD dToF LiDAR module designed for real-time depth imaging and point cloud output. For UAV developers, its low weight, low power consumption, compact size, and multiple interfaces make it suitable for embedded drone perception, altitude hold, terrain following, obstacle avoidance, smart inspection, and robotic vision development. It supports real-time depth images and 3D point cloud data for accurate environmental perception.
View product: DTOF Solid State LiDAR HM-LD1

View Product Details & Pricing ➔
| DTOF Solid State LiDAR HM-LD1 Specifications | |
|---|---|
| Product Name | DTOF Solid state LiDAR HM-LD1 – DTOF SSL |
| Technology | SPAD dToF solid-state LiDAR |
| Dimension | 43.5 mm × 30 mm × 26.5 mm |
| Ranging Capability | Indoor: 0.5–25 m; Outdoor: 0.2–8 m |
| Ranging Accuracy | ±3 cm |
| Field of View | 60° horizontal × 45° vertical |
| Weight | 28 g |
| Resolution | 40 × 30 |
| Frame Rate | 10 fps |
| Interface | UART / UDP / UVC |
| Operating Temperature | -20 ℃ to 60 ℃ |
| Power Consumption | 1.2 W |
| SDK Support | x86 Windows, x86 Linux, ARM Linux |
| Typical Applications | UAV altitude hold, terrain following, obstacle avoidance, distance detection, robot navigation, SLAM development, smart inspection, robotic vision |
Point Cloud and Depth Map Output
The HM-LD1 can provide ranging measurement data displayed as point cloud and depth data. For UAV and robotics development, this is important because teams can start with a visual depth map for evaluation, then convert depth pixels into local 3D points or obstacle zones. The same sensor data may be used for visualization, perception algorithm development, surface distance monitoring, or closed-loop flight behaviors after proper system validation.
Long Measurement Range in a Compact Class
The module is designed for accurate ranging, including outdoor use within its specified range. Product details note that it can measure up to 8 meters outdoors on a clear summer day assuming 80,000 lux. This makes it useful for measuring distances to objects that may be difficult for people to approach, such as bridges, expressways, and dams, provided the mission fits the sensor’s range, field of view, and environmental limits.
Why HM-LD1 Fits Compact UAV and Robotics Development
The 28 g weight reduces payload burden, while 1.2 W power consumption is friendly for battery-operated systems. The 60° × 45° FOV supports near-field spatial perception, and the UART, UDP, and UVC interfaces give engineers multiple integration paths. SDK support across x86 Windows, x86 Linux, and ARM Linux helps teams move from desktop development to embedded deployment. This is particularly valuable for UAV developers working with Raspberry Pi, Jetson, embedded Linux boards, or robotics middleware.
Best-Fit Use Cases for HM-LD1
Best-fit use cases include indoor drone obstacle avoidance, UAV altitude hold, short-range terrain following, bridge and dam distance detection, expressway inspection assistance, robot navigation, SLAM research, embedded 3D perception, Raspberry Pi or Jetson prototypes, smart inspection systems, user presence detection, object recognition, volume measurement, and zone intrusion monitoring. It is especially relevant when the design target is a compact drone or robot with limited payload capacity.
When to Choose a Larger Mapping LiDAR Instead
The HM-LD1 is a compact depth LiDAR module, not a complete long-range survey payload with GNSS, RTK, INS, and post-processing software. If your mission requires high-altitude corridor mapping, wide-area topographic surveying, forestry mapping, or survey-grade georeferenced point clouds, a mapping-grade UAV LiDAR payload may be more appropriate. If your mission requires local perception, obstacle detection, short-range inspection, or embedded 3D sensing, a compact dToF LiDAR module can be a practical and efficient choice.
Recommended Integration Workflows for 3D Drone LiDAR
Workflow 1: Raspberry Pi Prototype
A Raspberry Pi prototype is often the fastest way to validate sensor behavior. Connect the LiDAR through UVC, UART, or UDP depending on the data stream required. Use the ARM Linux SDK to receive depth information, display the depth map, and test range behavior on real targets. After basic validation, convert depth data into obstacle zones or distance triggers and send simplified signals to the flight controller. This workflow is suitable for early-stage UAV perception, indoor testing, and robotics education.
✅ Best fit: early bench testing, basic depth visualization, simple obstacle logic, and low-cost embedded experimentation.
⚙️ Engineering note: test the sensor with the motors running before trusting the results. Vibration, electrical noise, cable routing, and power supply quality can change behavior once the aircraft is assembled.
Workflow 2: Jetson AI Perception Stack
A Jetson-based architecture is useful when the UAV needs AI perception, sensor fusion, or ROS integration. Stream depth maps or point clouds to the Jetson, fuse the data with camera or IMU inputs, and run obstacle segmentation or object detection. Publish the results to ROS middleware and generate avoidance commands or safety zones. This workflow is suitable for developers building autonomous drones, smart inspection systems, or research platforms that combine LiDAR with computer vision.
✅ Best fit: robotics research, autonomous inspection, ROS development, AI-assisted perception, and multi-sensor fusion.
⚙️ Engineering note: watch CPU and GPU load carefully. A perception stack that runs fine on a desk can miss timing targets once logging, visualization, communication, and flight-control processes are all active.
Workflow 3: Flight Controller Distance Sensor
For altitude hold or proximity detection, the goal may be to send simplified distance data to the flight controller. In this workflow, UART can be used to extract distance information or processed measurements. The companion controller converts that information into a flight-controller-supported format. Engineers must test filtering, update rate, failsafe behavior, mounting angle, and vibration effects before enabling closed-loop flight.
✅ Best fit: altitude hold, proximity warnings, simple safety triggers, and lightweight production-style integrations.
⚙️ Engineering note: do not feed raw noisy readings directly into a control loop without filtering and validation. Bad distance data can cause oscillation, false braking, or unstable altitude corrections.
Workflow 4: UAV Inspection System
For inspection, mount the sensor forward-facing, downward-facing, or angled depending on the structure. Stream depth data to an onboard computer, estimate surface distance, and maintain a safe standoff from bridges, dams, walls, or industrial equipment. The system can log depth data for review and can assist operators by warning when the UAV is too close to a surface. This workflow is most effective when combined with good mechanical mounting, stable calibration, and field testing.
✅ Best fit: bridge inspection, dam inspection, expressway inspection, wall following, industrial distance monitoring, and operator-assist safety systems.
⚙️ Engineering note: inspect the lens area and enclosure design. Dust, water spots, scratches, and protective covers can affect optical performance. In field work, the mechanical details are not cosmetic; they are part of the sensor system.
Common Mistakes When Buying 3D Drone LiDAR
Mistake 1: Choosing Maximum Range Instead of Mission Fit
Maximum range is not always the most important metric. A compact drone performing indoor navigation may benefit more from low weight, low latency, wide enough FOV, and stable SDK support than from extreme range. A survey drone, however, may need long range and georeferenced mapping capability. Start with the mission and then choose the sensor class.
Look, range is easy to compare because it is a single number. But UAV performance is never one number. The right sensor is the one that fits your range, update rate, aircraft size, integration path, and mission environment at the same time.
Mistake 2: Ignoring Outdoor Sunlight Performance
Bright sunlight can reduce effective range, especially for compact depth sensors. Always check outdoor ratings instead of relying only on indoor or laboratory values. Test the sensor on realistic targets under expected lighting conditions. Concrete, asphalt, vegetation, metal, glass, black plastic, and water can behave very differently.
In the shop, indoor testing is where you start. It is not where you finish. If the drone will fly outdoors, validate the sensor outdoors, at the operating distance, on the actual surfaces, and under realistic sunlight.
Mistake 3: Underestimating SDK and Driver Work
Integration time can exceed hardware cost if the sensor lacks documentation, SDK support, Linux examples, ARM compatibility, or clear output formats. For UAV projects, software accessibility is a major selection criterion. Choose hardware that matches your development platform and production architecture.
A sensor with UART, UDP, UVC, and SDK support across x86 Windows, x86 Linux, and ARM Linux gives a team more room to build, test, and deploy. That flexibility matters when the prototype starts on a laptop and ends up on a Raspberry Pi, Jetson, or custom embedded platform.
Mistake 4: Treating Local Depth LiDAR as a Complete Mapping Payload
A local dToF depth LiDAR can provide valuable depth maps and point clouds, but that does not automatically make it a survey-grade mapping system. Mapping requires accurate position, orientation, timing, calibration, and usually RTK, PPK, GNSS, and INS integration. Understand the difference before specifying hardware.
This mistake shows up all the time. A local point cloud is useful, but survey mapping is a full measurement workflow. If the final deliverable needs to line up with the real world, the positioning stack is not optional.
Mistake 5: Ignoring Mechanical Mounting and Vibration
Mechanical integration is often overlooked. Sensor alignment, vibration isolation, cable strain relief, thermal conditions, propeller wash, lens protection, and mounting rigidity all affect performance. Before flight, test the sensor on the actual frame with motors running, because bench performance may not reflect airborne conditions.
Good mechanical design is not just about making the payload look clean. It protects the sensor, stabilizes the data, reduces failures, and makes calibration repeatable. That is the kind of detail that separates a one-off demo from a reliable UAV system.
FAQ: 3D Drone LiDAR
Can I use 2D LiDAR for 3D drone mapping?
What should beginners consider before buying a LiDAR drone system?
How do I choose LiDAR hardware for indoor autonomous drones or MAVs?
Is 3D drone LiDAR better than photogrammetry?
What is the difference between drone LiDAR mapping and drone obstacle avoidance LiDAR?
What LiDAR range do I need for a drone?
Can 3D drone LiDAR work outdoors in bright sunlight?
Does a LiDAR sensor alone make a drone autonomous?
What interface is best for UAV LiDAR integration: UART, UDP, or UVC?
Can I use a compact dToF LiDAR for UAV mapping?
Choosing the Right 3D Drone LiDAR Starts with the Integration Path
The best 3d drone lidar choice depends on what the UAV must accomplish. If you need survey-grade maps, evaluate LiDAR plus RTK, GNSS, INS, calibration, synchronization, and post-processing software. If you need real-time obstacle avoidance, evaluate range, field of view, frame rate, latency, interface options, and SDK support. If you need compact UAV perception, prioritize weight, power consumption, mechanical integration, and embedded Linux compatibility. If you are prototyping with Raspberry Pi, Jetson, or x86 Linux, choose a sensor with accessible SDKs and practical interfaces.
Look at the full chain before you buy: sensor, mount, power, interface, companion computer, SDK, middleware, flight controller, test procedure, and failsafe logic. That is how real UAV systems get built. The sensor is important, but the integration path is what turns it into a working aircraft capability.
For compact UAV perception, obstacle avoidance, terrain following, and embedded 3D sensing development, explore the DTOF Solid State LiDAR HM-LD1.
View Product Details & Pricing ➔
📚 References & Further Reading
- Industry Standard: SICK industrial LiDAR and sensor solutions
- Industry Standard: HOKUYO scanning LiDAR reference
- Related Guide: What Is RTK? The Centimeter-Level GPS Navigation Guide
- Related Guide: What Phase Means in 3D Structured Light Cameras
- Product Page: DTOF Solid State LiDAR HM-LD1








