

LiDAR Scanner iPhone: Is It Worth It for 3D Scanning, Measurement, and Robotics Prototyping?
Here’s the deal: if you searched for “lidar scanner iphone,” you are probably trying to figure out whether the LiDAR sensor inside newer iPhone Pro and iPad Pro models is a serious tool or just another spec-sheet feature that sounds better than it works. For room scanning, AR previews, quick 3D reference models, rough measurements, and low-light autofocus, the iPhone LiDAR scanner can be genuinely useful. It gives architects, designers, makers, real estate teams, educators, and hobbyists a fast way to capture depth information without hauling around a separate scanner.
Look, the answer changes fast once the job moves from casual scanning into repeatable measurement, robotics prototyping, UAV altitude sensing, SLAM support, obstacle avoidance, embedded vision, or industrial inspection. In those applications, engineers need more than a nice phone-based scanning experience. They need defined range performance, stable interfaces, point cloud or depth map access, SDK support, predictable frame rate, low power consumption, and a sensor that can actually be mounted inside a robot, drone, camera, or edge device. This guide compares the iPhone LiDAR scanner with dedicated dToF LiDAR modules and explains when a product like the DTOF Solid state LiDAR HM-LD1 becomes the more practical choice.
Table of Contents
- 👉 Quick Answer: Is iPhone LiDAR Worth It?
- 👉 What Is the LiDAR Scanner on iPhone?
- 👉 How iPhone LiDAR Works
- 👉 Best Uses for iPhone LiDAR Scanning
- 👉 Where iPhone LiDAR Falls Short
- 👉 iPhone LiDAR Apps, Exports, and Cost Considerations
- 👉 What Industrial and Robotics Projects Need from LiDAR
- 👉 iPhone LiDAR vs Dedicated dToF LiDAR Module
- 👉 Dedicated Product Example: DTOF Solid State LiDAR HM-LD1
- 👉 How to Choose the Right LiDAR Scanner
- 👉 Recommended Workflows by Use Case
- 👉 FAQ
- 👉 Final Verdict
Quick Answer: Is iPhone LiDAR Worth It?
Short answer: yes, the iPhone LiDAR scanner is worth it for quick 3D scans, AR previews, room capture, and rough measurements. No, it is not the right answer for most robotics, UAV, industrial inspection, or embedded product development work. Once you need repeatable data, hardware interfaces, SDK access, and known performance, a dedicated dToF LiDAR module is usually the better tool.
For everyday users, the iPhone LiDAR scanner earns its keep because it reduces friction. You can scan a room, preview furniture in AR, capture a rough 3D reference, document an interior, estimate dimensions, or improve low-light focusing without setting up specialized equipment. If the goal is visual understanding, fast capture, or a convenient planning reference, an iPhone with LiDAR can be surprisingly useful.
In the shop, though, convenience is only one part of the story. Robotics perception, industrial mapping, UAV navigation, outdoor detection, repeatable measurement validation, and embedded product development require more control than a phone-based scanning workflow normally provides. A robot or drone needs a sensor that can be mounted, powered, connected, streamed, calibrated, and validated. The simple rule is this: use iPhone LiDAR for fast capture and visualization; use a dedicated dToF LiDAR module for integration, repeatability, and engineering control.
Engineering takeaway: if your goal is robotics, UAV sensing, or embedded depth perception, compare phone-based scanning with a dedicated module such as the DTOF Solid state LiDAR HM-LD1.
What Is the LiDAR Scanner on iPhone?
iPhone LiDAR in Simple Terms
LiDAR stands for Light Detection and Ranging. In plain English, a LiDAR system sends out light, detects the reflected signal from nearby surfaces, and estimates distance from the return information. On Apple devices, the LiDAR scanner supports depth-aware experiences such as ARKit applications, scene understanding, people occlusion, faster plane detection, room scanning, low-light autofocus, and app-based measurement.
The consumer experience is intentionally simple. You do not need to understand optical timing, detectors, calibration, or reconstruction algorithms to use it. You open an app, move the phone around a room or object, and the software turns captured depth and camera information into something useful, such as a mesh, floor plan, 3D preview, or measurement estimate. That simplicity is the biggest strength of the iPhone LiDAR scanner.
Which iPhones Have LiDAR?
LiDAR is generally found on Pro-level iPhone models and certain iPad Pro models. Apple changes its product lineup over time, so buyers should always verify the current Apple specifications before purchasing a device specifically for LiDAR scanning. The practical point is simple: not every iPhone has a LiDAR scanner. Do not assume the feature is included just because the phone is new.
Why Users Search for “LiDAR Scanner iPhone”
Most searches for “lidar scanner iphone” come from practical questions. People want to know whether their iPhone can scan a room, create a 3D model, measure objects accurately, export a file for CAD or 3D printing, or replace a dedicated scanner. Developers may also ask whether iPhone LiDAR can be used for robotics, SLAM, or machine perception.
Those are not all the same question. For a room layout reference, the iPhone is convenient. For an autonomous system that must react to depth data in real time, a dedicated sensor is usually more appropriate. That difference matters because buying the wrong LiDAR tool often leads to wasted time, cleanup work, export problems, or a prototype that cannot move beyond a demo.
For broader context on LiDAR technology and the global sensing market, readers can also review industry resources from Hesai Technology.
How iPhone LiDAR Works
Time-of-Flight Depth Sensing
At a high level, LiDAR depth sensing uses a light source and a detector. The system emits light toward the scene, receives reflected light from surfaces, and estimates distance using timing or signal information. This is commonly discussed as time-of-flight sensing because distance is related to how long it takes light to travel to a surface and return to the sensor.
On an iPhone, that process is not just raw sensor physics. The device combines LiDAR data with camera images, motion data, AR frameworks, and scene understanding algorithms. This improves AR placement, object occlusion, room capture, and the scan quality seen by the user. It also means the final result depends heavily on software choices, not just the depth sensor itself.
Depth Map vs Point Cloud vs Mesh
A depth map is a distance field that stores how far surfaces are from the sensor at sampled points or pixels. A point cloud is a collection of 3D points representing surfaces in space. A mesh is a connected polygon surface reconstructed from depth information, camera data, and software algorithms. Many iPhone scanning apps show a polished mesh or room model rather than exposing the raw sensing pipeline.
This difference matters in engineering. A designer may only need a textured mesh or a floor plan. A robotics engineer may need live depth maps, point cloud data, synchronized timestamps, stable coordinate frames, and predictable sensor streams. Dedicated LiDAR modules are usually designed to expose this type of data more directly, while phone apps often hide complexity behind a clean user interface.
Why Software Matters as Much as the Sensor
The quality of an iPhone LiDAR scan depends strongly on the app. Different apps use different reconstruction algorithms, export formats, smoothing methods, measurement tools, and pricing models. A scan that looks impressive on the phone may still require cleanup before it can be used in CAD, simulation, game engines, robotics datasets, or inspection software.
Measurements can also vary based on lighting, surface material, scanning distance, user motion, and calibration assumptions. Look closely and you will often see the tradeoff: software makes the scan look cleaner, but that cleanup can also hide gaps, soften edges, or infer surfaces that the sensor did not actually measure well.
For readers who want a deeper optical engineering background, SPIE publishes extensive material on photonics, imaging, and sensing technologies.
Best Uses for iPhone LiDAR Scanning
Room Scanning and Interior Capture
Room scanning is one of the strongest everyday use cases for iPhone LiDAR. Interior designers, real estate teams, renovation planners, facility managers, and homeowners can use it to capture walls, floors, openings, furniture placement, and spatial context. The output can be used as a planning reference, a documentation layer, or a starting point for design discussion.
Here’s where it shines: it is fast. You can walk a space, capture useful geometry, share a model, and start a conversation without setting up tripods or dedicated scanning equipment. For early planning, that speed is valuable.
The important limitation is that speed is not the same as survey-grade accuracy. iPhone LiDAR can help users understand a space quickly, but critical construction dimensions, fabrication measurements, safety clearances, and compliance-related values should be verified with professional tools. The phone scan is excellent for context and communication; it should not always be treated as the final measurement authority.
3D Object Scanning and Creative Workflows
For creative users, iPhone LiDAR can be a practical way to capture props, furniture, sculptures, room assets, and object references. Artists and game developers may use scans as starting points for modeling. E-commerce teams may create rough visualization assets. AR developers may use scanned geometry to test placement and interaction concepts.
Not every object scans well. Shiny, transparent, thin, black, highly detailed, or complex objects can produce incomplete geometry or noisy surfaces. Apps may fill gaps or smooth geometry, which can make the model look better but reduce geometric fidelity. For casual visualization, this may be acceptable. For reverse engineering, dimensional inspection, or precision manufacturing, it is not enough.
Measurement and Estimation
iPhone LiDAR is useful for approximate dimensions, room volume estimates, furniture spacing, quick construction notes, and early planning. It can help answer practical questions such as whether a sofa might fit in a room, how much clearance exists around equipment, or what approximate area a space occupies. That makes it valuable for field notes and fast decision-making.
For professional measurement, users should be cautious. Measurement quality depends on scan technique, distance, surface reflectivity, app processing, and environmental conditions. A clean-looking result may still contain dimensional error. If repeatable accuracy is required, use a calibrated measuring tool or a dedicated sensor with published specifications.
AR Placement and Scene Understanding
Apple’s LiDAR implementation is especially useful for AR. It improves plane detection, object occlusion, anchoring, low-light scene recognition, and spatial understanding. This allows apps to place virtual furniture, characters, measurement overlays, design previews, or training content more convincingly in a real environment.
For many users, AR improvement is one of the most noticeable benefits of having LiDAR on an iPhone. You may not think about the sensor directly, but you notice that virtual objects sit more naturally in the room, the app finds surfaces faster, and the overall experience feels less jumpy.
Where iPhone LiDAR Falls Short
Limited Raw Data Control
Developers can access depth-related data through Apple frameworks, but product teams building robots, drones, inspection systems, or embedded devices often need more direct control. They may need deterministic data streams, interface-level control, synchronization, repeatable frame timing, custom filtering, and long-term support for a specific deployment environment.
This is not a failure of the iPhone. It is a mismatch of purpose. The iPhone LiDAR scanner is optimized for user experience inside the Apple ecosystem. Industrial sensing hardware is optimized for integration into machines, control systems, and embedded perception stacks.
App Lock-In and Export Restrictions
Many users discover that scanning is only part of the workflow. Exporting the data in a useful format may require a paid app, subscription, cloud processing plan, or professional license. Free apps may limit scan size or file export. One-time payment apps may not include advanced measurement or CAD features. Subscriptions often gate OBJ, PLY, E57, USDZ, textured mesh, BIM, or high-resolution export workflows.
For occasional users, this may be fine. For teams that repeatedly scan, export, process, and validate data, app dependency becomes a cost and workflow risk. If an app changes pricing, removes a feature, or modifies its cloud processing pipeline, the workflow can break.
Accuracy and Repeatability Challenges
Handheld scanning introduces variation. User motion, scan path, distance from the target, lighting, reflective materials, dark surfaces, thin edges, and reconstruction algorithms all influence the result. Apps may smooth, simplify, or infer surfaces to produce visually clean models. That is helpful for presentation but risky for engineering validation.
Repeatability is one of the biggest differences between casual scanning and industrial sensing. A robot or inspection system cannot rely on a person walking around with a phone. It needs a sensor installed in a known position, collecting data continuously under known conditions.
Range and Outdoor Performance Constraints
Outdoor sensing is difficult for many depth systems because sunlight, reflectivity, distance, and surface geometry affect signal quality. iPhone LiDAR can be useful outdoors for short-range tasks and visual references, but performance may be less predictable than users expect.
Outdoor robotics, UAV altitude sensing, inspection, and safety-related applications generally require sensors with documented outdoor range and environmental performance. In the shop or in the field, “it seemed to work on my phone” is not a validation plan.
No Direct Embedded Deployment
An iPhone cannot be easily embedded as a production sensor inside a robot, UAV, industrial inspection device, or machine vision unit. Even if it works for a proof-of-concept demo, the hardware, operating system, battery, thermal behavior, app dependency, mounting approach, and data interfaces are not designed for OEM deployment.
For a machine that must sense continuously and reliably, a dedicated module is the more realistic path. A production sensor needs mounting points, power planning, data interfaces, environmental limits, support documentation, and predictable supply. A phone is a consumer device first.
iPhone LiDAR Apps, Exports, and Cost Considerations
Free, One-Time Payment, and Subscription Apps
iPhone LiDAR apps vary widely in pricing. Some free apps support basic room scanning or simple 3D capture. Some one-time purchases are suitable for casual users who only need occasional exports. Professional apps may use subscriptions for CAD conversion, BIM workflows, cloud reconstruction, high-resolution scan processing, commercial usage, advanced measurement tools, or team collaboration.
The right app depends on the user’s output goal. If the goal is to see a room in 3D or share a quick visual model, a basic app may be enough. If the output must be imported into CAD, a game engine, simulation software, inspection workflow, or robotics dataset, export quality and file format support become more important than the scanning experience itself.
Export Formats to Evaluate
Common export formats include OBJ, PLY, STL, USDZ, GLB, glTF, E57, DXF, and CAD-related formats where available. OBJ and GLB are common for visual 3D assets. PLY can be useful for point cloud workflows. STL is often associated with 3D printing, although scan cleanup is usually needed. USDZ is common in Apple AR workflows. E57 may matter for point cloud and scanning professionals.
Before paying for an app, verify whether the required export format is included and whether exports preserve the needed geometry, scale, texture, point cloud, or metadata. That sounds obvious, but it is one of the most common places where a quick scanning experiment turns into an annoying workflow problem.
When App Cost Becomes a Hardware Decision
If a team repeatedly pays for scanning, export, cloud processing, or professional features, a dedicated LiDAR sensor may become more cost-effective over time. This is especially true when the project needs live data instead of static export files.
A hardware module with SDK access can reduce dependence on app pricing and provide a more stable development path for robotics, UAVs, smart security, inspection, and embedded vision. The cost is not only the purchase price. It is the total cost of getting reliable data into the system you are building.
What Industrial and Robotics Projects Need from LiDAR
Defined Range and Accuracy
Industrial systems need published specifications. Engineers must understand indoor range, outdoor range, accuracy tolerance, minimum detection distance, maximum reliable range, field of view, lighting assumptions, surface conditions, and environmental limits. Without these values, it is difficult to design, validate, or troubleshoot a sensing system.
The DTOF Solid state LiDAR HM-LD1 specifies indoor ranging capability of 0.5–25 m, outdoor ranging capability of 0.2–8 m, and ranging accuracy of ±3 cm. Those numbers give engineers a clearer basis for testing than a general phone scanning workflow.
Frame Rate and Resolution
Frame rate affects how quickly a system can react to changes. Resolution affects how much shape detail the sensor can observe. Not every project requires high-resolution depth. For obstacle avoidance, zone detection, altitude sensing, or object presence monitoring, compact depth sensing may be sufficient if the range, field of view, and update rate match the task.
HM-LD1 provides 40 × 30 resolution and 10 fps output, which suits compact obstacle detection, distance sensing, area monitoring, and lightweight embedded perception workflows. For fine mapping or high-detail 3D reconstruction, teams should evaluate whether that resolution is sufficient for their target object size and detection distance.
Interfaces for Real Integration
Interfaces matter because sensors must communicate with controllers. UART is useful for microcontrollers and embedded controllers. UDP supports networked systems and Linux development. UVC can simplify camera-like depth stream integration. SDK support can shorten development time and reduce low-level integration effort.
HM-LD1 supports UART, UDP, and UVC, with SDKs for x86 Windows, x86 Linux, and arm Linux. That makes it relevant to PCs, Raspberry Pi systems, embedded Linux devices, robotics controllers, and development platforms where direct data access is required.
Size, Weight, and Power
Mobile robots need compact sensors. UAVs are sensitive to payload because every gram can affect flight time and stability. Battery-powered systems need low power consumption. Enclosed devices must also consider thermal behavior and mounting constraints.
HM-LD1 is specified at 43.5 mm × 30 mm × 26.5 mm, weighs 28 g, and consumes 1.2 W. Those values make it suitable for compact devices where space, power, and weight are important design constraints.
Development Support and Supply Stability
Industrial buyers evaluate more than a sensor’s headline range. They also need documentation, SDK availability, technical support, sample data, integration guidance, manufacturing stability, and customization options. A sensor can be technically promising but difficult to deploy if the supplier cannot support real integration work.
For engineering teams evaluating compact dToF depth sensing, review the DTOF Solid state LiDAR HM-LD1 product page and request the product brochure for integration details.
iPhone LiDAR vs Dedicated dToF LiDAR Module
Comparison Table
| Evaluation Factor | iPhone LiDAR Scanner | Dedicated dToF LiDAR Module |
|---|---|---|
| Best For | AR, room scanning, quick 3D references, casual measurement | Robotics, UAVs, embedded vision, inspection, obstacle detection |
| Integration | App and Apple ecosystem dependent | Direct hardware integration through interfaces and SDKs |
| Raw Data Access | Limited by app and framework | Designed for depth maps, point cloud data, and sensor streams |
| Deployment | Useful for field capture and prototyping demos | Suitable for product development and embedded systems |
| Cost Model | Phone cost plus app subscriptions or export fees | Hardware module cost plus integration development |
| Engineering Control | Lower | Higher |
Practical Decision Summary
Choose iPhone LiDAR if the output is a visual scan. Choose dedicated dToF LiDAR if the output is system behavior. Choose iPhone LiDAR for documentation, room capture, creative references, and AR previews. Choose a dedicated dToF LiDAR module for automation, obstacle detection, UAV altitude sensing, smart inspection, embedded perception, and continuous sensing.
This distinction helps avoid overbuying or underengineering. A homeowner does not need an embedded LiDAR module to preview furniture. A robot developer should not depend on a handheld phone scan to build obstacle avoidance. The best choice depends on whether the project needs a file, a visual model, or a live sensor stream.
Dedicated Product Example: DTOF Solid State LiDAR HM-LD1
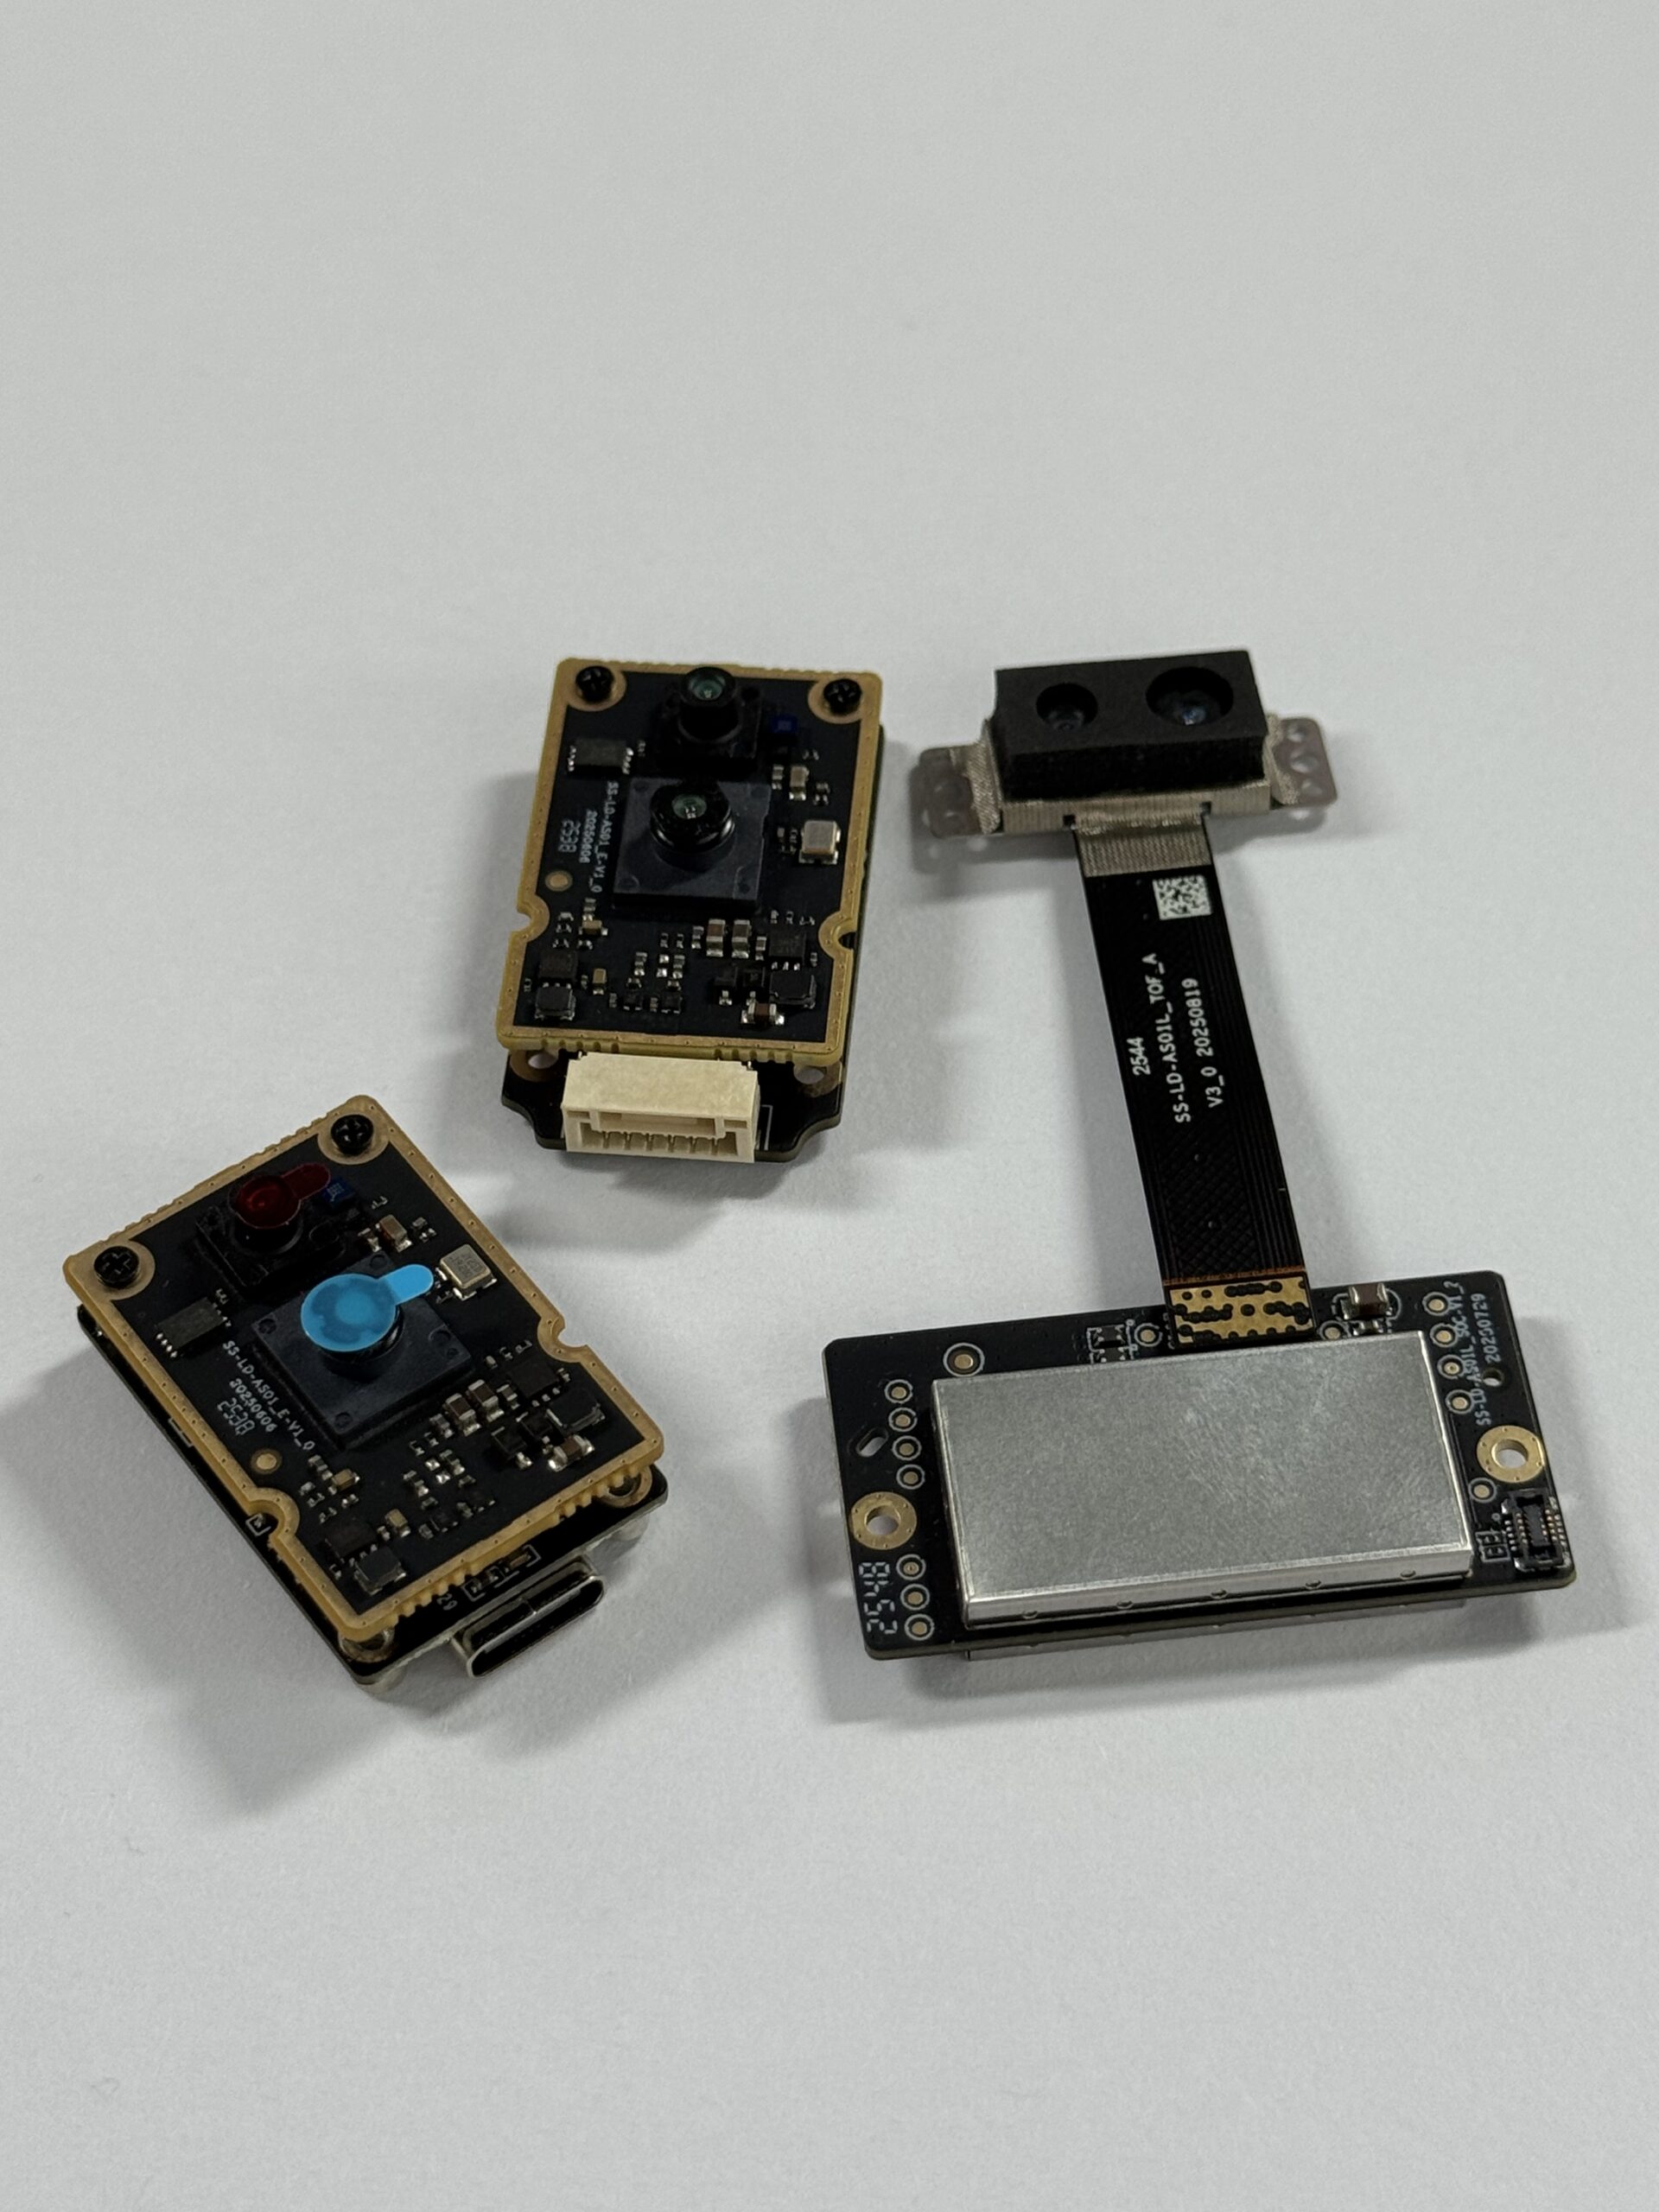
The DTOF Solid state LiDAR HM-LD1 is a compact solid-state LiDAR module based on SPAD dToF technology. Unlike a phone-based LiDAR scanner, it is intended for direct integration into robots, UAVs, cameras, security systems, inspection devices, and embedded perception platforms. It provides real-time depth images and 3D point cloud data for environmental perception, obstacle avoidance, distance detection, autonomous navigation, smart inspection, and robotic vision development.
HM-LD1 is especially relevant when a team has already proven that depth sensing is useful but now needs a practical sensor for hardware integration. It supports multiple interfaces, documented performance values, and development platforms that are more aligned with engineering workflows than app-based phone scanning.
View product details: DTOF Solid state LiDAR HM-LD1
| Specification | DTOF Solid State LiDAR HM-LD1 |
|---|---|
| Technology | SPAD dToF solid-state LiDAR |
| Dimensions | 43.5 mm × 30 mm × 26.5 mm |
| Ranging Capability | Indoor: 0.5–25 m; Outdoor: 0.2–8 m |
| Ranging Accuracy | ±3 cm |
| Field of View | 60° horizontal × 45° vertical |
| Weight | 28 g |
| Resolution | 40 × 30 |
| Frame Rate | 10 fps |
| Interface | UART / UDP / UVC |
| Operating Temperature | -20 ℃ to 60 ℃ |
| Power Consumption | 1.2 W |
| Supported Development Platforms | x86 Windows, x86 Linux, arm Linux SDK support |
View Product Details & Pricing ➔
Where HM-LD1 Fits Best
HM-LD1 supports applications across UAVs, robots, cameras, and security systems. It can be used for UAV altitude hold and terrain following, robot obstacle avoidance, SLAM support, object detection, zone intrusion monitoring, smart inspection, volume measurement, user presence detection, autofocus, and camera support. Its compact housing and low weight make it relevant for platforms where payload and space are limited.
For outdoor applications, the specified 0.2–8 m outdoor ranging capability provides a defined basis for evaluating detection zones, inspection distances, and obstacle avoidance behavior. For indoor or nighttime environments, the specified 0.5–25 m ranging capability supports longer detection scenarios in warehouses, labs, robot testing areas, and controlled inspection sites.
Why It Matters for Prototyping
An engineering team can use an iPhone LiDAR scanner to explore whether depth sensing is useful, but it cannot easily turn that phone scan into a deployable robotic perception subsystem. HM-LD1 is different because it exposes practical integration pathways through UART, UDP, and UVC, while supporting common development environments. This lets developers move from desktop testing to Raspberry Pi, embedded Linux, flight controller, or robot controller workflows.
MRP also describes support for x86 Windows, x86 Linux, and arm Linux SDKs, which matters because robotics and industrial teams rarely work in a single operating environment. A prototype may start on a Windows workstation, move to Linux for robot testing, and then migrate to an ARM-based embedded computer. SDK availability helps reduce the friction of that development path.
How to Choose the Right LiDAR Scanner
Choose iPhone LiDAR If
Choose iPhone LiDAR if you need fast room scans, visual references, AR concept testing, interior planning, casual measurement, or easy 3D capture. It is a strong option when convenience matters more than sensor-level control. It is also a good way to introduce teams to spatial capture before investing in dedicated hardware.
✅ It fits well when a human is driving the workflow: a person scans a room or object, reviews the result, exports a model, and uses that model for planning, presentation, or reference. If that is your workflow, the iPhone LiDAR scanner may be all you need.
Choose a Dedicated LiDAR Module If
Choose a dedicated LiDAR module if you need published sensor specifications, repeatable range data, depth maps, point clouds, embedded interfaces, SDK support, technical support, or direct integration into a robot, UAV, inspection system, smart camera, or industrial device. Dedicated modules are better when the sensor is part of the product rather than just a tool used to create a file.
⚙️ It is the better path when your controller needs live depth data, your enclosure needs a mounted sensor, your software needs predictable input, or your customer expects repeatable performance. That is where a module like HM-LD1 starts to make more sense than a phone.
Key Questions Before Buying
Before choosing a LiDAR scanner or module, define the actual requirement. What range do you need indoors and outdoors? Is accuracy specified under your expected lighting conditions? Do you need point cloud data, depth maps, or only distance values? What interface does your controller support? What operating system will run the application? What are your size, weight, and power limits? Will this be a demo, a prototype, or a production device?
These questions prevent a common mistake: choosing hardware based on a feature name instead of system requirements. “LiDAR” alone does not define performance. The right sensor is the one that matches range, field of view, frame rate, resolution, integration, environment, and cost constraints.
Recommended Workflows by Use Case
For Architects, Designers, and Real Estate Teams
✅ Use iPhone LiDAR for initial room scans and visual documentation. Export a mesh, floor plan, or room model if your app supports the required format. Clean the data in design software when needed, and validate critical dimensions with professional measurement tools. Treat the scan as a visual planning layer rather than the sole source of truth for construction or fabrication.
In practical terms, this means the iPhone is excellent for early conversations. It helps everyone see the same space and understand layout constraints. But when the design moves into ordering materials, cutting parts, or approving construction work, verify the numbers with proper measuring equipment.
For Robotics and UAV Developers
⚙️ Use iPhone LiDAR only for early concept exploration, environment capture, or demonstration. Then define detection range, field of view, accuracy, frame rate, operating environment, and interface requirements. Select a module such as HM-LD1 for embedded testing, stream data through UART, UDP, or UVC, and validate obstacle detection, altitude hold, terrain following, or SLAM behavior in real environments.
In the shop, this is the difference between a clever demo and a real prototype. A demo can prove the idea. A dedicated sensor helps prove whether the idea survives wiring, mounting, vibration, power limits, controller latency, and repeated field testing.
For Industrial Inspection and Smart Security
⚙️ Start by identifying detection zones and measurement targets. Evaluate environmental light, surface materials, required range, false-positive risk, and installation constraints. Choose a sensor with documented indoor and outdoor performance, then integrate depth data into alarm, inspection, or analytics software.
Long-term testing is essential because industrial systems must remain stable under changing light, dust, vibration, temperature, and object conditions. A scan that looks good once is not enough. A production system needs repeatable behavior day after day.
FAQ
Is an iPhone with LiDAR worth it for 3D scanning?
What is the LiDAR scanner on iPhone actually used for?
Are there one-time payment iPhone LiDAR apps, or do I need a subscription?
Can iPhone LiDAR be used for robotics prototyping?
How accurate is iPhone LiDAR for measurement?
Is iPhone LiDAR good enough for outdoor scanning?
What is the difference between iPhone LiDAR and dToF LiDAR?
When should I upgrade from iPhone LiDAR to a dedicated LiDAR module?
Final Verdict: Should You Use iPhone LiDAR or a Dedicated Module?
The iPhone LiDAR scanner is worth it when convenience matters most. It is excellent for quick spatial capture, room scans, AR visualization, rough 3D references, and casual measurements. For designers, real estate teams, hobbyists, educators, and app users, it can be a powerful tool because it removes the friction of carrying specialized hardware.
But for industrial and robotics applications, the equation changes. A phone-based scanner is not designed to be a production sensor, and app-driven workflows can limit data control, repeatability, integration, and long-term cost predictability. Robotics, UAVs, smart inspection, security monitoring, and embedded vision systems need sensors with defined performance and direct interfaces.
Here’s the deal in one sentence: if you need a quick visual model, use the iPhone; if you need a machine to sense, decide, and react, use a dedicated LiDAR module. That distinction saves time, budget, and a lot of avoidable engineering frustration.
If your project needs compact dToF depth sensing for robotics, UAVs, inspection, or embedded perception, explore the DTOF Solid state LiDAR HM-LD1. It offers indoor ranging up to 25 m, outdoor ranging up to 8 m, ±3 cm accuracy, 60° × 45° FOV, 10 fps depth output, UART/UDP/UVC interfaces, and SDK support for Windows, Linux, and arm Linux platforms.
📚 References & Further Reading
- Industry Standard: Hesai Technology and SPIE
- Related Guide: DTOF Solid state LiDAR HM-LD1






