

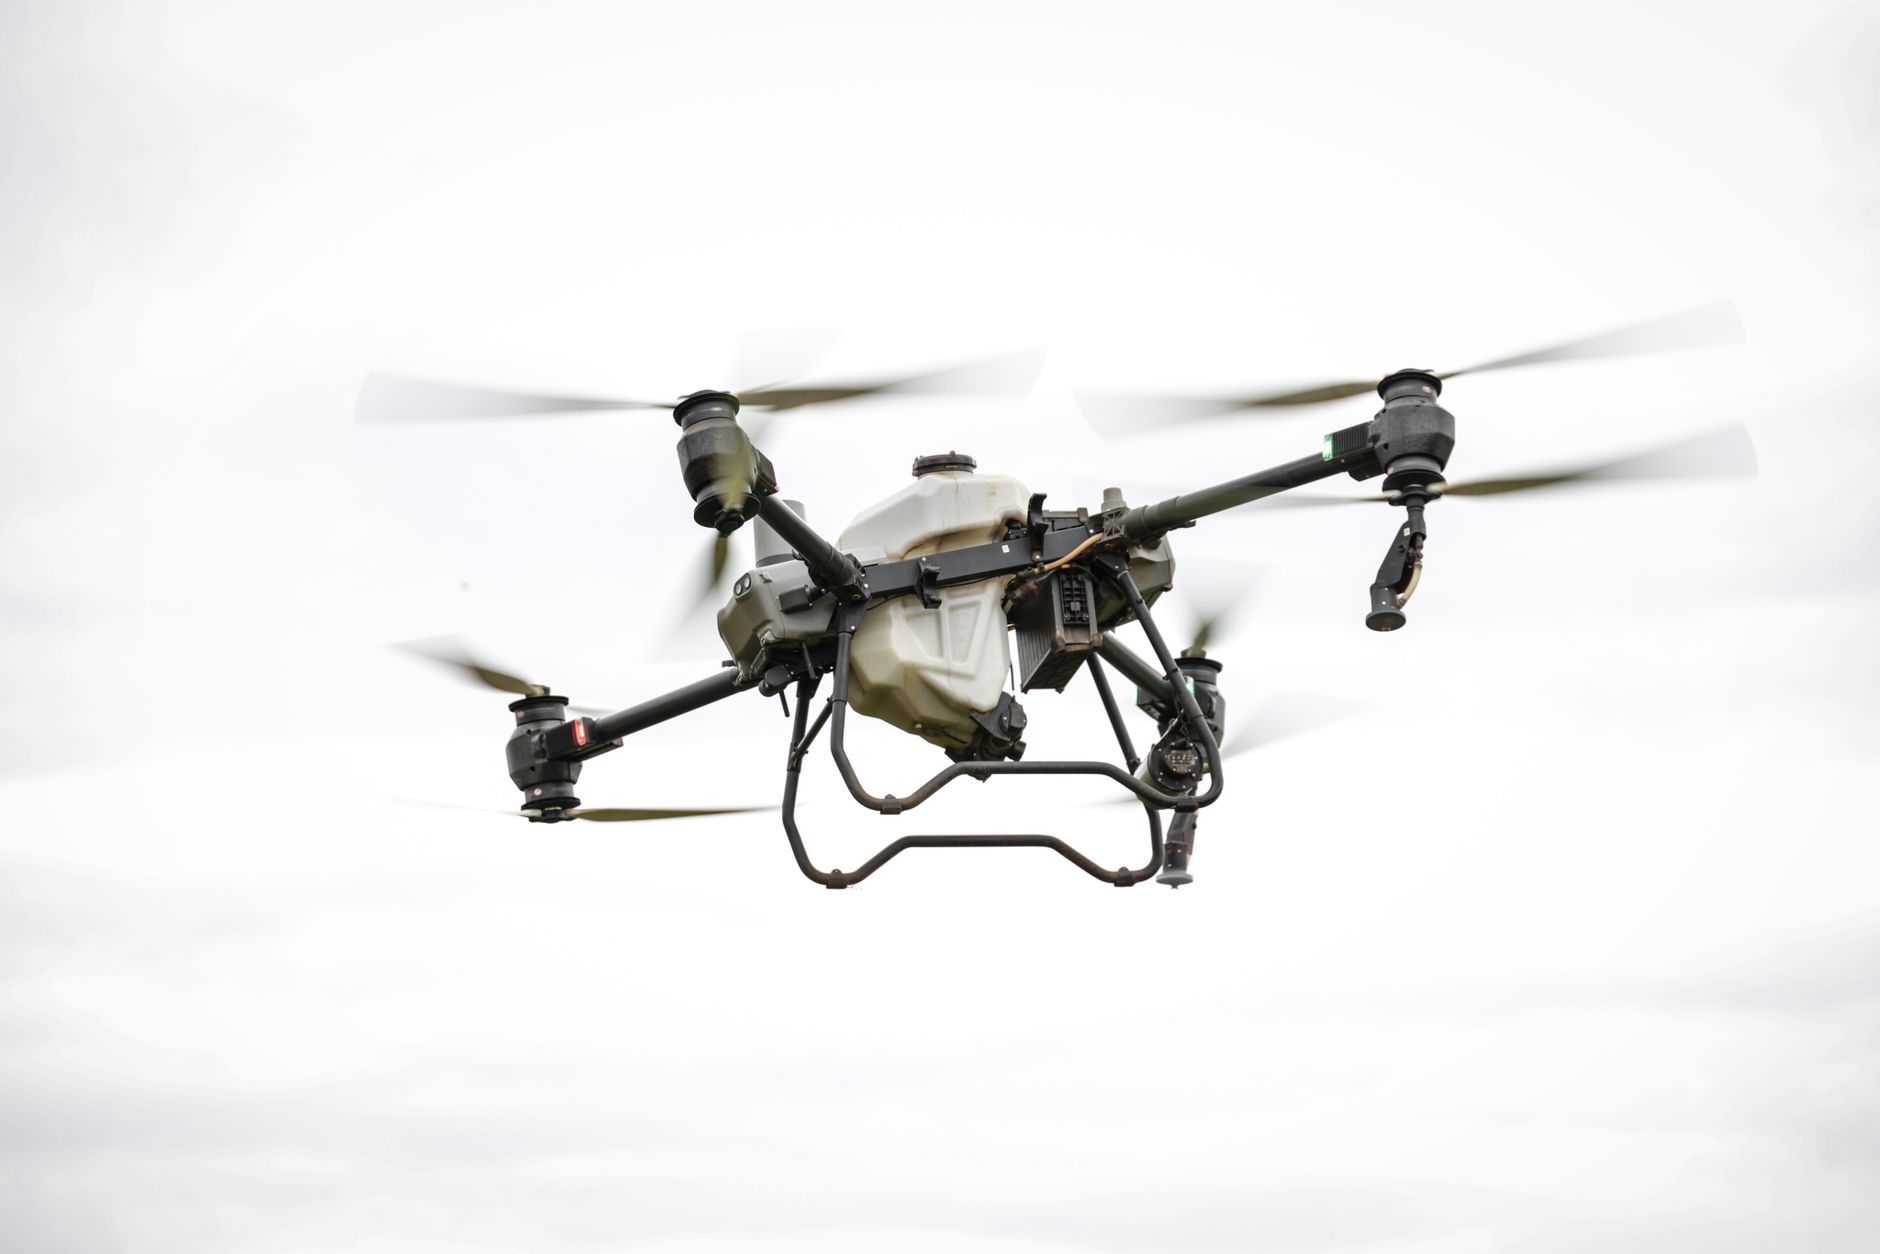
Sensor LiDAR Drone Guide: How to Choose Lightweight LiDAR for UAV Mapping, Obstacle Avoidance & Inspection
A modern drone is no longer just a flying camera. In the shop, that idea gets outdated fast. For UAV mapping, inspection, autonomous navigation, and obstacle avoidance, the aircraft has to understand distance, depth, and object position in real time. That is where a sensor lidar drone system earns its keep. By sending out light pulses and measuring how long the returns take, LiDAR gives a UAV direct distance data that cameras alone can struggle to deliver in low-texture scenes, shadows, repetitive industrial structures, or changing lighting conditions.
Here’s the deal: choosing LiDAR for a drone is not as simple as buying the longest-range sensor on the spec sheet. Drone platforms are limited by payload weight, power budget, vibration, processing capability, interface compatibility, and flight time. A heavy survey LiDAR may be the right tool for professional topographic mapping, while a compact solid-state dToF LiDAR module may be the smarter fit for obstacle avoidance, altitude hold, terrain following, robotic vision, and lightweight UAV development. This guide walks through how drone LiDAR works, how to choose the right sensor, and how compact modules such as the DTOF Solid State LiDAR HM-LD1 can support real-time UAV perception.
Table of Contents
- 👉 What Is a Sensor LiDAR Drone?
- 👉 How LiDAR Works on Drones
- 👉 Main Drone LiDAR Use Cases
- 👉 Lightweight LiDAR vs Survey-Grade Drone LiDAR
- 👉 How to Choose a LiDAR Sensor for a Drone
- 👉 Interfaces, SDKs, and Integration for Drone LiDAR
- 👉 DTOF Solid State LiDAR HM-LD1 for Lightweight Drone Perception
- 👉 Using LiDAR Sensors for UAV Mapping
- 👉 Using LiDAR for Drone Obstacle Avoidance
- 👉 Using LiDAR Drones for Industrial Inspection
- 👉 Drone LiDAR Installation and Integration Guidelines
- 👉 Common Mistakes When Choosing a Sensor LiDAR Drone Module
- 👉 FAQ: Sensor LiDAR Drone Selection
What Is a Sensor LiDAR Drone?
Definition of a Sensor LiDAR Drone
A sensor LiDAR drone is a UAV equipped with a LiDAR sensing module or LiDAR payload to measure distance, perceive depth, detect obstacles, support navigation, or collect 3D spatial data. LiDAR stands for Light Detection and Ranging. In plain field language, the sensor sends out light energy, receives the reflected signal from objects or surfaces, and calculates distance from that return. On a drone, that distance information can help the aircraft understand the environment around it, maintain a controlled distance from infrastructure, follow terrain, support landing, or generate point cloud data.
Unlike a normal RGB camera, which captures color and texture, LiDAR directly measures geometry. That matters when the drone has to make decisions based on actual distance rather than image appearance. In a warehouse, a drone may need to know how far it is from a rack or beam. On an inspection job, it may need to keep a safe standoff distance from a bridge, dam, tank, wall, or roof edge. In robotics research, LiDAR depth data may be combined with IMU, camera, optical flow, or visual-inertial odometry to build a more reliable perception stack.
Sharing a compact dToF sensor we’ve been working with for drone obstacle av…
LiDAR Sensor vs LiDAR Payload
Look, when people search for a drone LiDAR sensor, they may be talking about two very different product categories. A LiDAR sensor or module is usually a compact ranging device used for embedded perception. It may provide distance readings, a depth image, or a small 3D point cloud. These modules are often used for obstacle avoidance, altitude hold, terrain following, distance detection, robotic vision, and development platforms.
A LiDAR payload or drone mapping system is usually a larger integrated package. It may include a high-performance scanner, GNSS receiver, IMU, data storage, time synchronization hardware, calibration parameters, a gimbal or mechanical structure, and post-processing software. This type of system is used for professional surveying, topographic mapping, corridor mapping, mining, forestry, engineering deliverables, and georeferenced point cloud production.
This distinction matters because many teams searching for “sensor lidar drone” do not need a full survey payload. If the job is local obstacle awareness, short-to-medium-range inspection, embedded navigation, or UAV research, a lightweight solid-state dToF LiDAR module may be the better technical and economic choice.
Why Drone LiDAR Selection Is Different from Ground Robot LiDAR Selection
Drone LiDAR selection is tougher than ground robot LiDAR selection. A ground robot can usually carry more weight, use larger batteries, and tolerate a bulkier sensor enclosure. A UAV has limited payload capacity, and every gram affects endurance, stability, and safety margin. A sensor that works fine on an autonomous mobile robot may be too heavy for a small quadcopter once mounting brackets, cables, protective housing, and companion computers are included.
Power consumption is just as important. A few extra watts may reduce flight time, increase heat inside the aircraft body, or require a larger power regulation system. Vibration is another UAV-specific headache. Propellers, motors, and airframe resonance can affect data stability and long-term mechanical reliability if the sensor is poorly mounted. Outdoor sunlight also matters because optical sensors may lose usable range under high ambient light. Field of view influences blind spots, while interface compatibility affects whether the sensor can communicate with a flight controller, Raspberry Pi, Jetson, industrial PC, or another embedded platform.
Teams working on autonomous UAV navigation can also compare LiDAR-based perception with visual approaches in our guide to visual-based navigation for UAV.
How LiDAR Works on Drones
Time-of-Flight Distance Measurement
Most drone LiDAR systems are based on time-of-flight measurement. The sensor emits a light pulse toward the environment. When the pulse reaches an object, part of the energy reflects back to the receiver. Because the speed of light is known, the sensor can estimate distance from the time required for the emitted light to travel to the target and return. In direct Time-of-Flight, often written as dToF, the system directly measures photon return time. That is different from indirect ToF approaches that estimate distance from phase shift.
For drone applications, the value of ToF measurement is simple: it can produce direct range data without needing texture, visible features, or stereo matching. A plain white wall, a concrete beam, or a low-texture warehouse floor may be difficult for a camera-only system, but a LiDAR sensor can still measure distance if the target reflectivity, angle, and lighting conditions are within the sensor’s operating envelope.
For a broader scientific overview of LiDAR measurement principles, the U.S. Geological Survey LiDAR education resource provides helpful background on LiDAR data and its uses.
Solid-State LiDAR vs Mechanical LiDAR
Mechanical LiDAR uses moving parts to scan the environment. These sensors can offer wide scanning patterns and longer ranges, depending on their design, but they are often heavier, more power-hungry, and mechanically more complex. For professional mapping payloads, mechanical or hybrid scanning may be acceptable because the drone platform is larger and the mission requires dense point cloud collection.
Solid-state LiDAR is attractive for lightweight drones because it reduces or eliminates moving parts. That can improve durability, simplify integration, and cut payload weight. Solid-state dToF depth modules are especially useful when the application needs a depth image or local 3D perception rather than a large-area survey-grade scan. MEMS LiDAR uses a small scanning mechanism and can be compact, but it still involves more complex optical scanning than a pure solid-state or flash-style depth approach.
| Type | Advantages | Limitations |
|---|---|---|
| Mechanical LiDAR | Wider scanning patterns, often longer range | Heavier, moving parts, more power consumption |
| Solid-state LiDAR | Compact, lightweight, durable, easier integration | Usually more limited FOV and range |
| MEMS LiDAR | Compact scanning mechanism | More complex than pure solid-state designs |
| Flash/dToF Depth LiDAR | Real-time depth image and compact design | Resolution and outdoor range depend on sensor design |
Point Cloud and Depth Map Output
Drone LiDAR sensors may output different types of data. A simple rangefinder may output one distance value. A scanning LiDAR may output angular distance measurements that can be converted into a point cloud. A depth LiDAR module may output a depth image, where each pixel represents a distance value. Some modules also provide 3D point cloud data, which is useful for visualization, object detection, navigation, and spatial reasoning.
Depth maps are convenient for developers because they can be processed using image-style algorithms. For example, a drone can divide a depth frame into near, middle, and far zones to identify risk areas. Point clouds are useful when the system needs 3D geometry, object shape, or coordinate transformation into a drone body frame. In more advanced autonomy pipelines, the point cloud may be fused with IMU data, camera information, or odometry to improve navigation and mapping.
Why Sunlight Matters for Drone LiDAR
Outdoor performance is one of the big items that separates a lab demo from a dependable field system. Strong sunlight introduces background optical noise, which can reduce signal-to-noise ratio and shorten usable range. Target material also matters. A bright, reflective surface may be easier to detect than a dark, absorbent surface. The angle of incidence matters too: a surface viewed at a steep angle may return less signal to the receiver. Dust, fog, rain, and atmospheric conditions can further affect performance.
That is why engineering teams should always compare indoor and outdoor ranging specifications. A sensor may reach long distances indoors or at night but have a shorter daytime outdoor range. For UAV inspection and obstacle avoidance, choose based on real mission conditions, not ideal lab conditions.
Main Drone LiDAR Use Cases
Obstacle Avoidance and Collision Prevention
One of the most common reasons to use LiDAR on a drone is obstacle detection. A forward-facing sensor can detect walls, beams, shelves, tree branches, poles, and industrial structures in the flight path. A downward-facing sensor can measure altitude above the ground or a platform. Side-facing sensors can help with wall following or inspection standoff distance. In multi-directional configurations, several sensors may be used to reduce blind spots.
LiDAR does not magically make a drone autonomous. The sensor provides distance or depth information, but the system still needs perception software, risk logic, control rules, and flight controller integration. The software has to decide whether an obstacle is close enough to trigger a warning, slow down the aircraft, stop movement, climb, or reroute. The right response depends on flight speed, braking distance, mission type, and safety requirements.
Altitude Hold and Terrain Following
Downward-facing LiDAR can support altitude hold and terrain following, especially at low altitude where GNSS altitude or barometric readings may not be precise enough. In agriculture, inspection, indoor flight, landing assistance, and uneven terrain tracking, direct ground distance measurement can improve control stability. A drone flying over a sloped surface, warehouse floor, or inspection structure may benefit from reliable short-to-medium-range depth sensing.
For terrain following, engineers must account for sensor field of view, update rate, flight speed, target reflectivity, and surface texture. If the drone moves too fast for the sensor update rate and control loop, obstacle or terrain data may arrive too late. For low-speed inspection and development platforms, a compact dToF LiDAR module can often provide practical real-time distance awareness.
UAV Mapping and 3D Reconstruction
Drone LiDAR is also associated with mapping and 3D reconstruction. Professional mapping requires careful calibration, GNSS/IMU integration, trajectory processing, and point cloud registration. Compact LiDAR modules still have an important role in local environment scanning, indoor mapping prototypes, robotic SLAM development, and obstacle-aware navigation. They can help developers validate perception algorithms without immediately investing in a survey-grade payload.
If the goal is an engineering-grade deliverable such as a digital elevation model or georeferenced corridor map, a full mapping payload is usually required. If the goal is real-time onboard perception, collision awareness, or local spatial understanding, a lightweight depth sensor may be the better choice.
Industrial Inspection
Industrial inspection is a strong fit for lightweight drone LiDAR. Bridges, expressways, dams, warehouses, power facilities, tanks, corridors, tunnels, and construction sites often include structures that are difficult or unsafe for people to approach. LiDAR helps the drone maintain a safe distance from surfaces while collecting data with cameras, thermal sensors, or other inspection payloads.
The HM-LD1 product details state that outdoor measurement can reach up to 8 meters on a clear summer day under approximately 80,000 lux conditions. This type of short-to-medium outdoor capability is useful for inspection assistance where the drone needs distance awareness near structures rather than long-range topographic scanning.
Drone SLAM and Robotic Vision Development
LiDAR can support SLAM and robotic vision development, especially when fused with IMU, camera, optical flow, GNSS, or visual-inertial odometry. A depth map can help identify free space and nearby obstacles. A point cloud can help estimate local geometry. For dense, high-accuracy SLAM, developers may need more advanced sensors and sensor fusion pipelines, but compact depth LiDAR modules are valuable for prototyping and embedded development.
For deployment teams evaluating visual-inertial systems, see our guide on how to solve VIO deployment issues.
Lightweight LiDAR vs Survey-Grade Drone LiDAR
When Lightweight LiDAR Is the Better Choice
Lightweight LiDAR is often the better choice when the drone needs onboard perception rather than certified mapping output. Typical applications include obstacle avoidance, UAV prototyping, education, indoor navigation, altitude sensing, local inspection, smart camera depth sensing, robot/drone multi-platform development, and OEM embedded perception. The benefits are practical and easy to understand:
✅ Lower payload weight, which helps preserve flight time and control margin.
✅ Lower power draw, which reduces battery demand and heat.
✅ Easier mechanical integration on small UAV frames.
✅ Lower total system cost for development and inspection assistance.
✅ Faster engineering cycles for R&D, universities, and OEM teams.
For small drones, every gram matters. A 28 g LiDAR module has a completely different impact on flight endurance than a mapping payload weighing several hundred grams or more. Lightweight solid-state sensors also simplify enclosure design and reduce mechanical complexity. For R&D teams, universities, and OEM developers, this can accelerate testing and reduce early-stage project risk.
When Survey-Grade LiDAR Is Necessary
Survey-grade LiDAR is necessary when the application requires professional mapping accuracy, high point density, large-area coverage, georeferenced point clouds, repeatable deliverables, and validated measurements. Examples include topographic surveying, forestry canopy penetration, corridor mapping, mining volumetrics, digital elevation models, engineering survey, and infrastructure documentation.
These workflows usually need more than a sensor. They require GNSS/INS integration, time synchronization, calibrated offsets, trajectory processing, flight planning, ground control or check points, and professional post-processing software. A compact sensor should not be positioned as a direct replacement for a survey payload. It should be selected when real-time perception, compact integration, and embedded development are the priority.
Decision Matrix
| Application | Recommended LiDAR Type | Reason |
|---|---|---|
| Drone obstacle avoidance | Lightweight solid-state dToF LiDAR | Requires compact size, low latency, and low payload weight |
| Altitude hold | Downward-facing ToF or dToF LiDAR | Needs stable short-to-medium range measurement |
| Professional terrain mapping | Survey-grade LiDAR payload | Requires GNSS/IMU, calibrated point clouds, and mapping software |
| Inspection R&D | Compact depth LiDAR module | Balances cost, weight, and real-time perception |
How to Choose a LiDAR Sensor for a Drone
1. Weight and Payload Budget
Weight is one of the first specifications to check. Drone payload capacity is not just about whether the aircraft can lift the sensor. It is about whether the aircraft can lift the complete installed system while maintaining safe flight time, stability, and control margin. Engineers should include the LiDAR module, bracket, fasteners, cable harness, vibration isolation, protective cover, companion computer, power regulator, and any additional enclosure.
A lightweight LiDAR sensor for small drones can make the difference between a practical prototype and a platform that becomes too heavy to test safely. In the shop, this shows up fast: the aircraft lifts, but the flight time drops, the motors run hotter, and the pilot loses confidence. Compact modules are attractive for obstacle avoidance and embedded perception because they leave more room in the payload budget for batteries, wiring, and safety margin.
2. Power Consumption
Power consumption affects battery endurance and thermal design. A low-power sensor reduces current draw and helps preserve flight time. It also reduces heat generation inside compact drone bodies. Even if a sensor is small, high power consumption may require a more capable voltage regulator, additional heat dissipation, or larger battery capacity.
For battery-powered UAVs, a 1.2 W LiDAR module is easier to integrate than a high-power payload. It is especially valuable for lightweight inspection drones, indoor UAVs, and research platforms where every watt counts.
3. Indoor and Outdoor Ranging Capability
Always check indoor and outdoor range separately. Optical sensors often perform better indoors or at night because there is less ambient light. Outdoor sunlight can reduce effective range. The target surface also matters. Dark, angled, transparent, glossy, or irregular surfaces may produce weaker or less stable returns.
For drone obstacle avoidance, the required range depends on aircraft speed and stopping distance. A slow indoor inspection drone may only need short-to-medium range awareness. A fast outdoor UAV may need longer detection distance and faster update rates. Do not size the sensor only around a best-case lab number.
4. Ranging Accuracy
Ranging accuracy determines how closely the reported distance matches the true distance. For obstacle avoidance, centimeter-level accuracy may be sufficient because the system is usually concerned with safety zones rather than survey measurements. For altitude hold, stable repeatability may be just as important as absolute accuracy. For professional survey mapping, accuracy requirements are much stricter and depend on georeferencing, calibration, and processing workflow.
When comparing specifications, engineers should ask whether the stated accuracy applies across the full range, under what lighting conditions, and against what target reflectivity. A useful spec sheet tells you not just the number, but the conditions behind the number.
5. Field of View
Field of view defines how much of the environment the sensor can observe. A forward-facing LiDAR with a wider horizontal and vertical FOV can detect a larger area in front of the drone. This is useful for obstacle awareness and standoff distance monitoring. However, wider FOV does not automatically mean better performance. Depending on sensor resolution, a wider FOV may reduce angular detail per pixel.
For downward altitude measurement, a narrower or directed sensing area may be acceptable. For obstacle avoidance, a wider depth image can help detect objects that are not exactly in the center of the flight path.
6. Resolution and Frame Rate
Resolution determines how much spatial detail is available in the depth image. A higher resolution can detect smaller objects or more detailed shapes, but it may increase data processing requirements. Frame rate determines how often the sensor updates. A 10 fps depth stream may be sufficient for many low-speed perception applications, inspection assistance, and development projects. Faster drones may require higher update rates, multiple sensors, predictive control, or conservative speed limits.
The correct frame rate depends on the full data pipeline. A high frame rate is not useful if the software, communication interface, or flight controller introduces excessive latency. Always test sensor output, processing time, and control response together.
7. Interfaces
Interface selection can determine how quickly a drone LiDAR project moves from bench test to flight test. UART is useful for simple embedded communication with microcontrollers or flight systems. UDP is useful for network-based streaming to embedded Linux platforms, industrial PCs, and robotics systems. UVC is convenient when the LiDAR can behave like a camera-style device, allowing depth frames to be accessed by PCs and vision frameworks.
Flexible interface support is valuable because the same sensor can be evaluated on a PC, integrated with Raspberry Pi or Jetson, and later adapted to an embedded system.
8. SDK and Platform Support
SDK support reduces integration time. Drone developers often work with x86 Windows for testing, x86 Linux for robotics software, and ARM Linux for embedded platforms such as Raspberry Pi or other companion computers. A sensor with documented SDK support makes it easier to read data, visualize depth maps, generate point clouds, and build perception algorithms.
Without good software support, a low-cost sensor can become expensive in engineering time. Procurement teams should evaluate not only the sensor price but also documentation quality, example code, driver availability, technical support, and long-term supply stability.
9. Environmental Robustness
Drone LiDAR must tolerate real-world conditions. Temperature range, sunlight, dust, vibration, propeller wash, electrical noise, and mechanical stress all affect reliability. Engineers should consider cable strain relief, connector locking, EMI routing, grounding, waterproofing needs, and lens protection. If the sensor is used outdoors, the enclosure and mounting design must protect the optics without blocking the field of view.
Operating temperature is especially important for industrial inspection. A drone may be used in cold warehouses, outdoor summer environments, or near industrial structures where thermal conditions vary significantly.
10. Integration Cost, Not Just Sensor Price
The total cost of a drone LiDAR system includes the sensor price, development time, SDK maturity, mechanical mounting, power regulation, software drivers, data fusion, flight testing, documentation, and supplier support. A sensor with good interfaces and support can reduce engineering effort. A sensor with poor documentation may require weeks of custom development before useful data is available.
For OEM/ODM projects, supply stability and customization options are also important. Teams should consider whether the supplier can support long-term production, technical integration, and application-specific requirements.
Need a Lightweight LiDAR Sensor for UAV Development?
Explore the DTOF Solid State LiDAR HM-LD1 with 28 g weight, 1.2 W power consumption, 60° × 45° FOV, and UART/UDP/UVC interfaces for drone obstacle avoidance, inspection, and robotic vision.
Interfaces, SDKs, and Integration for Drone LiDAR
Connecting LiDAR to a Flight Controller
Some drone LiDAR applications only require simple distance readings. For example, a downward-facing sensor may provide altitude information, or a forward-facing sensor may trigger an obstacle warning. In these cases, a flight controller or microcontroller may receive compact data packets and make basic control decisions. UART can be useful in this type of embedded workflow.
More advanced applications require depth maps or point clouds to be processed by a companion computer. The flight controller may handle stabilization and basic flight control, while the companion computer handles perception, obstacle detection, local planning, and decision logic. The final command may then be sent back to the flight controller.
Connecting LiDAR to Raspberry Pi, Jetson, or Embedded Linux
Embedded Linux platforms are common in drone R&D because they can run robotics middleware, computer vision libraries, logging tools, and AI inference frameworks. UDP and UVC workflows are useful for streaming depth data to these systems. Developers can capture depth maps, visualize point clouds, test obstacle segmentation, and record datasets for validation.
When selecting hardware, engineers should check CPU usage, bandwidth, memory, and driver compatibility. A sensor that works well on a desktop PC may require optimization for embedded platforms with limited processing resources.
Using LiDAR with ROS, OpenCV, and SLAM Pipelines
Many robotics teams use LiDAR data inside ROS, OpenCV, or custom SLAM pipelines. A depth map can be converted into a point cloud, filtered, transformed into the drone body frame, and fused with IMU or camera data. For obstacle avoidance, the system may identify near-field objects and create risk zones. For SLAM research, depth data may help build local maps or improve environmental understanding.
Low-resolution depth modules can still be useful if the goal is near-field awareness, inspection standoff, or basic navigation support. For dense mapping, the sensor requirements become more demanding.
Latency and Data Pipeline Considerations
Latency is the total delay between sensing the environment and updating the drone’s behavior. It includes light measurement, depth calculation, interface transmission, middleware processing, obstacle detection, decision logic, and flight command update. A sensor with acceptable frame rate may still perform poorly if the software pipeline introduces too much delay.
Engineers should test the complete pipeline under realistic conditions. That means recording timestamped data, evaluating end-to-end response time, and validating performance at the intended flight speed. In a safe test area, run the system slowly first, review logs, then increase speed only when the data proves the control logic is behaving correctly.
DTOF Solid State LiDAR HM-LD1 for Lightweight Drone Perception
The DTOF Solid State LiDAR HM-LD1 – DTOF SSL is a compact dToF LiDAR module designed for real-time depth sensing and 3D perception. For drones, it is especially relevant where payload weight, low power consumption, and integration flexibility matter. Its 28 g weight, 1.2 W power consumption, 60° horizontal × 45° vertical field of view, depth image output, and 3D point cloud capability make it suitable for UAV obstacle avoidance, altitude sensing, terrain following, robotic vision, inspection assistance, and embedded development.
Product page: DTOF Solid State LiDAR HM-LD1
Product brochure: DTOF SSL HM-LD1 Product Brochure
| DTOF Solid State LiDAR HM-LD1 Specifications | |
|---|---|
| Product Name | DTOF Solid State LiDAR HM-LD1 – DTOF SSL |
| Dimension | 43.5 mm × 30 mm × 26.5 mm |
| Weight | 28 g |
| Ranging Capability | Indoor: 0.5–25 m; Outdoor: 0.2–8 m |
| Ranging Accuracy | ±3 cm |
| Field of View | 60° horizontal × 45° vertical |
| Resolution | 40 × 30 |
| Frame Rate | 10 fps |
| Interface | UART / UDP / UVC |
| Operating Temperature | -20°C to 60°C |
| Power Consumption | 1.2 W |
| Output | Depth image and 3D point cloud data |
| SDK Support | x86 Windows, x86 Linux, ARM Linux |
| Typical Applications | Drone obstacle avoidance, UAV altitude hold, terrain following, robot navigation, SLAM development, inspection, distance detection, robotic vision |
View Product Details & Pricing ➔
Why HM-LD1 Fits Lightweight UAV Development
The HM-LD1 is well matched to lightweight UAV development because it combines compact size, low mass, and low power draw. At 28 g, it can be considered for small drones where a heavier payload would reduce flight endurance or require a larger aircraft. Its 1.2 W power consumption helps preserve battery life and makes thermal integration easier.
The module’s 60° × 45° field of view is useful for local depth perception, while its 40 × 30 resolution and 10 fps frame rate provide real-time depth frames for many low-speed obstacle detection, inspection, and robotic vision applications.
Depth Map and Point Cloud Output
The HM-LD1 provides depth image and 3D point cloud data. Depth maps are useful for perception algorithms that divide the scene into zones, detect nearby obstacles, or estimate standoff distance. Point clouds are useful for 3D visualization, local geometry estimation, and robotics development. This dual output is helpful for teams that want to prototype on a PC and later deploy on an embedded platform.
Outdoor Measurement Considerations
The HM-LD1 supports indoor ranging from 0.5 m to 25 m and outdoor ranging from 0.2 m to 8 m. The product description highlights accurate measurement even at 8 meters outdoors on a clear summer day under approximately 80,000 lux. This is relevant for inspection scenarios such as bridges, expressways, and dams, where the drone may need to measure distance to objects that are difficult for people to approach.
Platform Compatibility
The module supports UART, UDP, and UVC interfaces, giving developers flexibility across microcontrollers, PCs, embedded Linux systems, Raspberry Pi-class platforms, and robotics computers. MRP offers SDKs for x86 Windows, x86 Linux, and ARM Linux, which helps reduce software integration effort for development and deployment.
Using LiDAR Sensors for UAV Mapping
What Drone LiDAR Mapping Requires
Drone LiDAR mapping requires more than distance measurement. A professional mapping workflow usually includes a LiDAR sensor, GNSS receiver, IMU, time synchronization, calibration, point cloud processing, flight planning, and accuracy validation. The system must know not only the distance from the sensor to the target, but also the position and orientation of the drone when each measurement was collected.
For larger UAV platform planning, readers can also review our DJI Matrice 300 RTK guide.
Where Compact LiDAR Modules Fit in Mapping Workflows
Compact LiDAR modules fit well in local mapping, indoor mapping prototypes, obstacle-aware mapping drones, robotic research, perception validation, and small-scale 3D reconstruction. They are useful when developers need onboard depth awareness rather than certified survey deliverables. A lightweight module can help a drone understand its immediate surroundings, avoid obstacles during data collection, or support local navigation in GPS-denied environments.
Here’s the practical split: if the aircraft needs to avoid a wall, hold a distance from a tank, or build a local 3D awareness layer for navigation, compact LiDAR may be a good fit. If the job requires stamped survey deliverables, georeferenced accuracy, and professional-grade point density, you are in survey payload territory.
When to Choose a Survey Payload Instead
If the project requires certified accuracy, georeferenced point clouds, dense large-area topographic data, digital elevation models, forestry analysis, mining volume calculation, or engineering survey deliverables, a survey-grade payload is usually the better choice. Lightweight dToF modules are not designed to replace full GNSS/INS LiDAR mapping systems. They are best used for embedded perception, local sensing, and development applications.
Using LiDAR for Drone Obstacle Avoidance
Forward-Facing Obstacle Detection
For forward obstacle avoidance, the LiDAR should face the flight direction with an unobstructed field of view. Engineers must consider object size, field-of-view coverage, drone speed, stopping distance, and latency. A sensor may detect a wall easily but struggle with thin wires, small branches, or low-reflectivity objects depending on resolution and optical conditions.
The obstacle avoidance system should be tested at conservative speeds before deployment. The drone must have enough time to detect, process, decide, and respond. A compact depth LiDAR can provide useful near-field awareness, but the control strategy must match the sensor’s range and frame rate.
Downward-Facing Altitude and Terrain Following
A downward-facing LiDAR can measure distance to the ground, floor, roof, platform, or inspected surface. This supports altitude hold, landing assistance, low-altitude inspection, and terrain following. Surface reflectivity, slope, dust, grass, water, and sunlight can affect readings, so field tests are important.
For downward mounting, pay attention to landing gear, propeller wash, and cable routing. A blocked field of view or vibrating bracket can make a good sensor look bad. The sensor should be protected, but the optics must remain clear.
Multi-Sensor Fusion for Safer Flight
LiDAR is often most effective when fused with other sensors. IMU data helps estimate motion. Optical flow can support low-altitude positioning. Stereo cameras and RGB cameras provide visual context. Radar may help in dust, fog, or challenging weather. Ultrasonic sensors can provide short-range redundancy. GNSS/RTK can provide global positioning outdoors. The best sensor stack depends on the mission, environment, risk level, and budget.
✅ LiDAR provides direct distance and geometry.
✅ Cameras provide texture, color, labels, defects, and visual context.
✅ IMU data supports motion estimation and stabilization.
✅ GNSS/RTK supports outdoor global positioning.
✅ Optical flow can improve low-altitude movement estimation.
Obstacle Avoidance Algorithm Workflow
A practical obstacle avoidance workflow begins by capturing a depth frame from the LiDAR. The software filters invalid readings, segments near-field obstacles, converts depth data into distance zones, estimates risk based on UAV velocity, and sends a warning or avoidance command. During testing, the system should log data for validation and improvement. Engineers should evaluate false positives, missed detections, latency, and behavior under different lighting and surface conditions.
⚙️ Start with stationary bench tests.
⚙️ Verify the depth frame and distance values against known targets.
⚙️ Test slow movement in a controlled area.
⚙️ Log timestamps from sensor capture through control response.
⚙️ Increase speed only after the data proves the system has enough reaction time.
Using LiDAR Drones for Industrial Inspection
Bridge, Expressway, and Dam Inspection
Bridges, expressways, and dams often include surfaces that are hard to access safely. Drones can reduce the need for manual climbing, scaffolding, or shutdown procedures. LiDAR helps the UAV maintain a safe distance from the structure while collecting visual or thermal inspection data. The HM-LD1’s outdoor measurement capability up to 8 m is relevant for close-range inspection assistance where standoff distance matters.
In these environments, the drone may be flying near concrete, steel, cables, railing, piers, beams, and water surfaces. The LiDAR system should be tested against the actual materials and angles expected on the job. Do not assume a clean indoor wall test tells the whole story.
Warehouse and Indoor Facility Inspection
Indoor facilities such as warehouses, factories, tunnels, and corridors often create challenges for GNSS-based navigation. LiDAR can provide local distance awareness in these environments. The HM-LD1 supports indoor ranging from 0.5 m to 25 m, making it useful for navigation assistance, obstacle detection, and distance monitoring in indoor inspection or robotic development.
Warehouses also create repetitive structures that can confuse vision-only approaches. Rows of racks, similar-looking beams, and low-texture floors make direct depth information valuable. A depth LiDAR module gives the perception system another source of truth.
Inspection Safety and Standoff Distance
Maintaining a consistent standoff distance is important in inspection. Flying too close can risk collision. Flying too far may reduce image detail or sensor quality. LiDAR helps estimate the distance to walls, columns, beams, shelves, tanks, and other infrastructure. This information can support pilot awareness, assisted flight, or autonomy algorithms.
For inspection teams, standoff distance is not just about avoiding contact. It also helps keep camera framing consistent, improves repeatability between inspection passes, and gives pilots better confidence when working near critical assets.
Combining LiDAR with Cameras for Better Inspection Data
LiDAR and cameras complement each other. LiDAR provides geometry and distance. RGB cameras provide visual evidence such as cracks, corrosion, labels, surface defects, and structural details. Thermal cameras provide heat information. For industrial inspection, combining LiDAR with cameras allows the drone to maintain safe distance while collecting the imagery needed for reporting and analysis.
Drone LiDAR Installation and Integration Guidelines
Mechanical Mounting
LiDAR should be mounted rigidly enough to maintain a stable coordinate frame, but protected from excessive vibration. Propeller wash, landing gear, brackets, and cables must not block the field of view. The sensor orientation should match the sensing task: forward for obstacle detection, downward for altitude or terrain following, and angled for inspection standoff monitoring.
In the shop, a lot of integration problems come from simple mechanical mistakes. A loose bracket, a cable hanging in front of the optics, or a mount that flexes during acceleration can create noisy data. Build the mount like the sensor measurement matters, because it does.
Power and Wiring
Power wiring should include stable voltage regulation, secure connectors, proper grounding, and strain relief. Cable routing should reduce electromagnetic interference and avoid moving propellers or gimbal mechanisms. For drones, connector locking and vibration-resistant wiring are important because intermittent power or data loss during flight can create safety risks.
⚙️ Use a stable regulated power source.
⚙️ Add strain relief near connectors.
⚙️ Keep data wiring away from high-current motor leads when possible.
⚙️ Confirm connectors cannot shake loose during vibration.
⚙️ Check voltage under load, not just with the aircraft sitting idle.
Calibration and Coordinate Frames
Coordinate frames define how LiDAR data relates to the drone body, IMU, camera, and flight controller. If the sensor is mounted with an offset or angle, the software must account for that transformation. Poor calibration can cause the system to misinterpret obstacle position or distance. For multi-sensor fusion, accurate coordinate alignment is essential.
Calibration does not have to be overcomplicated for every project, but it does need to be honest. If the LiDAR is angled downward by 15 degrees, the software needs to know that. If the sensor sits forward of the drone centerline, the system needs to know that too.
Testing Procedure Before Flight
Before flight, engineers should confirm output data, verify indoor range, test outdoor range, check latency, confirm mounting stability, validate obstacle zones, perform tethered or low-speed tests, and log all data. Testing should begin in controlled conditions and gradually move toward real mission environments. Any autonomous response should be validated carefully before enabling higher-speed operation.
✅ Confirm the sensor powers on reliably.
✅ Verify distance readings against known targets.
✅ Check depth image orientation and field of view.
✅ Test sunlight performance if the drone will fly outdoors.
✅ Validate the full data path from sensor to control response.
✅ Review logs before increasing autonomy or flight speed.
Common Mistakes When Choosing a Sensor LiDAR Drone Module
Choosing Range Without Checking Outdoor Conditions
A common mistake is comparing only maximum range. Indoor range may not equal outdoor daylight range. Strong sunlight, target reflectivity, angle, and weather can reduce performance. Buyers should always check outdoor specifications and test under real mission conditions.
Ignoring Weight and Power
A sensor may look excellent on paper but reduce flight time or require a larger drone. Weight and power should be evaluated as part of the full installed system, including brackets, cables, computers, and power electronics. A small sensor with a heavy mounting solution may not be a lightweight system anymore.
Assuming LiDAR Alone Provides Autonomous Flight
LiDAR is only the sensing layer. Autonomous flight also requires perception algorithms, decision logic, flight control integration, mapping or localization, safety behavior, testing, and validation. A good sensor improves environmental awareness, but it does not replace the full autonomy stack.
Overbuying Survey LiDAR for Simple Obstacle Avoidance
Some teams purchase expensive mapping payloads when they only need local obstacle detection or altitude sensing. For many UAV R&D, inspection assistance, education, and embedded perception projects, a compact solid-state dToF LiDAR module is more practical and cost-effective.
Ignoring Interface and SDK Support
Interface and SDK support can determine project success. A sensor that lacks usable drivers, documentation, or platform support may consume more engineering time than expected. For drone development, UART, UDP, UVC, and SDK support across common platforms can significantly reduce integration risk.
Build Your Drone Perception System with MRP
MRP provides perception and positioning modules for robots and UAVs, with technical support, SDKs, source-factory supply, and OEM/ODM customization options.
FAQ: Sensor LiDAR Drone Selection
Is there any LiDAR for small drones?
What LiDAR sensor should beginners choose for a drone project?
Is an expensive survey LiDAR drone worth it in 2025?
Can a drone use LiDAR for obstacle avoidance?
How far can a drone LiDAR sensor detect objects?
Is LiDAR better than a camera for drones?
Can lightweight LiDAR be used for drone mapping?
What is the best mounting position for LiDAR on a drone?
What interfaces are useful for drone LiDAR integration?
What specifications matter most when buying a drone LiDAR sensor?
📚 References & Further Reading
- Industry Standard: USGS overview of LiDAR data and applications
- Related Guide: Visual-Based Navigation for UAV








