
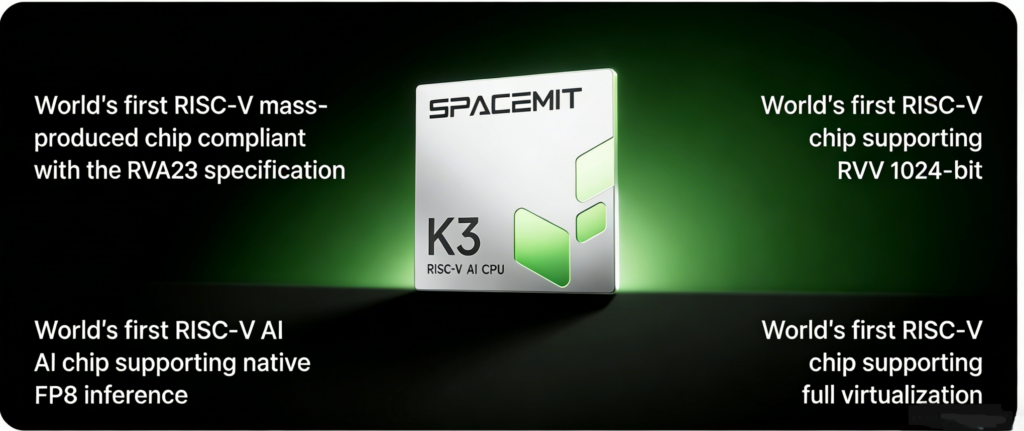
SpacemiT K3 Chip: Full Specifications, Interfaces & Core Innovations of the RVA23 RISC-V AI CPU

Introduction
SpacemiT K3, the flagship AI CPU chip launched by Chinese RISC-V pioneer SpacemiT in January 2026, stands as the world’...
Stop dragging a cable: make ANY UARTpose/odometry sensor wireless (ESP8266 bridge)
I’m done dragging a USB cable just to watch pose/odometry update in realtime.
So I built a tiny UART → Wi-Fi bridge with an ESP8266 ...
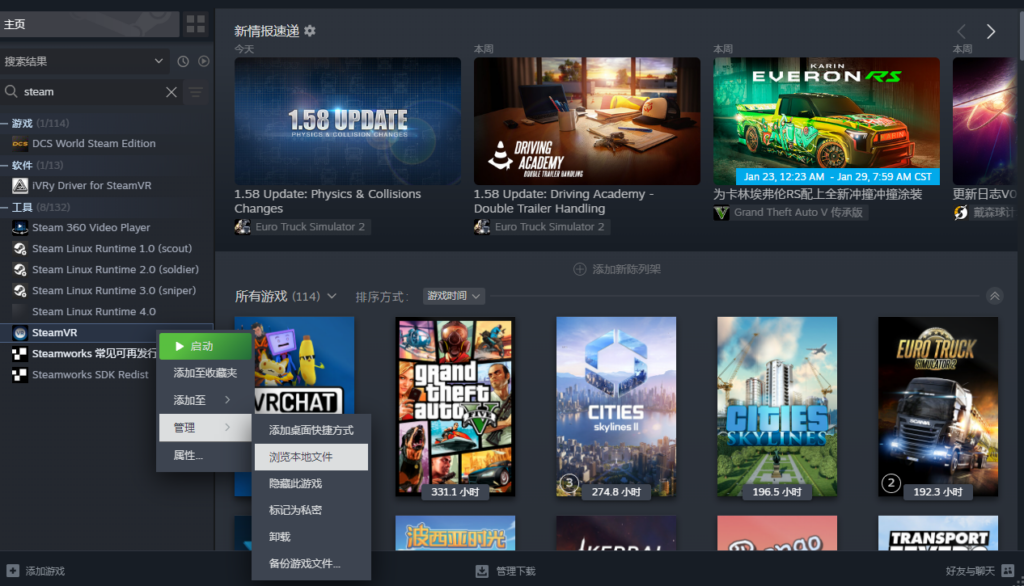
How to Connect RoboBaton-mini to Steam VR
With the growing popularity of VR development and application scenarios, we casually came up with the idea of integrating our in-house ...

Revolutionary Event Cameras That Capture What Traditional Cameras Miss
In high-speed and high-contrast environments such as autonomous driving, robotics, industrial inspection and motion capture, the core c...
Visual-Based Navigation (VBN) : The Complete Guide to UAV Navigation
Learn how UAV Visual-Based Navigation (VBN) solves drone localization issues in GNSS-denied environments—explore its principles, uses, challenges, and breakthroughs for safer, precise flights.

VIO With Global Shutter And Odometer: Practical Application Tips
Struggling with outdoor VIO accuracy? Learn practical, low-cost tips for global shutter camera photometric adaptation and a efficient loose-coupling method to use odometer data for error checking without high computational cost.

The Ultimate Guide to Robot State Estimation (15):VIO/VSLAM/Depth Camera
Move beyond academic metrics. Learn how hardware selection, fusion algorithms (VIO, GNSS), and depth camera traits (iTOF, Stereo) impact real-world VIO/VSLAM accuracy and robustness for robotics applications.
What Is The Aircraft Obstacle Avoidance System?
Critical for low-altitude economy safety: This guide covers 6 core aircraft obstacle avoidance technologies (ultrasonic, infrared, laser, LiDAR, millimeter-wave radar, visual), explains manual operation limits (camera blind spots), and shares safety tips. Learn to pick the right tech to cut crash risks.
CPU vs. GPU: Choosing the Right Accelerator for SLAM
Struggling with the high cost of GPUs? Learn practical CPU optimization techniques for SLAM on edge devices. Achieve low latency and reduce costs for industrial applications like SLAM and robotics. No expensive hardware required.
How to Engineer and Deploy Mainstream VIO/VSLAM Systems
Discover proven methods to overcome VIO/VSLAM deployment challenges, including ZUPT implementation, hardware acceleration, and real-time optimization for VINS-MONO/DSO systems. Learn industry best practices.
How to Solve VIO Deployment Issues: 8 Engineering Challenges
Discover the key engineering challenges in VSLAM/VIO deployment, including ORB-SLAM3 limitations, VINS-MONO optimization, and hardware integration strategies for real-world applications.