

Robot State Estimation | Does Robot Perception Technology Really Matter?

Exploring robot state estimation's commercial reality: Why over-engineered perception tech often fails in real-world robotics.
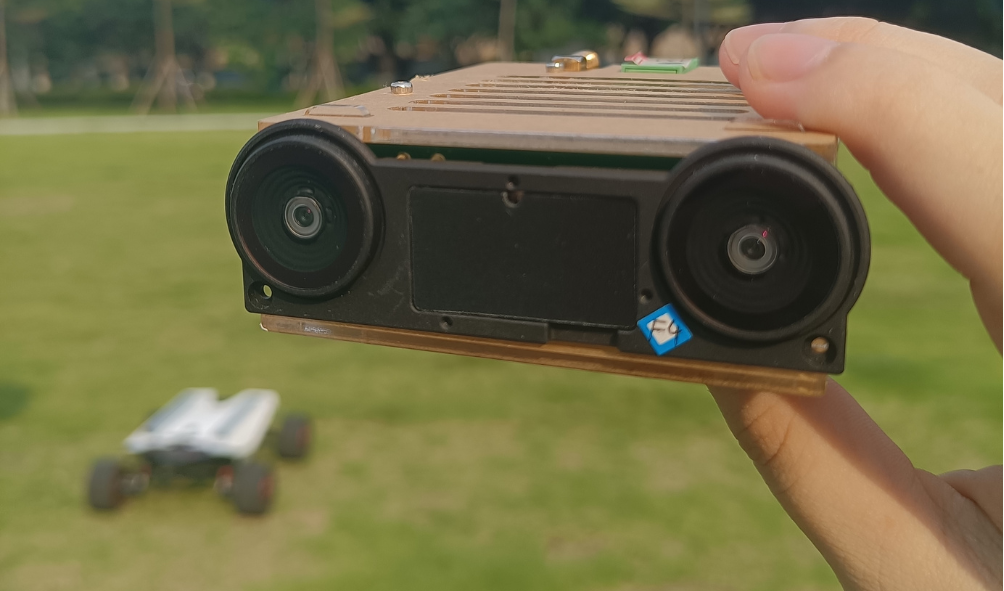
3 Critical VIO Problems & How to Fix Them
Explore the three-phase nature of VIO systems (overhead/robustness/accuracy) and worldview construction challenges. Learn how ORB-SLAM3, VINS-MONO and DM-VIO address these issues with practical deployment strategies.
As Level 3 Autonomy Goes Mainstream, Will Spatial Camera Replace Traditional Vision in ADAS?
With Level 3 autonomous driving gaining regulatory approval across Europe, Japan, and parts of the U.S., the spatial camera is receivin...
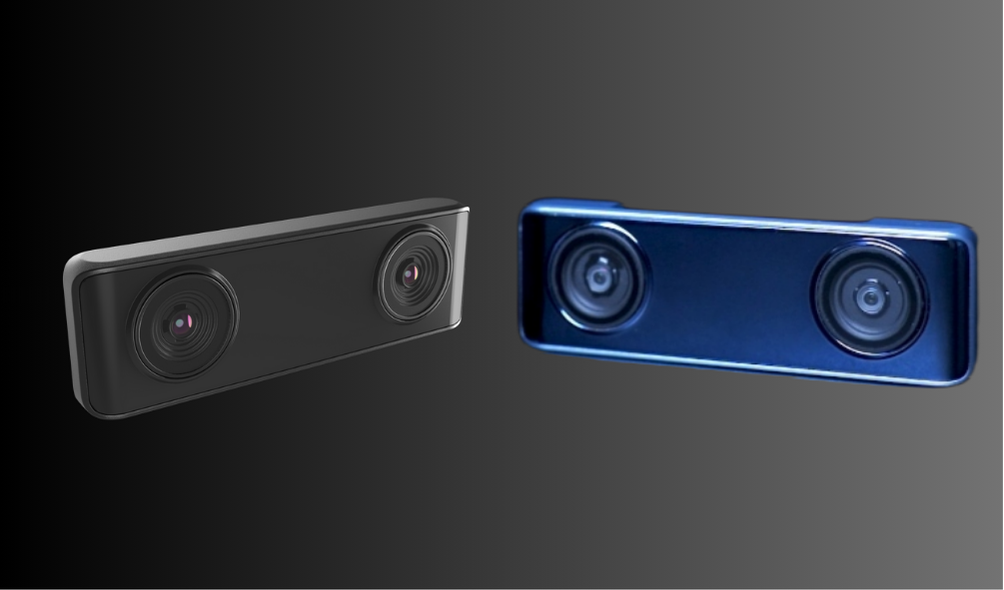
How to Fix VIOVINSVSLAM Issues: Complete Guide
Comprehensive guide to diagnosing and fixing VIO/VINS/VSLAM issues—scale drift, IMU errors, calibration, and optimization. Learn best practices for monocular & binocular systems.
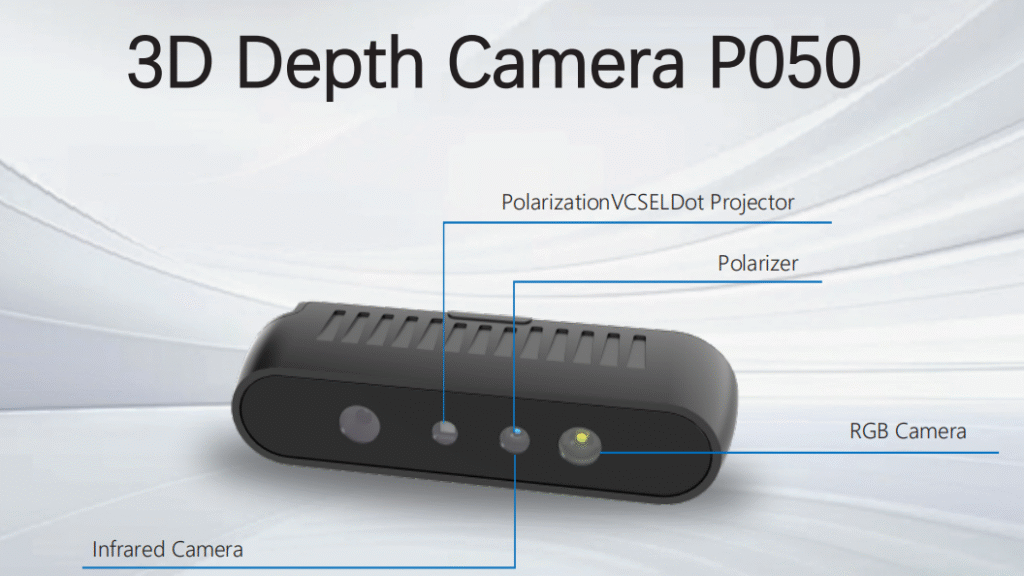
Depth Camera:How To Choose a 3D Depth Camera?
Struggling to pick a 3D depth camera? Compare structured light, ToF, and stereo vision technologies. Learn how iHawkP100R/P050 achieve millimeter-level accuracy for robotics, AR, and industrial applications

What is the Fundamental Issues of Visual-Inertial Odometry?2 Critical Challenges
Explore Visual-Inertial Odometry (VIO) challenges: accuracy vs. overhead trade-offs. Discover key solutions like ICEBA, DMVIO backend optimization, and ZUPT for robust 3D pose estimation in robots and XR devices.

What Problems Does ZUPT Solve in VIO/VSLAM? Tuning Tips and Practical Fixes
Facing VIO/VSLAM challenges in extreme conditions? This guide reveals how ZUPT offers practical solutions for drift, visual blind spots, high-speed motion, and more. Get expert tuning tips.
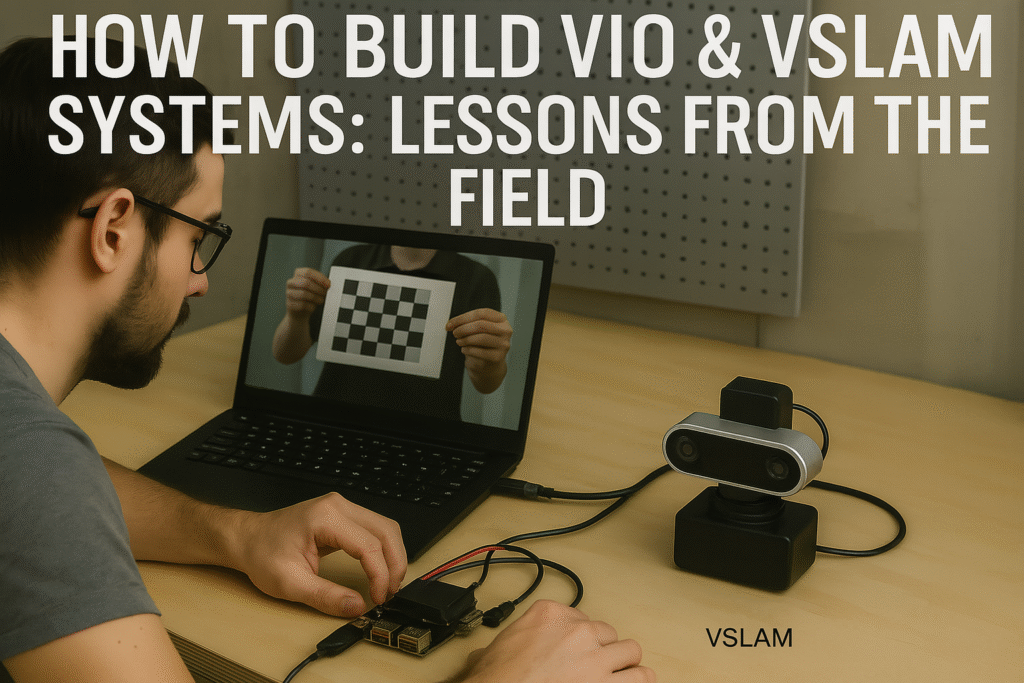
How to Build VIO & VSLAM Systems: Lessons from the Field
If you’re developing autonomous robots, drones, or AR/VR devices, you’ve likely looked into VIO (Visual-Inertial Odometry) and VSLAM (V...

Kalman Filter or Bundle Adjustment? How to Choose for SLAM Systems?
SLAM Systems: Kalman Filter vs. Bundle Adjustment – Compare accuracy, speed & robotics applications.

How to Implement ZUPT in VIO? Engineering 3 Constraints & Pitfall Avoidance
Today, we will delve into the core technologies and engineering practices within Visual-Inertial Odometry (VIO) systems. While specific...
How to Master Robot State Estimation? A SLAM Developer’s Roadmap
Learn robot state estimation for SLAM & autonomous driving with this step-by-step guide. Master linear algebra (50%), Lie groups (20%), and C++/Eigen coding. Includes ROS-compatible practice projects and competition tips.

Precise Robot Localization Made Easy | VIOBOT2 Spatial Computing Module
RoboBaton-VIOBOT2 offers advanced visual-spatial computing for robotics. Get real-time pose, depth maps & 3D reconstruction with RK3588 chip & proprietary algorithms.